
Problems of Selecting A Galt For An Integrated Locomotion Robot
Proceedings of the Fourth International Joint Conference on Artificial Intelligence. Robots And Productivity Technology. Pages 789-792.
© 1975 International Joint Conferences on Artificial Intelligence
Abstract
In controlling the locomotion of the walker there appear problems associated with the necessity of constructing coordinated motion of the body and legs which ensures accomodation to irregularities of the terrain being overcome. The paper considers algorithms tor selecting su9porting points for legs and for gait synthesis at a prescribed curvilinear motion of the walker over the terrain with complex relief.
- hev, V.E. Pavlovskij , V.S. Jaroshevskij, "Coordination of the walker's motions", Trudy IV Vsesojuznoj Konferentsii po Bionike", Moscow, I973.
- D.E. Okhotsimskij, A.K. Platonov, "Algorithms for cont,....xolling the wal- ker which is capable of overcoming obstacles"', Izv. AN SSSR, Tekhn.
- Kibernetika, 1973, N 5 (Transactions of the III International Conference on Artificial Intelligence, Stanford, USA, I973).
- D.E. Okhotsimskij, A.K. Platonov, G.K. Borovin, I.I. Karpov, E.I. Kugu- shev, V.E. Pavlovskij, V.S. Jaroshev- skij, "The control of an integrated locomotion robot", Izv. AN SSSR, Tekhn. Kibernetika, 1974, N 6 (Tran- sactions of the VI IFAC Symposium, Erevan, I974).
- R.Tomovic, "A general theoretical model of creeping displacement", Cybernetics, 1961, IV, 98-I07.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
E.I. Kugushev, v.s. Jaroshevakij
Institute of Applied Mathematics, the USSR Academy of Sciences, Moscow, A-4?, Miusskaya Sq., 4
Abstract. In controlling the locomotion of the walker there appear problems associated with the necessity of const ructing coordinated motion of the body and legs which ensures accomodation to irregularities of the terrain being over come. The paper considers algorithms tor selecting su9porting points for legs and for gait synthesis at a prescribed curvi linear motion of the walker over the terrain with complex relief.
Introduction. In case of a uniform rec tilinear motion of the walker over a plane it is most natural to select the gait, footholds and leg motion schedule on the base of some principles of regu larity, using, for example, periodic walking "step-to-step", with constant
velocity /I-3/·
While walking over the terrain with complex relief it is sometimes impossible to realize such a uniform motion.Indeed, footholds may be arranged on the terrain irregularly, as there exist areas for bidden for placing the legs (clefts, steep slopes). It the distance between footholds is long and the transfer time is so short, that the transfer velocity turns to be higher than the allowable one, the walker should decrease the ve locity of its motion over that segment of the trace. Thus even it the surtace irregularities are quite negligible for the walker's body to move keeping a horizontal position without touching them, a uniform motion may appear to be unrealizable.
It surface irregularities are rather appreciable then it is necessary to designing the body motion &v lo&t !t should touch them. In this case linearity of the bo~ motion is disturbed and uniform motion becomes unrealizable too.
If information about the terrain is being obtained during the motion then such cases may take place when it is impossible to 9redict motion for lack of information owing to the terrain irregu larities intercepting field ot view.Thie problem may be solved by organizing interaction, a kind ot dialogue, between the information system and motion design system (KDS). The interaction leads to adrupt dlcelerations and to disturbances ot regularity and uniformity of motion.
Thus, principles of regularity, periodicity and uniformity ot legs-and body aotion used for constructing the gait, the leg motion schedule and tor selecting footholds may be appreciably at variance with the requirement that the walker should be accommodating to the terrain relief. To solve the problem ot the best accommodation of the walker to the relief accidents it was found necessary to develop algorithms for select~ng the gait, footholds and leg motion schedule without any restrictions, associated with a prescribed pattern ot motion.
Algorithms for selecting the gait, footholds and leg motion schedule depend appreciably on the availability or lack of adequate information about the ter rain at the moment when the motion is being formed. If the information about the terrain is adequate it is possible to predict footholds forward along the trace to the extent which doesn't permit to get into ''blind alleys", i.P. into positions when the walker cannot proceed with its motion in the scope of the prescribed gait. The algorithm of "wave gait" synthesis /I, 3/ offers a simple way of designing the walker's motion which does not lead to "blind alley'' situations. However, the algorithm re guires predicting for so a long distance forward along the trace that in case of unavailability of adequate information about the terrain this algorithm may be found to be unrealizable.
In references /3-5/ there was con sidered a method for solving the problem of choosing the footholds, the leg mo tion schedule and the body position for a prescribed "gallop" gait in case of unavailability of adequate informationa there the case of locomotion over ~y lindrical surface was investigated.
The investigation of locomotion over cylindrical surface has shown that in order to overcome complex terrain in the absence of adequate information about the terrain it is necessary that the algorithms for choosing the gait, footholds and leg motion schedule should provide:
- Possibility of dialogue with the information system aiming at improving the walker's passabilitya
- Locomotion over arbitrary trace being chosen by the system of trace se lection in the process of locomotion with the object of by-passing large obstacles;
- Possibility of varying the ve locity of the walker's motion without additional recalculations of locomotion parameters a
- Possibility of realizing any type of gait allowable from the view point of static stability to ensure get ting out of ''blind alley" situations.
The solution of these problems was found by describing the walker's motion in a certain "space of states" offered in the papers by R.Tomovic and R.!!cGee and with the use of estimates of situation in that space at each instant of mo tion which were suggested by A.S.Narin' jani and V.P. Pjatkin in their conversa tion with the authors. As the investiga tion showed, a more rational method of gait controlling proved to be the method of predicting a situation in the space of states and of choosing adequate ac tions needed at some key instants of lo comotion which are defined by predicting.
~elow the paper describes the structure of motion design system, intro duces definitions of a motion trace, of the walker's state and of the walker's gait. Next, algorithms of motion desig ning are described including algorithms of predicting, calculating the sequence of walker's states, and choosing foot holds.
System structure· The system for simu lating the walker's motion consists of two units: a computing unit and an exe cutive one. The computing unit simulates algorithms to be loaded into the wal ker's on-board digital computers, and the executive unit simulates the real walker.
The computing unit generates cont rol signals used by the executive unit for simulating the walker's locomotion with demostration on a DC display and for shaping information signals charac terizing quality of execution.
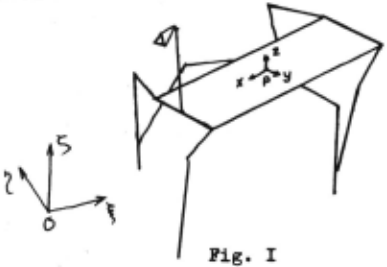
Motion trace. Motion designing is im plemented with the use of two coordinate systems - absolute one ( 0 , ~ , '2 , t; ) and relative one ( P, X , ':f, Z) (fig. I). The relative coordinate system is rigid ly coupled with the walker's body. All parameters of the walker are given in
the relative coordinate system.
The trace of motion is the curve {~ (S) > ~(5) > pC6)} in three-dimensional space ( ~ , ? , P ) where ~ , ~ coordinates of projection P on the plane Osrz., ,., - the angle between the projection of PX - axis on the plane Os~ and 0~ -axis (the walker's body yaw angle). The trace parameter 6 was taken to be equal to the length of the curve between the reference point {'_!, (o), ~ (o)) ,p> (o)} and the current point.
~· At each instant of time the walker's state from the point of view of its gait is characterized by the set of legs sup porting or being transferred, i.e. by f 1 ~ the sixdimensional vector q, = 1J. , ct ·
... , q.. 6 } which consis~s of zeros and uni"l;s. In addition q.> I if leg is sup porting, otherwise ~~= 0 /6/. At the moment of ligting or placing any legs on the terrain the walker's state ~ is changed. The walker's gait may be defined as a sequence of states ~"', n = I, 2 , ... /2/. 1!'ig. 2 shows the periodic sequence of states corresponding to the tripod gait /I/. If the sequence q., is perio dic then one may say that the gait is cyclic, and the sequence of states being realized within a period is called a cycle. The investigation of a certain class of such gaits was carr~ed out in references /I-4/.
'l.t = ( I I I I I I)
q_ 2 = ( I 0 I 0 I O)
~~= ( I I I I I I)
~~= ( 0 I 0 I 0 I)
~~= ( I I I I I I)
~·= ( I 0 I 0 I 0)
Tripod gait
Fig. 2
Given the sequence of states Q . .., = 1 2 r '} i ,.. { q,., , q., ., . . . . , q.,., q.., , it s convenient to introduce six binary fractional numbers OL.h Ol~, ... , oc.. lying in the range from zero to unit so that the digit n in the mantissa of number Ol..; is equal to 4~ . Vector CX= {a. ... , ... , Ol 6 } describes entirely the gait of a six-leg ged walker (fig. 3).
| OlJ = | O.IIIOIIIOIIIO ••• | = | !4/!5 |
| oLl | = O.IOIIIOIIIOII ••• | = | II/I5 |
| <X., = | O.IIIOIIIOIIIO ••• | = | I4/I5 |
| o£ 14 = | O.IOIIIOIIIOII ••• | = | II/!5 |
| 0£s = | O.IIIOIIIOIIIO ••• | = | I4/I5 |
| OL6 = | O.IOIIIOIIIOII ••• | = | II/I5 |
Tripod gait
1!'ig. 3
Gait ot may be realized as a stati cally stable one only in case when in any state approptiate to it, at least three legs are in the supporting phase. A ne cessary (but insufficient) condition for it is the following inequality ·
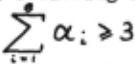
If all the gaits of the six-legged walker are identified with a unit six dimensional cube then unstable gaits will be dense throughout it. Therefore there exists no continuous functional t {«.) which would separate stable gaits from unstable ones.
Motion pattern constructing. The walker's motion constructing was subdivided into three stages:
- Global prediction on S . This stage of designing incorporates computing the state sequence for the walker to implement, along with its footholds, leg motion schedule and body motion. The depth of prediction amounts to an order of two walker's body lengths. Computa tion is performed in the absolute coor dinate system.
- Local prediction on S . This stage incorporates computing leg transfer trajectories. It also incorporates compu ting foot positions for all the legs in the relative coordinate system with such
a step .o S , that in order to calculate intermediate foot positions with a requi red precision it is sufficient to carry out linear interpolation. The depth of prediction amounts to an order of one fourth of the walker's body length.
- The generation of control signals for the executive unit. This part of the algorithm is applied in real time. A cor respondence is set up between parameter
- S and the time so that the motion ve locities of all the legs could not exceed the allowable ones. This stage also in corporates processing the signals recei ved from the executive unit.
Global prediction. At this stage the wal ker's motion is described as a sequence of states which are computed by using a special algorithm. For each state calcu lation of footholds is made, along with their existence segments. The existence segment of a foothold is a segment of the trace on which the possibility exists for a leg being in motion along it to be in the supporting phase and, in addition, the leg reaches this foothold without touching the other legs and the surface. The calculation of the existence segment of each state is made, i.e. of the trace segment on which the footholds correspon ding to a given state exist all together and provide locomotion static stability. The necessary and sufficient condition for implementing a stable motion is the existence of a non-empty intersection of the existence segment of any two succes sive states. If the motion throughout the selected sequence of states cannot be realized then a new sequence of states is calculated.
Calculation of states. The calculation of a state sequence is performed either according to a rigid scheme (for example, tripod and gallop gaits are set by vector Ol , as defined above) or on the basis of some rule. Simulation of the rule in dicated below was carried out.
Let Qo be the current state,
( s:. s:] its existence segment, [sf. s; J- the existence segment of the foothold leg i . If the leg is in the transfer phase, then it is believed that .... ·=-- .,.4;·-+- o> .l · O>.a ·
i.e. leg (0 may be in the supporting phase less than all the other legs.
is formed, where U.:. - the state diffe ring from the prededing one by the leg
is formed, where the state j)i differs from the preceding one by the leg } being in the supporting phase, i.e. an attempt is made to transfer } - leg to a new foothold so that it would be possi ble to transfer L0 - leg. lf none of these sequences is realizable then sequ ences with twin and triple leg transfer ring are formed..
Calculation of footholds. Let changing over from state Oo to state Q~ results in transferring legs it, ... ,~" ( K · 1~ 2., ~) to the supporting phase. The calculation of footholds for these legs is secured by perform~ng the iteration process on
$ - parameter of truncating the surfa
- ce domains which are allowable for pla cing legs.
The initial iteration value S£ is taken from:
depending on whether among the legs being placed there are back, intermediate and fore legs, respectively.
Each iteration step consists of the body position calculation, and the doma ins allowable for placing legs are trun cated according to the following condi tions:
- Reaching the truncated segment
of the domain,
- Non-touching the neighbouring legs;
- Non-touching the surface.
The domains remained after trunca tion must incorporate points which ensure the walker's static stability at the ini tial moment of the state existence $1 It such points exist, a step forward is made. Otherwise a bisection of the itera tion step is made with retrogression on
s .
At the end of the iteration process, the domains allowable for placing legs are narrowed up to the size of an execu tion error, therefore they may be taken to be footholds. The right end of the chosen footholds existence segment signi fies the value of parameter S , to which the iteration process has been reduced.
The left end is S, ·
Conclusions. The algorithms described above were simulated on the display sys tem at the Institute of Appliea Mathema tics, the USSR Acad.Sci. Tests were car ried out by displacing the vehicle along curvilinear trace with a varying radius of curvature, over surface with small domains allowable for placing legs (of the order of 4 per cent of the total area). Simulation has shown that the sys tem described can function in real time and enables to construct the walker's motion for rather complex regimes (turn on place, motion sideways and so on).
R E F E R E N C E S
- D.E. Okhotsimskij, A.K. Platonov, G .K. Borovin, I. I. Karpov, "Computer simulation of a walker's motion", Izv. AN SSSR, Tekhnicheskaja Kibernetika, I972, N 3·
- R.B. McGee, S. S. Sun, "On the problem of selecting a gait for a legged vehicle", Transactions of the VI IFAC Symposium, Erevan, I974.
- 3· D.E. Okhotsimskij, -~ . .!!: . Pl~t0~0·.r, G.K. Borovin, I.I. Karpov, E.1. Kugus-
hev, V.E. Pavlovskij , V.S. Jaroshevskij, "Coordination of the walker's motions", Trudy IV Vsesojuznoj Konferentsii po Bionike", Moscow, I973.
- D.E. Okhotsimskij, A.K. Platonov, "Algorithms for cont,....xolling the wal ker which is capable of overcoming obstacles"', Izv. AN SSSR, Tekhn. Kibernetika, 1973, N 5 (Transactions of the III International Conference on Artificial Intelligence, Stanford,
- USA, I973).
- D.E. Okhotsimskij, A.K. Platonov, G.K. Borovin, I.I. Karpov, E.I. Kugu shev, V.E. Pavlovskij, V.S. Jaroshev skij, "The control of an integrated locomotion robot", Izv. AN SSSR, Tekhn. Kibernetika, 1974, N 6 (Tran sactions of the VI IFAC Symposium, Erevan, I974).
- R.Tomovic, "A general theoretical model of creeping displacement", Cybernetics, 1961, IV, 98-I07.
@inproceedings{ijcai1975p125,
  title     = {Problems of Selecting A Galt For An Integrated Locomotion Robot},
  author    = {Kugushev, E. and Jaroshevskij, V.},
  booktitle = {Proceedings of the Fourth International Joint Conference on
               Artificial Intelligence, {IJCAI-75}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Patrick Winston and Carl Hewitt},
  pages     = {789--792},
  year      = {1975},
  note      = {Robots And Productivity Technology},
  url       = {https://ijcai.org/proceedings/1975/125},
}
TY - CPAPER TI - Problems of Selecting A Galt For An Integrated Locomotion Robot AU - Kugushev, E. AU - Jaroshevskij, V. T2 - Proceedings of the Fourth International Joint Conference on Artificial Intelligence, IJCAI-75 PB - International Joint Conferences on Artificial Intelligence PY - 1975 SP - 789 EP - 792 UR - https://ijcai.org/proceedings/1975/125 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





