
Control Algorithm of the Walker Climbing Over Obstacles
Proceedings of the Third International Joint Conference on Artificial Intelligence. Robot I mplementations. Pages 317-322.
© 1973 International Joint Conferences on Artificial Intelligence
Abstract
The paper deals with the problem of development the multilevel control algorithms for six-legged automatic walker, which provide the walker with the possibility to analyse the terrain profile before it while moving over rough terrain, and to synthesize adequate, rather reasonable kinematics of body and legs for walker's loco motion along the route and climbing over obstacles on its way. DC simulation and analysis of walker's model moving image on DC display scr e en make it possible to evaluate the algorithms developed and to find ways for their improvement. Key words: six-legged walker, DC simulation, control algorithm, data proce s sing, obstacle overcoming.
- I. Muybridge, E., Animals in Motion, Do- ver Co., New York, I957.
- EepHrnTe~H H.A., OomaH o~oMexaH~Ra, M., 1926.
- EepHrnTeMH H.A., 0 nocTpoeH~~ ~B~Re H~A , Me~r~a, 1947.
- Ee pHlliTe~H H.A., O~epK~ no m ~a~onor~~ ~B~R eH~A ~ ~~a~onor~~ aKT~BHOCT~, M ., 1966.
- Hildebrand, M., Symmetrical Gaits of Horses, Science, V. I50, N 3697, pp. 70I- 70B, November I956.
- Hildebrand, M., Analysis of the Sym- metrical Gaits of Tetrapods, Folia Biotheore- tica, V. VI, I966, pp. I-22.
- ToM on~~. P., 0 c~HTese caMo~n~Rym~xcH aBTOMaTOB, ABTOMaT~Ra ~ TeneMeXaH~Ra, T. 26, N~ 2, 1965.
- B. Tomovic, R., McGhee, R.B., A Finite State Approach to the Synthesis of Bioengi- neering Control Systems, IEEE Transactions on Human Factors in Electronics, V. HFE-7, N 2, pp. 65-69, June, I966.
- McGhee, R.B., Finite State Control of Quadruped Locomotion, Simulation, V. 9, N 3, pp. I35-I40, September I967.
- IO. McGhee, R.B., Some Finite State As- pects of Legged Locomotion, Mathematical Biosciences, pp. 67-85, February I968.
- II. Frank, A.A., McGhee, R.B., Some Con- siderations Relating to the Design of Auto- pilots for Le gged Vehicles, Journal of Terra- mechanics, V. 6, N I, pp. 23-35, I969.
- I2. Frank, A.A., Automatic Control of Legged Locomotion Machines, Ph.D. Disserta- tion, University of Southern California, May I968.
- I3. McGhee, R.B., Frank, A.A., Optimum Quadruped Creeping Gaits, University of Sou- thern California, I969. I4. Wilson, D.M., Insect Walking, Annual Review of Entomology, V. II, I966, pp.I03- I22.
- I5. W ilson, D. M., Stepping Patterns in Tarantula Spiders, Journal of Experimental Biology, V. 47, I967, pp. I33-I5I.
- I6. W endler, G., The Coordination of W alking Movements in Arthropods, Symp. Soc. Exp. Biol., V. 20 1 , I966~ pp. 229-250.
- I7. I7. MrHaTDe~ M.E., Ky~aKOB ~.M.~ MHXa~ ~OB A.A., MHxa~mon B.B., IOpeBH1l E.v1., A~ro pHTMH yrrpaB~8HHfl a~aiTTHBHO~ rnaraiD~e~ M8IDHHO~, ~OK~a~~ rrpe~cTan~eHHhl~ Ha IY CHMIT03HYM M~AK ~yopoBHHK ~IOroc~aB~H), I97I.
- IS. Oxou~MCKM¥1 ,ll,.E., n~aTOHOB A.K., E opOB~H r .K.' KapnoB M . M .' M o~e~l1PO B8Hli!e Ha
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
CONTROL ALGORITHM OF THE WALKER CLIMBING OVER OBSTACLES
D.E. Okhotsimski, A.K. Platonov U S S R
Abstract. The paper deals with the prob lem of development the multilevel control al gorithms for six-legged automatic walker, which provide the walker with the possibili ty to analyse the terrain profile before it while moving over rough terrain, and to syn thesize adequate, rather reasonable kinema tics of body and legs for walker's locomoti on along the route and climbing over obstac les on its way. DC simulation and analysis of walker's model moving image on DC display screen make it possible to evaluate the al gorithms developed and to find ways for their improvement.
Key words: six-legged walker, DC simu lation, control algorithm, data proces sing, obstacle overcoming.
The paper deals with the problem of con trol algorithm synthesis for a six-legged walker. It is supposed that the walker is supplied with an onboard digital computer. Rather a complicated algorithm may be used, which provides walking over rough terrain and climbing over some isolated obstacles.It is also supposed that the walker is equipped with a measurement system giving informati on about the terrain relief. Measurement da ta are processed by DC and used when making decision.
An effective method of testing the al gorithms is their simulation on a digital computer with a display unit. It is possible to simulate the walker itself, terrain re lief, measurement system functioning, data processing, decision making and walker con trolling. Observing on the CRT screen the moving image of the vehicle walking over the terrain, it is possible to check the functi oning of the algorithms, to estimate their effectiveness and to find ways for their im provement.
This paper deals with the algorithms in the range from the environment information (input) to the vehicle kinematics (output). The problem of terrain measurement data pro cessing and measurement controlling are also investigated. The simulation results are discussed.
On the first stage of the control algo rithm synthesis it was assumed that all ne cessary information about the terrain relief was got and processed and was kept in the computer memory in the form convenient for its further use in the decision-making algo rithm.
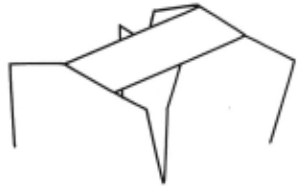
Several types of six-legged walking sys tem were investigated. Schematic image of one of them is seen in Fig. I. All six legs of t he walker have equal geometrical parame ters and equal orientation of the joint axes. Each leg has three degrees of freedom in the joints: two in the hip joint and one in the knee. The first hip-joint axis is perpendicular to the plane of the vehicle body, while the second one is parallel to the body plane and perpendicular to the t high. The knee axis is parallel to the se cond hip-joint axis. The total number of de grees of freedom in six legs amounts to eigh teen. The vehicle body has no kinematic con straints, and therefore it may have six de grees of freedom in its motion relative to the supporting surface.
The walker of this type has rather rich kinematic feasibilities which may be used to provide the vehicle's adaptivity to the ter rain. The problem is to synthesize appropri ate control algorithms which. could organize the walker kinematic in a reasonable way for the effective solving of different locomotion tasks.
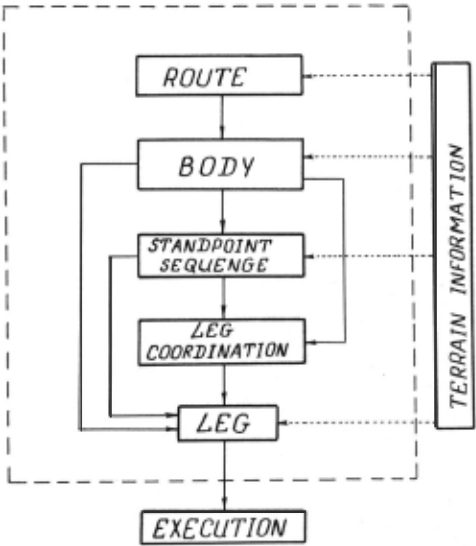
It was reasonable to design control al gorithms as a multilevel hierarchical system. The following 5 levels were adopted:
- Leg. This level is the lowest one.It is necessary to synthesize leg motion during the support and swing phases and to avoid small-size obstacles.
- Leg coordination. This level is high er than the previous one. The leg-coordinati on algorithms provide support scheduling of the legs, i.e. they generate sequences of "up" and "down" times for all legs. The con dition must be satisfied: The stability mar gin of the vehicle should be always no less than a given value.l8
- 3· Standpoint seguence. This level fixes in advance several supporting points on the support surface. In a simple case, if the terrain relief allows it, the level generates a regular standpoint sequence describe~ by two parameters: the gauge width and the stride length. In more complicated cases it is necessary to plan an irregular standpoint se quence, e.g. for some cases of climbihg over obstacles.
- ~· The output of this level is the parameters of motion of the walker's centre of mass both along the route and in vertical direction, and the parameters of body rotati on (pitch, jaw, roll).
- Route. The route planning level is the highest one. Up to now the route of the walker has been planned by an operator.
- Fig. 2 shows interlevel information flow. The complex of control algorithms is dash lined. Dotted lines indicate the flow of ter rain information to different levels.
It was reasonable to begin designing the algorithms from lower levels and then pass on to the higher ones. When testing the algorithms the outputs of higher levels were imitated.
The initial stage of investigation dealt with the leg-control algorithm in the simple case of regular gait of the walker moving along the regular standpoint sequence. The body moved with constant velocity. The imi tation of the l evels higher to the leg-con trol level was, in this case, rather simple.
The leg-control algorithm provided vertical legs adaptation to small-scale terrain roughness.
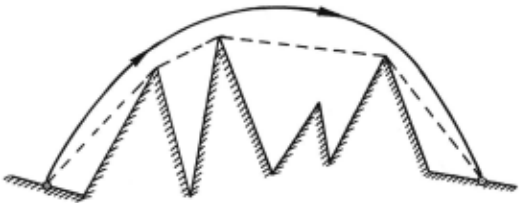
A special block was designed for synthe sizing leg-tip motion during the swing phase in the case of complicated small-scale re lief. The ordinates of the leg-tip trajecto ry (Fig. 3) were calculated as the sum of the ordinates of the convex envelope of the relief (dashed line in Fig. 3) and of the ordinates of a parabola with vertical axis. The parabola was chosen in such a way that its ordinates were equal to zero both in the initial and final points. It was assumed that the horizontal component of the leg-tip velocity was constant during the whole swing phase.
For the second level of leg coordination - the algorithm for support scheduling with prescribed stability margin was designed in a general case for irregular standpoint se quence.
Two types of gait were investigated:
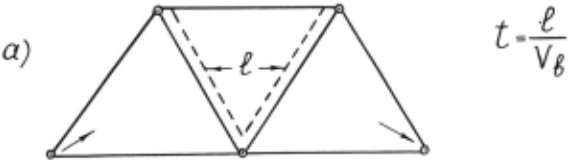
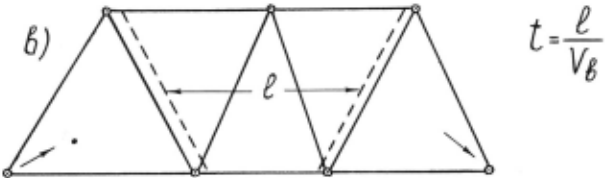
I. Tripod gait. Each of the two tripods consists of foreleg and hind leg of one size and of middle leg of another size. Three legs of the tripod swing simultaneously.Two tripods swing alternately. Fig. 4a illu - strates the adopted logics of calculating "up" and "down" times of the tripod in the case when all legs of the same side use the same standpoint sequence ("step-in-step" type of locomotion). The swing phase of the tripod coincides with the time interval when the projection of the centre of mass of the walker moves between two dashed lines inside the supporting trian~le formed by the legs of the other tripod (Fig. 4a). This logics provides stability margin of prescribed va lue.
2. Wave gait.l 8 The idea of this type of gait was taken from one of the enthomolo gical papers by D. Wilson.l4 The swing waves propagate along the legs of each side of the walker beginning from the hind legs. The hind legs of both sides st·art alternately.
Support scheduling logics is shown in Fig. 4b. The time interval between the start of the hind leg and the standing of the fo releg (wave propagation time) was calculated under condition of prescribed stability mar gin. Two equal intervals of simultaneous support of hind and middle legs, and of mid dle and front legs were subtracted from the wave propagation time. The rest of the time was devided among three legs proportional to their strides (the rule of constant leg tip horizontal velocity.
It should be noted that in special case of regular standpoint sequence the gaits ge nerated both by wave and by tripod a lgo rithms may coincide. But in general case of irregular standpoint sequence a l gorithms synthesize different gaits.
The designed algorithms of this level generated support schedule for both cons tant and variable velocity of the body in general case of curve route. The body rota tion and the vertical component of body ve locity might be taken into consideration.
On the third level two versions of standpoint planning algorithms were designed which were able to generate standpoint se quences for arbitrary curve route on the sup port surface with small-scale roughness. It was assumed that each point of the surface might be used as a standpoint. ·
Some algorithms were designed for gene rating special irregular standpoint sequen ces in case of overcoming obstacles.
The fourth-level algorithms formed body motion for curve route under the above men tioned condition relative to the support surface. Some cased of overcoming obstacles were considered.
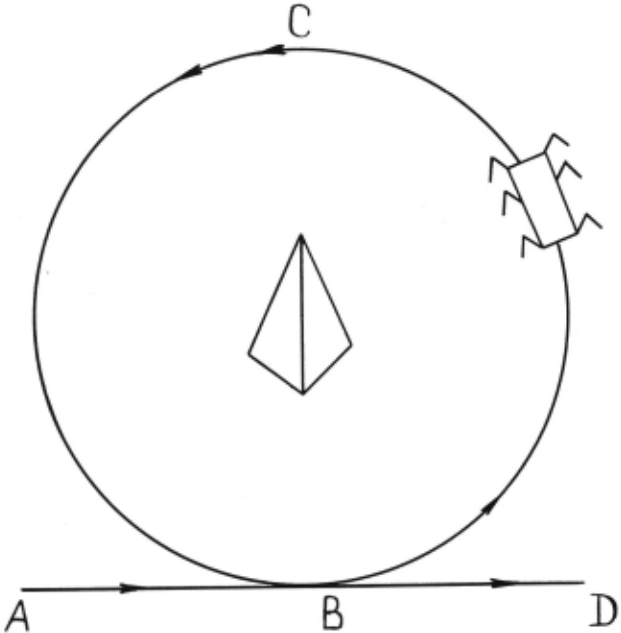
Fig. 5 presents an example of the walk er's locomotion along the curve route. The vehicle moved at first along the rectilinear segment AB. Then, at point B, it changed its route and began walking along the circle of the prescribed radius around the object lo cated inside the circle (part BOB). At point B the walker continued its previous route (segment BD).
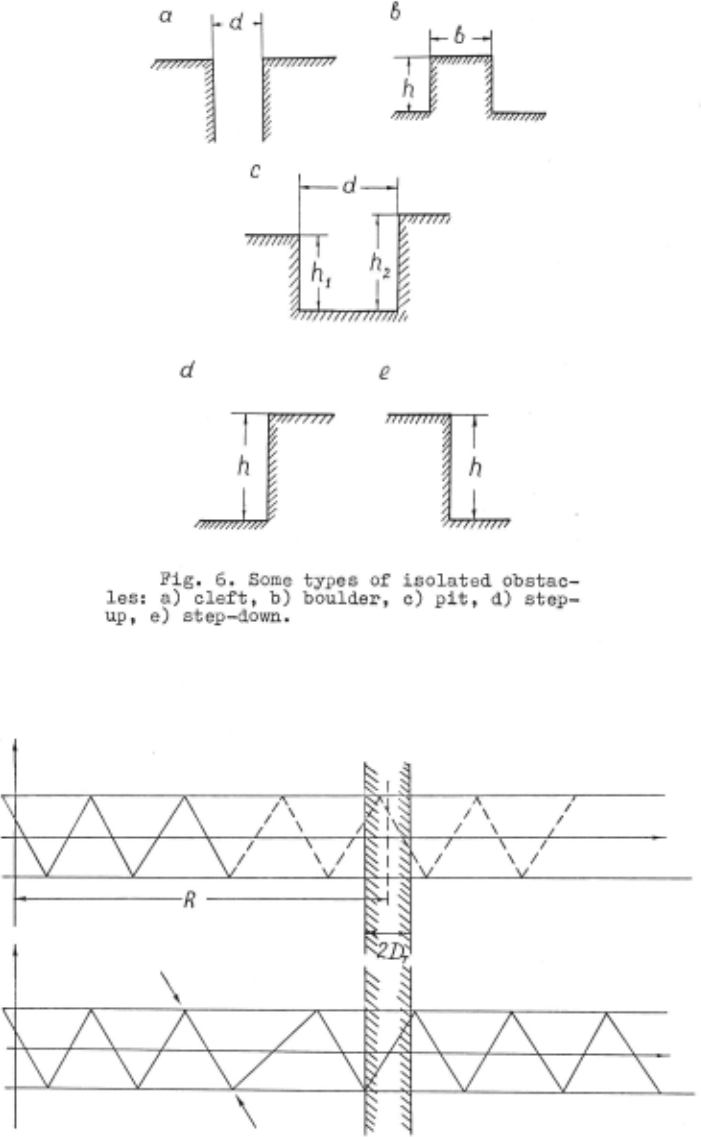
The problem of overcoming isolated ob stacles of some types was investigated. An obstacle may be considered as an isolated one when it is located on the support sur face all points of which might be used as standpoints. For some obstacles it appears undesirable or impossible to use points of the support surface in the vicinity of the obstacle due to geometrical restrictions associated with the neighbourhood of the ob stacle.
Some types of isolated obstacles are shown in Fig. 6. One-parameter obstacle "cleft" (Fig . 6a) is functionally equivalent to the domain forbidden for standing the legs. There are no geometrical restrictions in the vicinity of the "cleft".
Two-parameter obstacle "boulder" (.B'ig. 6b), on the contrary, creates two restricted spots close to it. The spot before the boul der is undesirable because of the possibili ty of contacting the boulder in the support phase. The body of the boulder may make it impossible to stand leg tip in the spot be hind the obstacle. It is permissible to stand legs of. the walker on the boulder; it is even desirable.
The bottom of the three-parameter ob stacle "pit" (Fig. 6c) may be used to stand legs on it except two spots near the walls.
It should be noted that "cleft", "boul der" and "pit" from the geometrical point of view may be regarded as a combination of more simple obstacles of the ty:pes "step in" and "step-down" (Fig . 6d, e). If the longitudinal dimensions of the upper part of the boulder or these of the pit bottom are large enough, the boulder and the pit may be interpreted as two separate isolated obstacles of the "step" type. If the "steps" are positioned rather close one after ano ther, there exists interference between them, and it is, apparently, more reasonable to treat such a combination as a special type of obstacle with its own special method of overcoming.
Some algorithms were designed for deci sion-making concerning the reasonable acti ons of the walker overcoming the obstacle. It was assumed that all necessary informati on about the type and geometrical parameters of the obstacle are available and may be used by decision-making algorithm.
As to the methods of overcoming obsta cles, the basic principle was assumed that the higher level might be involved only in case of real need. For instance, if adapta tion to small scale obstacles can be made by means of level "leg", this must be done. If this appears impossible, the special stand point sequence and appropriate support sche dule must be generated. If necessary, the special body motion has to be used.
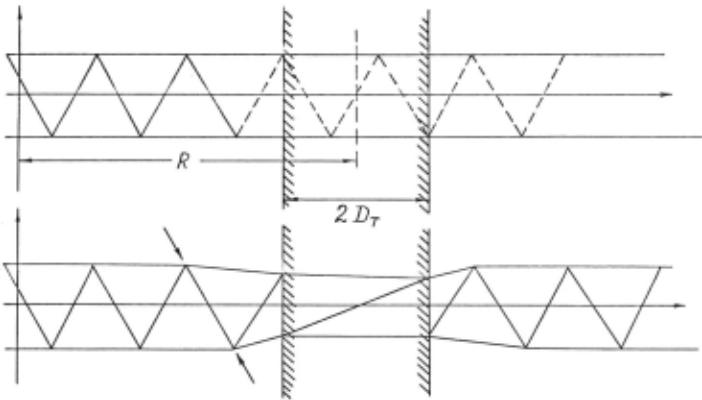
The algorithms for overcoming the cleft t ype obstacle were designed in greater deta~ A special classification block estimated the situation: standpoint sequence parameters, cleft width and its position relative to the walker. Depending on the situation analysis results the following decisions about the regime could be made:
- Nothing has to be changes.
- It is necessary to make longer one stride before the cleft by changing the po sition of two standpoints and shifting them in such a way that one of them, the nearest to the cleft, would be positioned on the brink. The further development of standpoint sequence may be regular, as before the cleft.
- 3· It is necessary to position four standpoints on the brinks of the cleft (two on each brink) and to rearrange some other standpoints.
- To apply regime 3 but to shift standpoints on the brink closer to the axis of the standpoint sequence.
- The body of the walker must be low ered, and regime 4 must be applied.
The standpoint sequences in Fig. 7 cor respond to regime 2, while those in Fig. 8 correspond to regimes. 4 and 5·
The regimes I-5 are listed in order of growth of their complicacy and their feasi bilities. According to the basic principle the classification block tried to find out subsequently the possibility to use regimes I-5, beginning from regime I, and adopted the first of them which provided successful
overcoming the cleft.
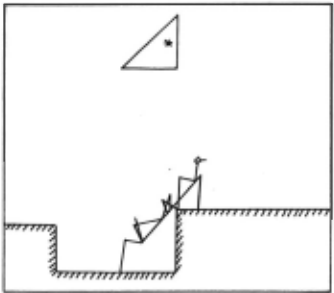
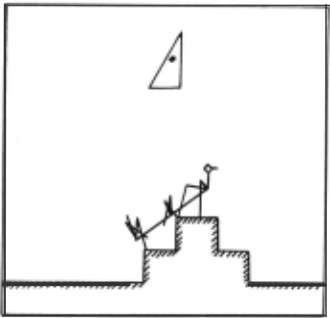
Such an approach is evidently appli cable to designing reasonable methods of overcoming other types of obstacles. It should be noted that for a pit rather deep, or for a boulder rather high, or for an ob stacle like the one in Fig. IO it may be ne cessary to tilt the body of the walker and change its pitch angle in an appropriate way as a function of time (Fig . 9, IO). It is evident that when analysing the obstacle, this regime, as the most complicated one,
has to be tested in the last turn.
Some problems connected with measure ments were investigated: measurement data processing, obstacle identification, measu
rement control.
It was assumed that the measurement sys tem was able to estimate the distance between the fixed point of the vehicle and the point of intersection of the measuring beam and the support surface. The direction of the beam may be constant. When the vehicle walkes, the beam slides over the terrain and measures its profile. But this may be insufficient. The angle between the beam and horizon must be small enough for the vehicle could get ter rain relief information beforehand and has possibility of planning its actions in a rea sonable way. On the other hand, it is clear that for small beam-horizon angle rather long zones after obstacles are inaccessible to re lief measurements. The increasing of the beam-horizon angle diminishes the inaccessible zones but diminishes simultaneously the dis tance between the vehicle and the measured points of the terrain.
Under the circumstances it was reaso nable to control the beam direction for more effective use of measurement system. One of the adopted rules was as follows. All the time when it is possible, some "small" beam horizon constant angle is used. This regime is used as long as the size of inaccessible zones is no more than a given value and each zone can be "overstepped", i.e. overcomed without placing any standpoint inside the zone. If not, the additional measurements must be carried out when approaching nearer to the obstacle. The measuring beam must be inclined steeper to horizon.
If measuring results indicate that it is impossible to place standpoints inside the zone after the obstacle in an appropriate way, the further locomotion is excluded. If appropriate placing the standpoints is pos sible, the walker uses these points for stan ding its legs and walks on.
The investigation carried out confirmed that observing on the display screen the mo vi~g image of the vehicle walking on the ter ra1n is a very effective method for testing the control algorithms and estimating their properties. The motion picture made from the CRT screen of the display unit gives an idea of the walker control algorithms effective ness.
References:
- Muybridge, E., Animals in Motion, Do ver Co., New York, I957.
- EepHrnTe~H H.A., OomaH o~oMexaH~Ra, M., 1926.
- EepHrnTeMH H.A., 0 nocTpoeH~~ ~B~Re H~A , Me~r~a, 1947.
- Ee pHlliTe~H H.A., O~epK~ no m~a~onor~~ ~B~ReH~A ~ ~~a~onor~~ aKT~BHOCT~, M., 1966.
- Hildebrand, M., Symmetrical Gaits of Horses, Science, V. I50, N 3697, pp. 70I70B, November I956.
- Hildebrand, M., Analysis of the Sym metrical Gaits of Tetrapods, Folia Biotheore tica, V. VI, I966, pp. I-22.
- ToMon~~. P., 0 c~HTese caMo~n~Rym~xcH aBTOMaTOB, ABTOMaT~Ra ~ TeneMeXaH~Ra, T. 26, N~ 2, 1965.
- Tomovic, R., McGhee, R.B., A Finite State Approach to the Synthesis of Bioengi neering Control Systems, IEEE Transactions
on Human Factors in Electronics, V. HFE-7, N 2, pp. 65-69, June, I966.
9. McGhee, R.B., Finite State Control of Quadruped Locomotion, Simulation, V. 9, N 3, pp. I35-I40, September I967.
IO. McGhee, R.B., Some Finite State As pects of Legged Locomotion, Mathematical Biosciences, pp. 67-85, February I968.
II. Frank, A.A., McGhee, R.B., Some Con siderations Relating to the Design of Auto pilots for Legged Vehicles, Journal of Terra mechanics, V. 6, N I, pp. 23-35, I969.
I2. Frank, A.A., Automatic Control of Legged Locomotion Machines, Ph.D. Disserta tion, University of Southern California, May I968.
I3. McGhee, R.B., Frank, A.A., Optimum Quadruped Creeping Gaits, University of Sou thern California, I969.
I4. Wilson, D.M., Insect Walking, Annual Review of Entomology, V. II, I966, pp.I03I22.
I5. Wilson, D.M., Stepping Patterns in Tarantula Spiders, Journal of Experimental Biology, V. 47, I967, pp. I33-I5I.
I6. Wendler, G., The Coordination of Walking Movements in Arthropods, Symp. Soc. Exp. Biol., V. 20 1 , I966~ pp. 229-250.
IS. Oxou~MCKM¥1 ,ll,.E., n~aTOHOB A.K., EopOB~H r .K.' KapnoB M .M.' Mo~e~l1POB8Hli!e Ha UBIVI ~BHJKeH~H rnaraiOII\ero anrrapa Ta. JilsBecT~H AKa~eMl!!~ Hay It CCCP, TexH~qeci<aH K~oepHeT~Ka, I972J Bhlrr. 3, CTP,· 47-59.
- I7. I7. MrHaTDe~ M.E., Ky~aKOB ~.M.~ MHXa~ ~OB A.A., MHxa~mon B.B., IOpeBH1l E.v1., A~ro pHTMH yrrpaB~8HHfl a~aiTTHBHO~ rnaraiD~e~ M8IDHHO~, ~OK~a~~ rrpe~cTan~eHHhl~ Ha IY CHMIT03HYM M~AK ~yopoBHHK ~IOroc~aB~H), I97I.
I~. 0XOUl1M CKli!~ ,ll,.E., n~aTOHOB A.K., Eo pOBHH r.K., KaprrOB Jil.M., ]asyTHH IO .M., llaB~OBCKHI B.E., HpornencKH~ B.C. AnropHTMhl yrrpan~eHHH ~BHJKeHHeM rnaraiD~ero arrnapaTa. li1HCTHTYT npli!K~a~How MaTeMaTHKH AH CCCP, IJpenpli!HT N~ 63 38 I972 ro~, MOCKBa.
·
·
·
A
Fig . 5. An example of locomotion along the curve route.
@inproceedings{ijcai1973p41,
  title     = {Control Algorithm of the Walker Climbing Over Obstacles},
  author    = {Okhotsimsky, D. E. and Platonov, Alexander K.},
  booktitle = {Proceedings of the Third International Joint Conference on
               Artificial Intelligence, {IJCAI-73}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Nils J. Nilsson},
  pages     = {317--322},
  year      = {1973},
  month     = {8},
  note      = {Robot I mplementations},
  url       = {https://ijcai.org/proceedings/1973/41},
}
TY - CPAPER TI - Control Algorithm of the Walker Climbing Over Obstacles AU - Okhotsimsky, D. E. AU - Platonov, Alexander K. T2 - Proceedings of the Third International Joint Conference on Artificial Intelligence, IJCAI-73 PB - International Joint Conferences on Artificial Intelligence PY - 1973 SP - 317 EP - 322 UR - https://ijcai.org/proceedings/1973/41 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





