
Design Concept of Direct-Drive Manipulators Using Rare-Earth DC Torque Motors
Proceedings of the Seventh International Joint Conference on Artificial Intelligence. Robotics. Pages 775-777.
© 1981 International Joint Conferences on Artificial Intelligence
Abstract
A direct-drive robotic manipulator (CMU DD Ann) is being" developed at Carnegie-Mellon University. This paper describes the design concept and theory of this new mechanical ann based on the direct-drive method using rare- earth DC torque motors. Because these motors have high torque, light weight and compact size. we can construct robots with far beuer pe rfonnance than those presently avai[pble. For example, we can eliminate all the transmission mechanisms between the motors and their loads. such as reducers and chain belts. and construct a simple mechanism (direct-drive) where the ann links are directly coupled to the motor rotors and stators. This elimination can lead to excellent perfonnance: no backlash, low fraction, low inertia, low compliance and high reliability.
- Asada, H. and Kanade, T. Design of Direc/-Drive Mechanical Arms. Technical Report CMU-RI-TR-81-1, Robotics Institute, CMU, April, 1981.
- Kano, T. Yanagida, H. Rare Earth-l'roperlies and Applicalions. Gihodo Press, 1980.
- Ojima, T ., Tomi1.awa, D .. et.al. Magnetic Properties of a New Type of Rare-Earth Cobalt Magnets. IEEE Transaclions on Magnelics MAG•l3 :1317-1319, 1977.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1. Introduction
Present electrically powered manipulators are still far inferior to human arms and unsatisfactory for many applications in terms of speed, accuracy and versatility. One of the reasons for this poor performance comes from the transmission mechanisms, such as gear trains, lead screws, steel belts, chains and linkages, which arc used to transmit power from the motors to the load and to increase the driving torque. The following problems result from having complicated transmission mechanisms:
- Dynamic response is poor because of the heavy weight and/or high compliance of the transmission.
- Fine movements and pure torque control arc difficult because of the relatively large friction and backlash at the transmission.
- Additional complicated mechanisms for minimizing the backlash arc necessary and they need careful adjustment and regular maintenance.
One of the main reasons for using a transmission mechanism with a nigh gear reduction ratio is that the conventional servo motors provide rather small torque and high speed. Recently, however. high-torque and low-speed motors using new rare-earth magnetic materials (eg. samarium cobalt) have been developed and are becoming available for industrial usc [2) [3]. Since the maximum magnetic energy product is 3 to 10 times larger than with a conventional ferrite or alnico magnet. the rare-earth DC motors have a high output torque, low speed, light weight and compact body. lbcy arc suited for the manipulator drive and will allow elimination of the transmission mechanism.
In this paper, we discuss a manipulator where all the joint axes are directly coup!ed to rotors of rare-earth magnet DC torque motors. First a basic configuration of direct-drive manipulators is shown. Second, we present a design theorv for direct drive manipulators by using a simple kinematic model. We then find an arm structure most suitable for direct drive. Finally, we describe a direct-drive manipulator developed at Carnegie-Mellon University, and verify the theoretical result
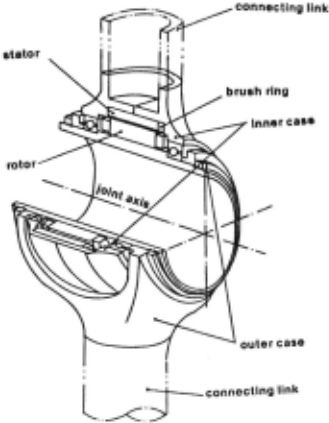
13asically, a direct-drive manipulator consists of a series of active joints whose typical construction is shown in Figure 1. The inner and outer cases are connected to the other joints by CO)lnccting links. The motor illustrated is a DC torque motor which consists of a rotor, a stator and a brush ring. The stator and the brush ring are installed in the inner case, while the rotor is directly coupled to the outer case without any transmission mechanism. Some variations are possible in the joint mechanism. For example, the stator can be attached to the outer case, and the rotor to the inner case. Also, the joint axis can be parallel to the connecting links. In any case, the joint has a simple structure with all the components attached directly to the inner and outer cases.
Since the direct drive method eliminates all the transmission mechanisms and since the load is directly coupled to the actuator output, a direct-drive manipulator is essentially free from the problems which have been caused by the transmission mechanisms: backlash is essentially removed, and compliance is almost zero except at the connecting Unks. Slight Coulomb friction can exist, but only at the bearings supporting the joint axis. Because of its simple structure, a direct-drive manipulator is composed of a much smaller number of mechanical parts. This is .,.,other important advantage of direct drive, because it potentially contributes :" improve the reliability of the manipulator and to make it free from complex maintenance or readjustment One uf the difficulties in developing a direct-drive manipulator is that the motors to drive wrist joints arc themselves loads for the motors at elbow joints and they arc also loads for the motors at shoulder joints. In other words. the load increases rapidly along a series of active joints. An essential i~suc in designing a practical manipulator is to reduce this increasing load. To achieve this reduction we will analyze the series of joint loads and discuss the feasibility of direct drive in the manipulator actuation.
3. Theory for Designing Dil'ect-Drive Manipulators
3. 1. Kinematic Mode!
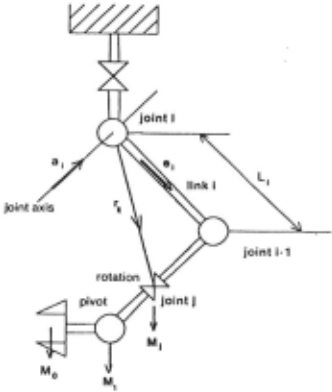
Figure 2 shows a simplified model of direct-drive manipulators where we assum~ .
- The arm consists of a series of point mass (joints) M . connected by straight links without mass. 1
- The joint axes, illustrated by arrows in th'e figure, arc perpendicular or parallel to the links which they connect.
Each joint is numbered I to n from the lip to the base. We call a joint whose axis is perpendicular to the links a pivot, and a joint whose axis is parallel to the links a rotation. In Figure 2, the first joint is a pivot and the second a rotation.
The position vector from joint ito jointj(t)J) is given as follows,
where lk is the length of link k between joints k-1 and k, and ck is a unit vector which points to the direction of link k. 'I1te unit vector ek depends on joint angles 8 k, .... ,8 n'
About the axis of joint i, the moment Tg 1 is developed due to the gravity force of the external load M 0 and a series of point mass from M 1 through M 1 _ 1 :
where a 1 denotes a unit vector which points to the direction of the axis of joint i, g denotes an acceleration vector of gravity, and x and · stand respectively for vector and inner product~. The moment of inertia of the arm about the axis of joint i is
Note that Tg 1 and I 1 depend on joint angles 8 ;s because they include r v·
3.2. Series of Joint Mass
In designing a direct-drive manipulator, maximum torque of each active joint is one of the basic specifications that we should consider. Let us suppose that. for an arbitrary arm configuration, the maximum torque Tm 1 of active joint i must be larger than that required to rotate the joint with a specified angular acceleration a, The maximum torque must also bear the gravity force of the arm. Namely,
All the mass of joints from 1 through i-1 need to be predetermined to compute the above maximum torque, because Tg 1 and I 1 include M 1 for Jg::s;i-1. Therefore the design of the arm drive system should be carried out step by step starting from joint l.
- Give a maximum external load M 0 , and set i= l.
- Compute the required maximum torque Tm 1 by eqs. (2), (3) and (4).
- Select a motor which can develop Tm 1 , and determine the joint mass M 1 by designing the joint housing .·
- Set i= i+ 1, and go back to step 2 while i;:S;n.
As we noted, the active joint i is itself a load for joint i+ I, and both arc then loads for joint i+ 2, and so on. If joint i is heavy in comparison with its output torque, active joint i+ 1 needs to be more powerful and therefore tends to be heavier; this chain is multiplicative. Hence, the required torques for the subsequent active joint increase very fast. Therefore, light weight (as well as high output torque) is an essential requirement for active joints in a direct-drive manipulator.
This observation suggests that we introduce {1, the ratio of mass to peak torque (M/T ratio}, as an index to evaluate the active joint performance;
where Tm is maximum torque, and M is mass of the active jomt.
Now, let us consider a special case where every link is of the same length, all the joints arc pivot\ ami all the joints have the same Mfl' ratio fJ . We can then express analytically a series of joints mass M 1 which satisfies cq. (4). Notice that both the gravity load Tg; and the inertia load I 1 arc maxima when the arm is kept at a level. The weight of motor i is written in the following recursive formula:
Table 1: Weights of motors for all pivotal joints
ii·O. I
| MOtor weight ,____ | iii | ii, | ii3 | ii, | "· | 'M, | lolal(IM 1 ) |
|---|---|---|---|---|---|---|---|
| I | 1.10 | 3 . 61 | 10 . 61 | 30 . 12 | 86 . 09 | 246 . 04 | 378 . 47 |
| 0 . 6 | 0. 65 | I. 60 | 3 . 44 | 7 . 57 | 16 . 50 | 35 . 93 | 66 . 48 |
| '· 26 | 0 . 28 | 0.68 | 1.33 | 2 . 44 | 4. 38 | 7. 82 | 17 . 92 |
In this formula,~. M 1 and Pare made dimensionless by using link tcng·h I, maximum load M 0 and acceleration of gravity g,
Table 1 shows M .'s for~ =0.1 and p = 1, 0.5, and 0.25. The )'oint I - mass increases exponentially with the joint number. When fl = 1, the total arm weight is about 380 times heavier than that of an external object that the arm can carry. If p becomes 112, the total arm weight is drastically reduced to 1~6. 'lbc last joint, M 6 is reduced as much as 117. Thus small Mrr ratio fl is very c!Tcctivc in reducing the series of joints mass.
3.3. Suitable Arm Structure for Direct Drive
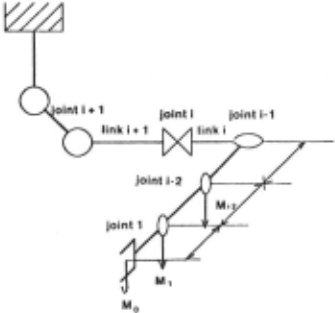
The previous discussion assumed that all the joints were pivots. Now we can investigate how the series of joints mass can be reduced by replcaing some of them by rotational joints. Then we find out what kinematic arm structures arc suitable for direct drive. Consider the case as shown in Figure 3 where joint i is a rotation instead of a pivot Then. only joints from 1 to i-2 arc the loads for active joint i, because the axis of joint i penetrates the point mass i- i and therefore the point mass i-1 is not a load for joint i. Thus the formula forM 1 , in this case, is:
Comparing this with eq. (6), we note that the load for active joint i is reduced. Moreover. the rotational joint i can be placed at any position on links i+ 1 and i. I fit is placed on joint i+ I, joint i is not a load for joint i+ l. In addition, the joint i can be a counter weight for joint i+ 1 if it is placed on the extension line of link i+ 1.
The adjacent joints of a rotational joint must be pivot~. because: two consecutive rotational joints arc equivalent to one. Robot arms with 6 degrees of freedom can have at most three rotational joints. and there are 21 combinations in the arrangement of pivots and rotations. For each case the series of joint mass arc computed. Table 2 lists mass of joints for several structures which contain at least 2 rotational joints. From this t:tblc we can conclude that the arm structure P·R·P·R·P·R from the tip to the shoulder is the lightest and that R·P·R·P·P·R is as light as P·R·P·R·P· R.
4. Development of a Direct-Drive Manipulator
4.1. Investigation of Motors
'Inc feasibility of developing a direct-drive manipulator depends on the performance of motors, which arc the most important components in r.ctivc joints and a key to Reduce the MIT ratio of the active joint. We therefore investigate the ratio of mass of a motor to its peak torque (we call it M M/T ratio) for DC torque motors in the market.
A permanent magnet with a high density of magnetic flux increases output torque and then reduces the MMrr ratio. Recently, we saw a rapid progress in technology of rare-earth cobalt magnetic materials. lbc maximum magnetic energy product of rare earth cobalt is 19 to 30 MGOe, while those of conventional ferrite magnet and alnico magnet are about 3 MGOe, and 5.5 MGOe, respectively. ·Jn fact we camparcd rare· earth and alnico magnet motors in the market which have approximately the same shape and mass. The peak torque for tlte rare-earth magnet motors is about twice as large as that of alnico motors, and therefore their M MIT ratio is reduced to 112. Also, we noticed that the larger-diameter motors have the ~maller MMrf ratio. The extra large alnico magnet motor has a MM/T ratio as small as that of the medium size rare-earth motors.
| •otor weight ~ (ttp)structur•t~aa .. ) | "• | "• | "• | "· | "· | "• | toul |
|---|---|---|---|---|---|---|---|
| R-P-R- P-P-P | o• | I . 20 | I. 20 | 4.24 | 9 . 08 | 19 . 60 | 36 . 41 |
| R- P- P- R- P- P | 1.20 | 2 . 81 | 2 . 61 | 9.22 | 19 . 76 | 36 . 40 | |
| 1.20 | 2 . 81 | &. 68 | 6 . 88 | 20 . 06 | 36 . U | ||
| R-P - P- P- P-A | I. 20 | 2.61 | 6 . 68 | 12.34 | 2.oo" | 25.43 | |
| P-~-P - A-P- P | 0 . 66 | 0. 66 | 2.81 | 2 . 61 | 9 . 08 | 19.48 | 36.86 |
| P-R-P-P-A- P | 0 . 155 | 0 . 66 | 2 . 81 | 6 . 61 | 6 . 81 | 19.78 | 36 . 89 |
| P·R·P·P· P·R | 0 . 66 | 0 . 55 | 2 . 81 | 6 . 61 | 12 . 17 | 2.60 | 26.09 |
| P- P-R- P-A-P | 0 . 65 | 1.60 | t. •o | 6 . 88 | 6 . 81 | 19 . 68 | 36 . 69 |
| P- P- R-P-P - R | 0 . 65 | 1.60 | 1. 50 | 6 . 68 | 12 . 17 | 2 . 73 | 25 . 12 |
| P- P-P - R-P- A | 0.56 | I. 60 | 3 . 44 | 3.44 | 12.34 | 3 . 05 | 26 . 32 |
| 1.20 | I. 20 | 4 . 24 | 4 . 24 | 14 . 69 | 26 . 51 | ||
| R· P ·P·R·P- R | l. 20 | 2 . 61 | 2 . 61 | 9 . 22 | 2 . 31 | 18 . 95 | |
| I. 20 | 1.20 | 4 . 24 | 9 , 08 | 2 . 06 | 18 . 78 | ||
| o . 5' | 2 . 61 | z. 61 | 0.08 | 2 . 32 | 18 . 72 |
4.2. CMU DO Arm
A direct·drive manipulator (CMU DO Arm) was designed based on the above design theory, and is being developed at Camcgic·Mcllon University [1). For joints 1 through 3 we selected motors with rare-earth cobalt permanent magnet and for others alnico magnet motors with a large diameter. 'Inc basic design specifications of the CMU DD Arm are:
- Degrees of freedom:
- Joint structure:
- Pivot:
- Rotation:
- Total length:
- Maximum load:
- Maximum speed:
6 (option 7)
P-R-P-R-P-R
180°
360°
1.7 m
6 kg(4 kg)
4 m/scc at the tip
5. Conclusion
'Inc direct-drive manipulators have potentially a number of excellent features that the present electrically powered robotic manipulators do not nave. However, the development of a practical manipulator requires powerful active joints with light weight We analyzed required torques for a series of active joints by introducing the MIT ratio (ratio of mass to peak torque) of active joints. We also found that the suitable kinematic structures for the direct drive are P-R-P-R-P-R and R-P-R-P-P-R in the case of robots with 6 degrees of freedom.
The CMU direct-drive arm was designed according to these theoretical concepts also taking into account of motors presently available on the markets. However, the practical implementation requires investigation of another problem : heat dissipation. Each joint housing requires a light weight and strong structure with the property of good heat dissipation. This improvement in joint housings as well as more powerful motors will allow us to have robots of lighter weight and higher performance 'than currently available.
Acknowledqements
The authors wish to express their gratitude to Raj Reddy for his constant encouragement and enthusiasm on this project. Ed Kurts, Kasturi Rangan and Phil Spano provided assistance in designing and r')nstructing the CMU arm.
@inproceedings{ijcai1981p149,
  title     = {Design Concept of Direct-Drive Manipulators Using Rare-Earth DC Torque Motors},
  author    = {Asada, Haruhiko and Kanade, Takeo},
  booktitle = {Proceedings of the Seventh International Joint Conference on
               Artificial Intelligence, {IJCAI-81}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Patrick J. Hayes},
  pages     = {775--777},
  year      = {1981},
  month     = {8},
  note      = {Robotics},
  url       = {https://ijcai.org/proceedings/1981/149},
}
TY - CPAPER TI - Design Concept of Direct-Drive Manipulators Using Rare-Earth DC Torque Motors AU - Asada, Haruhiko AU - Kanade, Takeo T2 - Proceedings of the Seventh International Joint Conference on Artificial Intelligence, IJCAI-81 PB - International Joint Conferences on Artificial Intelligence PY - 1981 SP - 775 EP - 777 UR - https://ijcai.org/proceedings/1981/149 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





