
A Knowledge-Based Interactive Robot-vision System
Proceedings of the Sixth International Joint Conference on Artificial Intelligence. .
© 1979 International Joint Conferences on Artificial Intelligence
Abstract
A robot-vision project is reported which incorporates several existing AI methods and some new results. The ambition of the project is a system which can economically complete various intelligent tasks within the scope of mini- and microcomputers. The tuned composition of the applied methods provides a new and powerful approach to RandO, engineering and workshop-operation.
- /M.Ba thor:Hidden-Line Algorithm for a Robot Experiment . Ph.D.Thesis,Budapest, 1977
- /B.G . Baumgart : Geometric Modelling for Computer Vision .Stanford AIM-249, 1974
- /K . S .Fu: Stochastic Tree Languages and Their llfl- plications to Picture Processing.Int.Symp. on Multivariable Anal., Pittsburgh, 1978
- /V.Gallo:A Program for Grammatical PR.4th IJCAI /Tbilisi/ , 1975, pp . 628-634
- /L.Mero:A Quasi-Parallel Contour Following Al- gorithm. AISB/GI Conf.on AI ,Hamburg , l978 , pp. 189-194
- /T . Vamos :Industrial Objects and Machine Parts Recognition,in Applications of Syntactic PR. /Ed .K.S. Fu/ ,Heidelberg ,l977 , pp. 243-267
- /T.Vamos : Automatic Control and AI/invited sur- vey/ .Prepr.of 7th IFAC World Congress /He lsinki/, 1978, ±, pp. 2355-2369
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1. INTRODUCTION
This paper reports on a robot-vision lab for RandO and for experimentation of specialized industrial applications. The system combines many well-known methods of recognition with some own ones /a fast template method, a quasi parallel edge-finder etc./ but this combination provides a sophisticated goal-oriented approach for real-life problem solving.
2. PICTURE PROCESSING, RECOGNITION
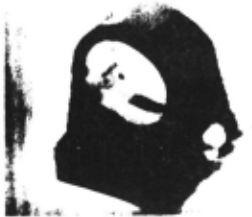
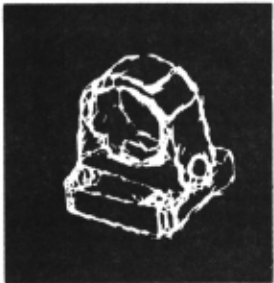
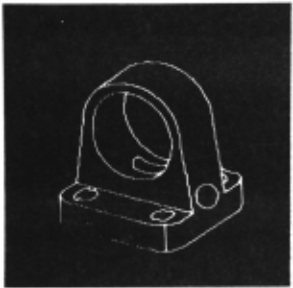
The system is based on man-machine com munication; the goal is the recognition of 3D industrial objects whose number is limited to 10-20 for each task. The objects are taught either by building a geometric model or by a computer-aided transformation of the real situations viewed during the learning period to create a standard model description si milar to the artificial one. The camera input /Fig. 1/ is processed in overlap ping pixels by a simplified version of the Hueckel-operator using only two li near templates. An estimator of the fit coordinates a weight-attribute to the stroke. These weights and some fuzzy like parameters which are attributed to the higher picture-hierarchy are rele vant elements of the heuristic search. The hairy stroke-picture /Fig. 2/ is used both by the brute-force shape estimators which provide a first guess and, by the further picture processing.Nodes of the contour are supposed where the slope-variances of the strokes attain local maxima /Fig. 3/. Streaks along the contour lines are detected by a quasiparallel minimum-cost algorithm oper a ting in parallel between every sup posed node-pair connecte_d by paths.
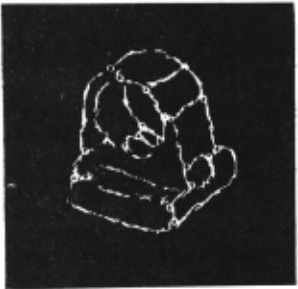
This algorithm is based on a mathemati cal mode l of the expected streaks. The requirements with the paths are ex pressed by four graph-theoretic crite ria which mean that every contour-line should be optimally approximated by a s treak and each of them by only one streak. A potential-field growing algo rithm has been developed in order to find the streaks and it can be proved that the streaks prov ided by this algo rithm satisfy the criteria of the math ematica l model of the streaks. The streaks found using this algorithm are disp l ayed on Fig. 3.
The next preprocessing algorithm merges the streaks either into line segments by uniting the approximately identically directed consecutive strokes or into arcs by comparing the slope differences . This interpretation is generally weakt due to the uncertainty of the whole pro cess ; thus a probability value is as signed to each poss ible interpretation, consider ing that each streak may have various interpretations /Fig . 4/. This value serves for the ordering of hypoth eses in the linguist ic recognition.
Matching the processed picture with the model a nd the who le knowledge base, de cision on the ambigu ities due to multi- I ple or failing edges and areas are solved by linguistic methods. Three ac celerating heuristic tools are applied in directing the search on the problem graph~ a priori information, the wcights with the calculated fuzzy-like estima tion attributes of the picture hierarchy and the pistance measures between pic tures and models. The estimation attrib utes are calculated from the weights of the strokes, considering in each stage /node, streak, edge, picture part/ the reliability of the fit, decomposition and concatenatio~. Several distance measures are distinguished~ brute-force characteristics with their special task oriented combinations, distances similar to those used by Fu I 3 I , distances ob tained from statistics of learning, spe cial measures preprogrammed by the oper ator with the help of his personal expe rience.
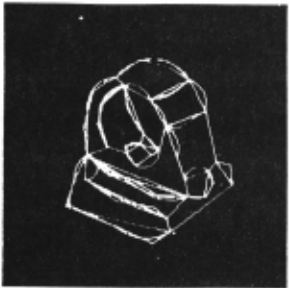
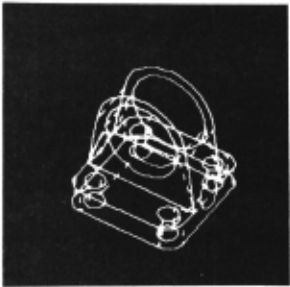
The process of recognition includes the determination of orientation , namely the calculation of the transformation matrix which transforms the position of the model to the real positioR of the object. Model lfng is used not only in the ways initiated by Rober ts and later Baumgart and others but as a general tool for man-machine communication during i/ the system de s ign, ii/ the task learning and iii/ the robot operation . Each l eve l is different in inte lligence ; none o f the levels can disturb its superior one but each has a systematic downward compati ble interactive apparatus based on a graphic d isplay. The graphics is 30-20 oriented: the internal representation and manipulations re f er most ly to the 3D model /Fig . 5/, the different 20 pictures to be matched with the scene are derived from that using a fast hidden line elimination algorithm. This means that all usual 3D operat i ons are imple mented / r o tation , distortion , unifica tion etc./ , adapted specially to our requirements, i. e. r eal time, low storage capacity .
3 . EXPERIMENTAL RESULTS
Robo t c ontrol and hardware are usual not to be detailed here . The system use s a 16 bit 40 kB mini with a 2 us cycle-time /VIDEOTON R-10 licence aft~r the French CII- Mitra-15/ , minidisc , magtape, graphic display.
The who l e recognition procedure needs about 30-50 seconds to recognize an objec t shown e. g. in Fig. 1. The run ning times of the particular algorithms are the following. The hidden line algo r ithm is extremely f as t, it provided e. g . Fig . 6 within 2 seconds. The edge f inding oper ator needs about 4 seconds for processing a TV picture input. The algorithm which assembles the strokes int o streaks requires 10~15 seconds. The grammatica l search ing procedure of find ing the possible faces and the possible ob ject drawings in the streaks' inter p retatio ns takes 5-8 seconds. The other on-line algorithms take less than 1 or 2 seconds altogether.
Experiments have proved t ha t the indi cated heuristic s earch results in a time requirement depending statistically li nearly on the ob ject'complexity, number of objects, number of ambiguities /edge~
interpretations , s hadows , partial obser vations/. A successful guess /e . g. a brute-force estimator/ can cut short occasionally all further trials. In u n fortunate cases the interaction of the operator is als o possible.
4. APPLICATIONS
The system is primarily assembly-orient ed. Other applications o f our r esults that already work are being realized re cently~ a .Tecr;>.gni tion system in a bus body factory identifying the meta l sheets for contro lling a painter robot and a man-machine system in neuro-biolo gical research which should detect neu ronal nets in microscope-sections.
@inproceedings{ijcai1979p203,
  title     = {A Knowledge-Based Interactive Robot-vision System},
  author    = {Vámos, Tibor and Báthor, Miklos and Méro, László},
  booktitle = {Proceedings of the Sixth International Joint Conference on
               Artificial Intelligence, {IJCAI-79}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Bruce G. Buchanan},
  year      = {1979},
  month     = {8},
  url       = {https://ijcai.org/proceedings/1979/203},
}
TY - CPAPER TI - A Knowledge-Based Interactive Robot-vision System AU - Vámos, Tibor AU - Báthor, Miklos AU - Méro, László T2 - Proceedings of the Sixth International Joint Conference on Artificial Intelligence, IJCAI-79 PB - International Joint Conferences on Artificial Intelligence PY - 1979 UR - https://ijcai.org/proceedings/1979/203 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





