
Cycles in Liquid Democracy: A Game-Theoretic Justification
Proceedings of the Thirty-Fifth International Joint Conference on Artificial Intelligence. Main Track. Pages 3350-3358.
https://doi.org/10.24963/ijcai.2026/372
Keywords
- Game Theory and Economic Paradigms: Noncooperative games
- Game Theory and Economic Paradigms: Computational social choice
Abstract
A common criticism of liquid democracy within the relevant academic literature is that delegation cycles can occur, seemingly resulting in unused voting power. Yet, practitioners argue that delegation cycles are not only unproblematic but are even formed intentionally by participants. To bring theory closer to reality, we introduce a model that captures this strategic behavior under uncertainty. We study the existence, structure and quality of Nash equilibria, revealing that delegation cycles naturally emerge. To complement these findings, we perform computational experiments using best-response dynamics.
- [Abramowitz and Mattei, 2025] Ben Abramowitz and Nicholas Mattei. Flexible representative democracy. Social Choice and Welfare, 64(1):263-308, 2025.
- [Anshelevich et al., 2021] Elliot Anshelevich, Zack Fitzsimmons, Rohit Vaish, and Lirong Xia. Representative proxy voting. In Proceedings of the AAAI Conference on Artificial Intelligence, volume 35, pages 5086-5093, 2021.
- [Behrens et al., 2014] Jan Behrens, Axel Kistner, Andreas Nitsche, and Björn Swierczek. The principles of LiquidFeedback. Inter- aktive Demokratie, 2014.
- [Behrens et al., 2022] Jan Behrens, Axel Kistner, Andreas Nitsche, and Björn Swierczek. The temporal dimension in the analysis of liquid democracy delegation graphs. The Liquid Democracy Journal, (7), 2022.
- [Behrens, 2015] Jan Behrens. Circular delegations-myth or disas- ter? The Liquid Democracy Journal, (3), 2015.
- [Bersetche, 2022] Francisco M Bersetche. Generalizing liquid democracy to multi-agent delegation: A voting power measure and equilibrium analysis. arXiv preprint arXiv:2209.14128, 2022.
- [Bloembergen et al., 2019] Daan Bloembergen, Davide Grossi, and Martin Lackner. On rational delegations in liquid democracy. In Proceedings of the AAAI Conference on Artificial Intelligence, volume 33, pages 1796-1803, 2019.
- [Blum and Zuber, 2016] Christian Blum and Christina I. Zuber. Liquid democracy: Potentials, problems, and perspectives. Jour- nal of Political Philosophy, 24(2):162-182, 2016.
- [Brill et al., 2022] Markus Brill, Théo Delemazure, Anne-Marie George, Martin Lackner, and Ulrike Schmidt-Kraepelin. Liquid democracy with ranked delegations. In Proceedings of the AAAI Conference on Artificial Intelligence, volume 36, pages 4884- 4891, 2022.
- [Caragiannis and Micha, 2019] Ioannis Caragiannis and Evi Micha. A contribution to the critique of liquid democracy. In Proceedings of the 32nd International Joint Conference on Artificial Intelligence (IJCAI), pages 116-122, 2019.
- [Christoff and Grossi, 2017] Zoé Christoff and Davide Grossi. Bi- nary voting with delegable proxy: An analysis of liquid democ- racy. In Proceedings of the Conference on Theoretical Aspects of Rationality and Knowledge (TARK), 2017.
- [Cohensius et al., 2017] Gal Cohensius, Shie Manor, Reshef Meir, Eli Meirom, and Ariel Orda. Proxy voting for better outcomes. In Proceedings of the International Conference on Autonomous Agents and Multiagent Systems (AAMAS), pages 858-866, 2017.
- [Colley et al., 2022] Rachael Colley, Umberto Grandi, and Ari- anna Novaro. Unravelling multi-agent ranked delegations. Au- tonomous Agents and Multi-Agent Systems, 36(1):1-35, 2022.
- [Colley et al., 2023] Rachael Colley, Théo Delemazure, and Hugo Gilbert. Measuring a priori voting power in liquid democracy. pages 2607-2615. Proceedings of the International Joint Confer- ence on Artificial Intelligence (IJCAI), 2023. IJCAI
- [Dey et al., 2021] Palash Dey, Arnab Maiti, and Amatya Sharma. On parameterized complexity of liquid democracy. In Proceed- ings of the Conference on Algorithms and Discrete Applied Math- ematics, pages 83-94, 2021.
- [Elkind et al., 2022] Edith Elkind, Martin Lackner, and Dominik Peters. Preference restrictions in computational social choice: A survey. arXiv preprint arXiv:2205.09092, 2022.
- [Escoffier et al., 2019] Bruno Escoffier, Hugo Gilbert, and Adèle Pass-Lanneau. The convergence of iterative delegations in liq- uid democracy in a social network. In Proceedings of the 12th International Symposium on Algorithmic Game Theory (SAGT), pages 284-297, 2019.
- [Escoffier et al., 2020] Bruno Escoffier, Hugo Gilbert, and Adèle Pass-Lanneau. Iterative delegations in liquid democracy with re- stricted preferences. In Proceedings of the AAAI Conference on Artificial Intelligence, volume 34, pages 1926-1933, 2020.
- [Green-Armytage, 2015] James Green-Armytage. Direct voting and proxy voting. Constitutional Political Economy, 26(2):190- 220, 2015.
- [Grossi et al., 2026] Davide Grossi, Andreas Nitsche, and Georgios Papasotiropoulos. Modeling liquid democracy: A survey of the (computational) social choice literature. In Proceedings of the International Joint Conference on Artificial Intelligence, 2026. https://gpapasot.github.io/ld-comsoc/. IJCAI Link
- [Jain et al., 2022] Pallavi Jain, Krzysztof Sornat, and Nimrod Tal- mon. Preserving consistency for liquid knapsack voting. In Pro- ceedings of the European Conference on Multi-Agent Systems (EUMAS), pages 221-238, 2022.
- [Kahng et al., 2021] Anson Kahng, Simon Mackenzie, and Ariel Procaccia. Liquid democracy: An algorithmic perspective. Jour- nal of Artificial Intelligence Research, 70:1223-1252, 2021.
- [Köppe et al., 2024] Matthias Köppe, Martin Kouteckỳ, Krzysztof Sornat, and Nimrod Talmon. Fine-grained liquid democracy for cumulative ballots. In Proceedings of the 23rd International Conference on Autonomous Agents and Multiagent Systems (AA- MAS), page 1029-1037. IFAAMAS, 2024.
- [Kotsialou and Riley, 2020] Grammateia Kotsialou and Luke Riley. Incentivising participation in liquid democracy with breadth-first delegation. In Proceedings of the International Conference on Autonomous Agents and MultiAgent Systems, pages 638-644, 2020.
- [Koutsoupias and Papadimitriou, 2009] Elias Koutsoupias and Christos Papadimitriou. Worst-case equilibria. Computer science review, 3(2):65-69, 2009.
- [Markakis and Papasotiropoulos, 2025] Evangelos Markakis and Georgios Papasotiropoulos. As Time Goes By: Adding a Tem- poral Dimension to Resolve Delegations in Liquid Democracy. In Proceedings of the International Conference on Algorithmic Decision Theory (ADT), pages 48-63, 2025.
- [Noel et al., 2021] Jonathan A Noel, Mashbat Suzuki, and Adrian Vetta. Pirates in wonderland: Liquid democracy has bicriteria guarantees. In Proceedings of the International Symposium on Algorithmic Game Theory (SAGT), pages 391-405, 2021.
- [Papasotiropoulos and Schmidt-Kraepelin, 2025] Georgios Papa- sotiropoulos and Ulrike Schmidt-Kraepelin. Liquid democracy: An annotated reading list. ACM SIGecom Exchanges, 22(2):130- 135, 2025.
- [Tyrovolas et al., 2024] Giannis Tyrovolas, Andrei Constantinescu, and Edith Elkind. Unravelling expressive delegations: Complex- ity and normative analysis. In Proceedings of the AAAI Con- ference on Artificial Intelligence, volume 38, pages 9918-9925, 2024.
- [Utke and Schmidt-Kraepelin, 2023] Markus Utke and Ulrike Schmidt-Kraepelin. Anonymous and copy-robust delegations for liquid democracy. Proceedings of the Conference on Neural Information Processing Systems (NeurIPS), 36:69441-69463, 2023.
- [Yamakawa et al., 2007] Hiroshi Yamakawa, Michiko Yoshida, and Motohiro Tsuchiya. Toward delegated democracy: Vote by your- self, or trust your network. Proceedings of the International Jour- nal of Human and Social Sciences, 1(2):146-150, 2007.
- [Zhang and Grossi, 2021] Yuzhe Zhang and Davide Grossi. Power in liquid democracy. In Proceedings of the AAAI conference on Artificial Intelligence, volume 35, pages 5822-5830, 2021.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Liquid democracy is a flexible voting system that allows voters to vote directly or delegate their vote to another participant, who can vote on their behalf. Delegations are transitive, meaning that delegated votes can be delegated further, creating delegation chains. The voter at the end of a chain casts ballots on behalf of everyone in the chain. This system combines the advantages of direct democracy and representative democracy by giving voters the freedom to choose their own mode of participation [Blum and Zuber, 2016].
Over the past decade, academic interest in liquid democracy has grown rapidly [Grossi et al., 2026; Papasotiropoulos and Schmidt-Kraepelin, 2025]. However, practitioners have noted that some parts of this literature overlook or misinterpret key aspects of liquid democracy as it is implemented in practice [Behrens et al., 2014; Behrens, 2015]. While liquid democracy is often applied over an extended period of time to an ongoing stream of decisions, much of the literature models it as a one-time event. This divergence has led to differing views on the issue of delegation cycles. In the literature, delegating and voting are frequently modeled as mutually exclusive options. Consequently, delegation cycles (i.e., a situation where a voter i delegates to j, and this delegation eventually returns to i through a chain of delegations) are seen as problematic because none of the voters in the cycle eventually casts a vote, leaving their collective voting weight unused. In contrast, Behrens et al. [2022] propose an alternative interpretation (informed by their experience with the LiquidFeedback platform): voters specify default delegations that remain fixed across multiple decisions. These default delegations serve as a fallback whenever voters do not cast a vote; if a voter casts a vote, their default delegation is ignored. Under this interpretation, like-minded voters who trust one another may intentionally form delegation cycles with their default delegations. These cycles rarely result in lost votes for actual decisions, since all the voting weight in the cycle is used as long as at least one of the involved voters casts a vote.
To bridge theory and practice, we introduce the default delegation model. Voters declare delegations for a future election, which will be used only if they do not participate themselves. To model uncertainty about who will participate in this election, each voter has a fixed probability of participating in the election. A voter's utility thus depends on both (i) other voters' delegation choices and (ii) who actually turns out to vote. We assume that participants live in a (one-dimensional) metric space and prefer to be represented by those who are close to them. Moreover, voters can have different tolerance levels towards being represented by faraway voters. While the model is not explicitly temporal, analyzing strategic behavior in this probabilistic setting can shed light on long-term delegation dynamics. In a world with a stream of similar elections, where each voter participates in only a fraction of them and participation is not highly correlated, equilibrium states in our model can serve as proxies for long-term behavior across the election stream.
We provide theoretical evidence supporting the practical observation that delegation cycles naturally arise among rational users of liquid democracy platforms. More concretely, within the default delegation model, we provide a gametheoretic analysis of how voters can strategically set their default delegations to ensure that their voting power ends up with casting voters whose preferences closely align with their own. We study (i) existence, (ii) structure, and (iii) quality of (pure) Nash equilibria and demonstrate that, under mild assumptions, delegation cycles are necessarily formed. Our findings are complemented by computational experiments, providing additional insights into best-response dynamics.
1.1 RelatedWork
Recent research in (computational) social choice and beyond shows a growing interest in liquid democracy, with various models and methodologies emerging. We focus on studies that are related to ours in terms of these two aspects.
The Role of Cyclic Delegations. A key branch of the literature addresses delegation cycles, typically viewing them as undesirable and proposing solutions to eliminate them [Brill et al., 2022; Christoff and Grossi, 2017; Colley et al., 2022; Dey et al., 2021; Jain et al., 2022; Köppe et al., 2024; Kotsialou and Riley, 2020; Markakis and Papasotiropoulos, 2025; Tyrovolas et al., 2024; Utke and Schmidt-Kraepelin, 2023]. All of these works distinguish between delegating and casting voters and focus on axiomatic and algorithmic aspects, rather than strategic behavior. Notably, the work by Markakis and Papasotiropoulos [2025], like ours, was directly motivated by the study of Behrens et al. [2022]. They study a temporal model with delegation updates over discrete time-steps. By contrast, in our paper, the temporal aspect is captured through the probabilistic model for ballot casting. Other approaches prevent cycles by design: Abramowitz and Mattei [2025] disallow transitive delegations; Kahng et al. [2021] only allow delegations to voters with higher competence; Caragiannis and Micha [2019] assume the existence of a mechanism preventing cyclic delegations.
One-Dimensional Spatial Models. To model voters' preferences over potential delegates, we assume that voters are positioned in a one-dimensional metric space. This is a common modeling choice (often representing ideological alignment), used in delegative voting settings by Yamakawa et al. [2007], Green-Armytage [2015], Cohensius et al. [2017], Escoffier et al. [2020], and Anshelevich et al. [2021].
Strategic Delegation Behavior. A prominent line of research in liquid democracy employs a game-theoretic perspective. Specifically, this includes work that analyzes Nash equilibria of delegation games [Bersetche, 2022; Bloembergen et al., 2019; Escoffier et al., 2019; Escoffier et al., 2020], provides worst-case guarantees [Noel et al., 2021], or studies voting power [Zhang and Grossi, 2021; Colley et al., 2023]. However, the games that these works consider are significantly different from the ones we analyze. None of them models the strategic choice of delegates under probabilistic voter participation. For instance, prior utility models are based on the effort of voting [Bloembergen et al., 2019] or are analyzed in purely deterministic settings [Escoffier et al., 2019; Escoffier et al., 2020].
1.2 Our Contribution
Our central contribution is conceptual: we introduce the novel default delegation model for liquid democracy. It captures and explains strategic delegation behavior under uncertain participation-a feature inherent in real-world liquid democracy systems. To provide insights into the occurrence, merits, and soundness of cycles, and to establish the first principled justification for their emergence, we analyze the following:
Existence of Nash Equilibria. Our computational experiments suggest that Nash equilibria are prevalent across a broad range of synthetic instances. In Section 3, on the negative side, we identify instances where a Nash equilibrium does not exist, even in simple settings with only three voters, or where all voters have identical tolerance levels. On the positive side, we establish the existence of Nash equilibria in several special cases or slight variants of our original model.
Structure of Nash Equilibria. In Section 4, we prove that, under mild assumptions, strategic voters form delegation cycles in equilibrium. More precisely, every non-trivial component of an equilibrium delegation graph contains exactly one cycle. Furthermore, we show that relaxing any of the assumptions invalidates the result, and we provide additional insights into the structure of delegations at equilibrium. In more general settings, computational experiments reveal that the vast majority of components contain cycles. The width of these cycles appears to be proportional to voters' tolerance levels and inversely proportional to the number of voters.
Quality of Nash Equilibria. In Section 5 we evaluate the quality of Nash equilibria primarily in terms of their social welfare, i.e., the total utility they achieve, and we measure the Price of Anarchy (PoA), i.e., the ratio between the best possible social welfare and the social welfare of equilibria. While we prove that the PoA is generally unbounded, we also provide strong positive results: for non-degenerate instances, the difference between the two quantities is bounded, and as voting probabilities increase or tolerance levels decrease, the welfare in equilibrium approaches the optimal social welfare. Moreover, our experiments show that Nash equilibria often achieve close-to-optimal social welfare.
Omitted proofs and details can be found in the full version. To show how they complement the theory, our experimental findings are presented right after the results they support.
2 The Default DelegationModel
We consider a finite set V of voters using a liquid democracy platform. Each voter nominates a default delegate for a future election, in which any voter may choose to vote or abstain. If a voter i ∈ V does not vote, their voting power is passed to their default delegate, continuing transitively until a voter who casts a vote is reached-this voter is called i's ultimate delegate. If no one in the delegation chain votes, i has no ultimate delegate and their voting power is lost.
Default Delegations. For each voter i, we let d(i) ∈ V denote their default delegate. Self-nominations (d(i) = i) are allowed and interpreted as abstentions from nominating a default delegate. Each delegation profile d = (d(i))i∈V naturally corresponds to a (directed) delegation graph Gd = (V, {(i, d(i)) | i ∈ V }) whose edges correspond to default delegations. Thus, each vertex of Gd has out-degree exactly 1 and self-nominations correspond to self-loops.
Ultimate Delegates. Assume that the set of voters casting a vote is known, and let X ⊆ V denote this set. The default delegations of voters in X are irrelevant. Therefore, to resolve delegations for this election-that is, to determine which voters in V \ X are ultimately represented by which casting voters in X under d-it suffices to consider the subgraph of Gd that only contains delegations from noncasting voters. For each non-casting voter i ∈ V \ X, we can identify their ultimate delegate by following the (unique) directed walk in this graph starting from i. If this walk leads to a casting voter j ∈ X, then j is the ultimate delegate of i. If the walk leads to a cycle or a self-loop, 1 then i has no ultimate delegate. Each casting voter has a voting weight in the examined election equal to the number of voters for whom they are the ultimate delegate, themselves included.
Probabilistic Participation. A crucial ingredient of our model is the assumption that voters do not know which other voters are casting a vote in the future election. Rather, when choosing a default delegate, they need to consider different possibilities of where their vote "ends up". To capture this uncertainty, we use a simple probabilistic model. Namely, we assume that each voter i ∈ V casts a vote with a fixed probability pi ∈ [0, 1]. We let p = (pi)i∈V denote the profile of vote-casting probabilities. A voter i with pi ∈ {0, 1} is called deterministic. This modeling choice reflects the idea that, in practice, many (independent) elections occur, and voters are not aware of or engaged in every single one of them. The probability pi then can be thought of as the fraction of elections in which voter i typically participates. This probabilistic approach provides a simple way to model varying voting behavior without requiring complex assumptions about individual awareness or decision-making for each election.
Given a delegation profile d and a voter i ∈ V , we can now derive the probability distribution over i's ultimate delegates. Let π(d, i) denote the longest simple path in Gd starting at i. Then, π(d, i) is the unique sequence (y0, y1, · · · , yk) of distinct voters starting with y0 = i and satisfying the following:
Voter i's ultimate delegate is the first casting voter along the path π(d, i). Therefore, for ℓ ∈ {0, 1, · · · , k}, the probability that voter yℓ is the ultimate delegate of i is given by
The ultimate delegate of i is undefined with probability ∏kr=0 (1 - pyr ), which we interpret as i's ballot being lost.
Distance and Tolerance. To evaluate and compare different delegation options, we assume that each voter's utility depends on the alignment between their preferences and those of their ultimate delegate. Alignment is defined in terms of the Euclidean distance between voters along a onedimensional ideological space, represented as the interval [0, 1]. Each voter i ∈ V is associated with a fixed position xi ∈ [0, 1], reflecting their ideological stance, which remains constant throughout all elections. Let x = (xi)i∈V denote positions. The utility of a voter decreases as the distance between their position and that of their ultimate delegate increases, capturing the notion that voters prefer representatives who are ideologically closer to themselves. Essentially, a voter's utility is single-peaked [Elkind et al., 2022] at their own location, decreases linearly within a fixed radius, and drops to zero beyond that threshold. We view this as a natural first modeling step and refer to Section 6 for extensions.
1 We use the term "cycle" exclusively for closed paths involving at least two vertices, excluding self-loops from this definition.
Each voter i ∈ V is associated with a tolerance parameter τi ⩾ 0. This represents the maximum distance the voter is willing to accept between their own position and that of their ultimate delegate, while still deriving positive utility from delegating. Let dist(i, j) = |xi -xj | be the distance between voters i and j, and let τ = (τi)i∈V . The acceptability set of voter i is given by: Ai(x, τ) = {j ∈ V | dist(i, j) ⩽ τi}.
Instances. Given the voters' positions x, their voting probabilities p, and their tolerance parameters τ , we define an instance as the triple I = ⟨x, p, τ ⟩. To avoid ties, we will always assume that our instances are in general position, meaning that no two voters share the same position and that no voter j ̸= i is at distance exactly τi from voter i. 2 Further, we will sometimes assume that j belongs to Ai(x, τ ) if and only if i belongs to Aj(x, τ). If this holds for all pairs of voters, then we say that the instance satisfies mutual acceptance. A special case of mutual acceptance instances are those where all voters have identical tolerance parameters (τi = τj for all i, j ∈ V ); we will refer to such instances as symmetric. We often assume that voters are ordered by increasing xi, and then specify p and τ as vectors corresponding to that order.
Voter Utility. The utility of a voter from a realization of the random election is defined as their tolerance minus the distance to their ultimate delegate, or 0 if the ultimate delegate is undefined. In other words, voters rank potential ultimate delegates by proximity and prefer abstaining over delegating to a voter outside their acceptability set. Formally, given positions x, tolerances τ , and the set X of casting voters, the utility of voter i under a delegation profile d is τi - dist(i, j), where j ∈ X is the ultimate delegate of i, or 0 if no ultimate delegate is defined. Due to probabilistic participation, the ultimate delegate of voter i is a random variable (distributed according to Expression (1)). To account for this randomness, we define the expected utility of voter i as the weighted sum of their utilities over all possible ultimate delegates. Specifically, the expected utility of voter i (henceforth, simply utility) in an instance I can be expressed as
where (y0, y1, · · · , yk) are the voters along the path π(d, i). When the instance I is clear, we refer to ui(d, I) as ui(d). Normalization would not affect our results on NE existence and structure. The social welfare of a profile d in I is the sum over voter utilities, SW(d, I) = ∑i∈V ui(d, I). The profile maximizing it among all possible profiles for I will be called optimal and denoted by dSW (I), or simply dSW .
Example 1. Consider an instance with six voters, V = {A,B,C,D,E, F}. The positions x and voting probabilities p are depicted below, together with the delegation graph Gd of the delegation profile d with d(A) = B, d(B) = C, d(C) = A, d(D) = E, d(E) = D, d(F ) = F .
2 If an instance is not in general position, then slightly perturbing some entries of x will bring the instance into general position.
Suppose that for a given election, the set of casting voters is {A, F}. This situation happens with probability pA · pF · Πi∈{B,C,D,E}(1 - pi) = 0.8 · 0.3 · 0.7 · 0.8 · 0.7 · 0.9 ≈ 0.085. In this scenario, A has a voting weight of 3 and F has a voting weight of 1. The voting weights of D and E cannot be allocated to a casting voter and are lost.
Assume that τi = 0.25 for all i ∈ V . Then the acceptability set of voter D is AD(x, τ) = {B,C,D,E}. The expected utility of voters A and F w.r.t. the delegation profile d is uA(d) = 0.8 · 0.25 + 0.2 · 0.3 · (0.25 - 0.1) + 0.2 · 0.7 · 0.2 · (0.25 - 0.2) ≈ 0.21 and uF (d) = 0.3 · 0.25 = 0.075.
3 Existence of Nash Equilibria
We start our game-theoretic analysis of the default delegation model. We define the concept of best responses and profitable deviations in a standard way. We denote by d-i the profile d not including the choice of i, and by (d-i, d′ (i)) the delegation profile in which all voters except i delegate according to d, whereas i delegates to d′ (i).
Definition 1. For a voter i ∈ V, d′ (i) is a best response to delegation profile d if and only if it maximizes ui(d-i, ·). We say that d′ (i) is a profitable deviation from d for voter i if ui(d-i, d′ (i)) > ui(d).
Building on the notion of profitable deviations, we are ready to define (pure) Nash equilibria. We focus on pure (rather than mixed) equilibria, not only because they are the standard starting point for strategic reasoning on a novel model, but also because practical implementations of liquid democracy typically require deterministic delegations, making pure equilibria an appropriate model of real-world delegation behavior.
Definition 2. A delegation profile d is a Nash equilibrium (NE) if no voter i ∈ V has a profitable deviation from d.
Through our initial example, we highlight that equilibria are not necessarily unique and that different equilibria may have different graph-theoretic structures.
Example 1 Continued. The delegation profile d from Example 1 is a Nash equilibrium, since each voter chooses a best response, as shown in Table 1. Note that equilibrium delegations need not go to the closest voter. Interestingly, d is not the only NE of this instance. It can be verified that d′ , whose delegation graph Gd′ is shown below, is also an NE. We highlight that two equilibria might significantly differ. For instance, Gd′ has two (weakly) connected components, in contrast to Gd. Moreover, d and d′ differ in terms of social welfare, casting voters' weights and expected number of votes that are lost.
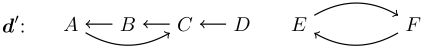
| A | B | C | D | E | F | |
|---|---|---|---|---|---|---|
| A | 0.200 | 0.210 | 0.202 | 0.195 | 0.194 | 0.179 |
| B | 0.159 | 0.075 | 0.163 | 0.083 | 0.081 | 0.023 |
| C | 0.089 | 0.086 | 0.050 | 0.089 | 0.086 | 0.014 |
| D | 0.052 | 0.086 | 0.075 | 0.075 | 0.085 | 0.064 |
| E | -0.084 | -0.043 | -0.055 | 0.066 | 0.025 | 0.039 |
| F | -0.134 | -0.102 | -0.111 | 0.067 | 0.069 | 0.075 |
Experimental Analysis of NE Existence. To get a first impression of whether Nash equilibria exist in general, we carried out computational experiments using a best-response dynamic. That is, the process starts with some delegation profile (e.g., a random one) and then iterates over the voters, updating their delegation whenever there is a profitable deviation. The process stops when no voter can make a profitable deviation, which results in a Nash equilibrium by definition. Interestingly, running our best-response dynamics on 20,000 different (mutual acceptance) instances for various values of n, x, p, and τ , and starting profiles, has always led to the identification of a Nash equilibrium. The details are deferred to the full version.
Non-Existence of Equilibria. In contrast to what we observed in our computational experiments sketched above, Nash equilibria do not always exist in the default delegation model. To showcase this, we provide the following example and later strengthen the result in Theorem 2.
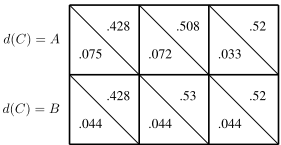
Example 2. The instance I with V = {A,B,C,D}, x = (0, 0.05, 0.1, 0.5), p = (0.4, 0.05, 0.2, 0.4) , τ = (1, 0, 0.2, 0) does not admit an NE. Assume for contradiction that d is an NE in I. Then, in d, the voters B and D must delegate to themselves as τB = τD = 0, i.e., delegating to any other voter lowers their utility compared to self-delegation. Further, since τC = 0.2, dist(C,D) = 0.4 and d(D) = D, voter C does not delegate to D. Both A and C do not delegate to themselves. This is because τA - dist(A,B) > 0, τC - dist(C, B) > 0, and d(B) = B, implying that choosing to delegate to B provides better utility than self-delegation. In the following table, we show the utilities of A and C in all profiles that were not ruled out by the previous reasoning.
Given this impossibility result, we focus on subclasses of the default delegation model or slight variations towards obtaining positive results on the existence of Nash equilibria.
3.1 Special Cases
We discuss three special cases of the default delegation model and draw a complete picture of whether these restrictions suffice to guarantee the existence of equilibria. We study (i) deterministic instances, i.e., those where pi ∈ {0, 1} for all i ∈ V , (ii) mutual acceptance instances, i.e., those where j ∈ Ai(x, τ) if and only if i ∈ Aj(x, τ) for all i, j ∈ V , and (iii) instances with few voters, i.e., those instances where |V | is upper bounded by a constant. On the positive side, such restrictions can guarantee the existence of an NE.
Theorem 1. For each of the following restrictions, any instance I is guaranteed to admit a Nash equilibrium, which is moreover computable in polynomial time:
- (i) I is deterministic,
- (ii) I has two voters, i.e., |V | = 2, or
- (iii) I satisfies mutual acceptance and |V | ⩽ 3.
In deterministic instances, the profile where every noncasting voter (i.e., with pi = 0) delegates to their closest casting voter (i.e., with pj = 1) in their acceptability set is an NE. For two-voter instances, we show that the expected utility of a voter is not influenced by the delegation choice of the other. For mutual acceptance instances with three voters, we propose a greedy algorithm for finding an NE. While these restrictions are strong, we complement Theorem 1 by showing that relaxing them even slightly invalidates the result.
Theorem 2. There exists an instance I for which no Nash equilibrium exists if
- (i) I has three voters, i.e., |V | = 3, or
- (ii) I satisfies mutual acceptance and |V | = 4.
We remark that statement (ii) of Theorem 2 holds even for symmetric instances, i.e., with voters of equal tolerance.
3.2 Variants of the Model
In response to these negative results, we discuss two variants of our model that guarantee the existence of NE. These are relevant in certain real-world contexts, but mainly serve a theoretical purpose: demonstrating the tightness and minimality of Example 2 and complementing Theorem 2.
Directional Acceptability. In the default delegation model, a voter accepts representation by voters positioned both to their left and to their right, only dependent on their distance. We introduce a variant of the model, where each voter selects a direction and accepts representation only by voters in that direction, in which case the utility is still determined by the distance, in line with Expression (2). Depending on the direction selected, we refer to a voter as leftist or rightist. To motivate the setting further, we note that beyond the political spectrum the positional line can instead represent a hierarchy or organizational seniority, where participants may delegate only upward and, e.g., set a personal cutoff allowing delegation to a supervisor or manager but not to executive levels.
In Example 2, voter A can be considered a rightist and voter C can be considered a leftist as AC(I) only includes voters to their left. Hence, NE may not exist in instances with both leftists and rightists. However, Theorem 3 shows that any instance with only leftists or only rightists admits an NE.
For the sake of concreteness, we define an example of a utility function that induces leftist voters. Namely, replace (τi - dist(i, yℓ)) in Expression (2) (intuitively, the utility of voter i for being represented by yℓ in a specific election) by:
We remark that Theorem 3 holds for any utility model that assigns negative utility to representation on the one side and utility equal to τi - dist(i, yℓ) to the other.
Theorem 3. Every instance in which the voters are all leftists or all rightists admits a Nash equilibrium, computable in polynomial time.
The proof of Theorem 3 constructs a Nash equilibrium by starting from a profile where everyone delegates to themselves, and then finding best responses for all voters sequentially in order of their position.
Proxy Voting. We now move to another variant of the model in which Nash equilibria are guaranteed to exist. In the proxy voting setting, we restrict the number of voters on any path π(d, i) that leads to a casting voter. Specifically, no such path is allowed to contain more than two voters (including voter i themselves). Hence, we effectively restrict the strategy space of the voters based on the actions of the other voters. This restriction is reminiscent 3 of the well-established framework of proxy voting [Cohensius et al., 2017; Anshelevich et al., 2021], a variant of liquid democracy in which voters are divided into delegating and casting voters and delegation chains may contain at most 2 voters. This setting aligns with implementations in blockchain governance and delegated Proofof-Stake systems, where voters delegate to designated actors (e.g., active voters, token-holder representatives, or validators) who, by design, cannot delegate further, resulting in delegation chains of minimal length.
In Example 2, delegation chains of three voters arose. By forbidding such chains, we effectively eliminate the issue that leads to the non-existence of equilibria. In the proxy voting setting, we guarantee the existence of Nash equilibria, leading to a dichotomy in the maximum allowable delegation chain length to ensure the existence of Nash equilibria.
Theorem 4. In the proxy voting setting, every instance admits a Nash equilibrium, computable in polynomial time.
4 Structure of Nash Equilibria
We now focus on the structural properties of equilibria. In particular, we are interested in the existence of cycles in delegation graphs corresponding to Nash equilibria. Our first result establishes that delegation cycles are the rule, rather than the exception. This aims to provide a compelling gametheoretic explanation for the prevalence of cycles and the behavior of voters observed in practice.
Theorem 5. Consider a mutual acceptance instance I without deterministic voters. Then, for every Nash Equilibrium d of I, it holds that every weakly connected component of Gd with more than a single vertex has exactly one cycle.
3 The settings are not identical as we allow for length 2 cycles.
Proof Sketch. Assume there is an acyclic weakly connected component W of Gd with at least two voters. Then, W would form a tree with a "sink" voter i such that d(i) = i. By analyzing the incentives of voter i, we derive that j /∈ Ai(x, τ) for any j such that d(j) = i. But, by the mutual acceptance assumption, it must also hold that i /∈ Aj(x, τ), which contradicts d being an equilibrium. Uniqueness follows from the fact that each vertex in the component has out-degree 1.
When the assumptions of Theorem 5 do not hold, cycles do not necessarily exist in every equilibrium.
Observation 6. Cycles are not guaranteed to exist in Gd, where d is an NE of an instance that is not of mutual acceptance or where deterministic voters exist.
However, in mutual acceptance instances, at least one equilibrium with a cyclic structure is guaranteed to exist, even with some deterministic voters. The proof is similar to that of Theorem 5 and includes the observation that deterministic voters may be indifferent between delegation options.
Theorem 7. Consider a mutual acceptance instance I admitting an NE. Then, there exists an NE d of I in which every weakly connected component of Gd with more than a single vertex has exactly one cycle.
Without mutual acceptance, the existence of equilibria exhibiting cycles is not guaranteed. For example, consider an instance with two non-deterministic voters such that A accepts B, but B does not accept A. Then, there is a unique equilibrium in which A delegates to B and B self-loops.
Returning to the case where the assumptions of Theorem 5 hold, we now aim to further analyze the structure of equilibria by turning our attention to delegations "entering" a cycle. Specifically, for a weakly connected component W, let C(W) denote the set of voters forming the cycle within that component, and let L(W) and R(W) denote the sets of voters of W positioned to the left and right of the cycle, respectively. Formally, L(W) = {i ∈ W : xi < xj for all j ∈ C(W)} and R(W) = {i ∈ W : xi > xj for all j ∈ C(W)}.
Theorem 8. Consider a mutual acceptance instance I without deterministic voters and a Nash equilibrium d of I. Consider a weakly connected component W of Gd that consists of more than a single vertex, and let C(W) denote the cycle in W. There is at most one vertex vL ∈ L(W) with d(vL) ∈ C(W) and at most one vertex vR ∈ R(W) with d(vR) ∈ C(W). Moreover, in Gd, L(W) and R(W) form in-trees rooted at vL and vR, respectively.
Thus, the cycle C(W) has a unique "entry point" vL for voters in L(W), and all voters in L(W) have delegation paths to vL (analogously for vR and R(W)). It might be tempting to conjecture that these entry points vL and vR delegate to the leftmost and rightmost voters in C(W), respectively, or that all voters in L(W) (respectively, R(W)) form a simple delegation path. However, in the full version, we show that this is not generally the case. Therefore, a significant strengthening of the structural description offered by Theorem 8 is unlikely.
Experimental Analysis of NE Structure. Our theoretical results do not specify how large delegation cycles are or how often they occur in instances not satisfying the assumptions of Theorem 5. We address these questions experimentally in general instances (see the full version for details). We examined the size (i.e., number of vertices) and width (i.e., maximum distance between two vertices) of cycles and weakly connected components and we observed that, as tolerance levels decrease, cycle size and width, as well as component width, decline gradually. Moreover, as n increases, the average cycle and component width decreases, with voters in the same component-especially cycles-having closely aligned positions. The proportion of voters with self-loops remains stable at around 5%. The average cycle size stays around 4.9 across instances and grows as n increases. Notably, nearly all weakly connected components with more than one vertex contain a cycle, indicating that the pattern identified theoretically for mutual acceptance instances (see Theorem 5) also appears in randomly generated instances.
5 Quality of Nash Equilibria
We next focus on evaluating the quality of equilibria. For the theoretical analysis we use a Price-of-Anarchy approach to compare the social welfare of Nash equilibria to the optimal social welfare [Koutsoupias and Papadimitriou, 2009]. First, we observe a contrast between the structure of social-welfaremaximizing delegation graphs and of Nash equilibria.
Observation 9. There exist mutual acceptance instances without deterministic voters in which social welfare maximizing delegations do not induce cycles; e.g., in the symmetric instance with V = {A, B, C}, x = (0.12, 0.5, 0.88), p = (0.1, 0.9, 0.1), and τi = 0.4 for all i ∈ V , social welfare is maximized if A and C delegate to B, who self-loops.
Recall that dSW(I) is a profile maximizing social welfare and let dNE(I) be a Nash equilibrium of I achieving the lowest social welfare among all NE. We define the Price of Anarchy (PoA) of an instance I in the standard way
and show that this ratio can be arbitrarily large.
Theorem 10. The Price of Anarchy of default delegation instances is unbounded.
Proof Sketch. We proceed by describing a family of instances parametrized by n and λ ∈ R>1/n2 . In the limit for n → ∞, the worst NE d satisfies SW(d) → 0. Further, we show there is a parameterized profile d′ such that the social-welfaremaximizing delegation profile dSW satisfies SW(dSW) ⩾ SW(d′ ) → λ, for n→∞.
We fix a value for λ and then define In as the instance with voters {1, 2, . . . , n+1} and x, p, τ as shown below. Note that voters are equidistant: dist(i, i+1) = 1/n2 , for all i ∈ [n].
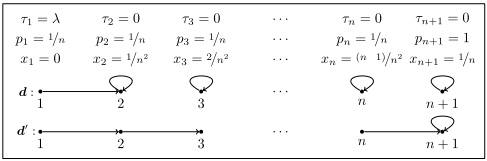
The profile d with d(1) = 2 and d(i) = i for all i ⩾ 2 is a Nash equilibrium. Since ui(d) = 0 for all i ⩾ 2, we get
For the profile d′ with d′ (n + 1) = n + 1 and d′ (i) = i + 1 for i ⩽ n, we get ui(d′ ) n→∞ ----→ 0 for all i ⩾ 2 and u1(d′ ) =
The calculation details are deferred to the full version.
At first glance, Theorem 10 is a negative result concerning the quality of NE. However, the constructed instances have certain characteristics, such as a voter with a very low voting probability and all but one voter having acceptability sets limited to themselves, while voter 1 has A1(x, τ) = V . Moreover, the social welfare of the two delegation profiles in the proof of Theorem 10 exhibit a relatively small absolute difference (λ = ∑i∈V τi). This suggests that measuring the difference rather than the ratio may yield better conclusions about the quality of equilibria. We define the additive Price of Anarchy of an instance I as PoA+(I) = SW(dSW(I)) - SW(dNE(I)), and proceed with the following positive results on both the multiplicative and the additive Price of Anarchy; 4 with the latter bound being essentially tight.
Theorem 11 asserts that higher voting probabilities correlate with better Nash equilibria in terms of social welfare. Furthermore, and perhaps surprisingly, the smaller the tolerance levels, the better the additive PoA bound.
We have assessed the expected number of votes cast in equilibria, showing that, unlike in other liquid democracy frameworks where cycles are criticized for resulting in ballot loss, in our setting, they effectively help mitigate lost voting power. Also, results on the structure of optimal delegation profiles, complementing Observation 9, can be found in the full version, further highlighting differences from NEs and vote-loss-minimizing profiles.
Experimental Analysis of NE Quality. To complement our worst-case bounds, we move beyond PoA and examine how the social welfare achieved by NEs (in particular under the best-response dynamic) compares to the optimal social welfare in randomly generated instances. Since identifying dSW is computationally infeasible when n is large, we approximate it by the sum of each voter's expected utility under their optimal delegation profile, denoted by ODP(I). Formally, ODP(I) = ∑i∈V ui(di∗ ), where di∗ is a delegation profile maximizing the utility of voter i. It holds that Gdi∗ contains a path that starts in i and passes through all vertices in Ai(x, τ ) in increasing order of distance to i. This value serves as an upper bound of SW(dSW) and does not necessarily correspond to a feasible delegation profile.
4 While PoA+ is not explicitly normalized by utility, the bound in Theorem 11 implicitly is, since ∑i∈[n] τi is a trivial upper bound for social welfare.
| Number of Voters | τi ∈ [0, τmax] with τmax = | ||||||
|---|---|---|---|---|---|---|---|
| 20 | 50 | 100 | 200 | 1 | 0.75 | 0.5 | |
| dBR | 97.6% | 98.8% | 99.4% | 99.7% | 98.9% | 98.9% | 98.6% |
| ddir | 53.6% | 49.6% | 50.4% | 50.5% | 51.2% | 51.6% | 52.3% |
We generated 100 instances for each n ∈ {20, 50, 100, 200}, with values for x, p, τ chosen uniformly at random. For n = 50, we also tested 5 tolerance vectors τ , scaling each by 0.75 and 0.5 to assess the effect of different tolerance levels (details on the instances can be found in the full version of the work). For each instance, we computed ODP(I) as an upper bound on the social welfare and an NE dBR via best-response dynamics. Table 2 shows the average ratios SW(dBR)/ODP(I). As a baseline, we also include the social welfare achieved by the delegation profile ddir ("direct voting") in which every voter self-loops.
As expected, the Nash equilibrium profiles outperform the direct voting profiles, which consistently reach only around 50% of ODP(I). The average social welfare achieved by dBR is remarkably high (⩾98% of ODP(I)) and gets closer to ODP(I) as n increases. Given that ODP(I) upper bounds the optimal social welfare, we conclude that Nash equilibria in our model achieve almost optimal social welfare.
6 Conclusion
We introduced the default delegation model and used it to provide a novel game-theoretic perspective on strategic delegation decisions in liquid democracy. We revealed how delegation cycles naturally emerge among rational participants, offering a justification for their existence.
Our model leads to several avenues for future research. One of them is to explore the computational complexity of finding equilibria or delegation profiles maximizing social welfare. In our experiments, we use best-response dynamics to find equilibria; however, these algorithms are not guaranteed to converge. It would also be interesting to define voters' alignment based on more general metric spaces; e.g., the Euclidean plane. Preliminary experiments reveal that the structure of equilibria becomes more complicated in that setting. Considering alternative utility functions could yield further insights. Examples include normalized utility, nonlinear functions of distance, and functions incorporating voting costs, voting behavior of the ultimate delegate, or the resulting election outcome. The probability of casting a ballot could also be part of the strategy space of a voter. Finally, while we primarily focused on cycles, long delegation paths remain an important and underexplored aspect of liquid democracy, as they may be associated with eroding trust in ultimate delegates.
Acknowledgments
We thank Andreas Nitsche for helpful discussions. Rachael Colley has been supported by the ANR JCJC project SCONE (ANR 18-CE23-0009-01) and the grant EP/X013618/1 from the Engineering and Physical Sciences Research Council. This project has received funding from the European Research Council (ERC) under the European Union's Horizon 2020 research and innovation programme (grant agreement No 101002854). Grzegorz Lisowski acknowledges support by the European Union under the Horizon Europe project Perycles (Participatory Democracy that Scales). Georgios Papasotiropoulos was supported by the European Union (ERC, PRO-DEMOCRATIC, 101076570). Views and opinions expressed are, however, those of the authors only and do not necessarily reflect those of the European Union or the European Research Council. Neither the European Union nor the granting authority can be held responsible for them. Ulrike Schmidt-Kraepelin was supported by the Dutch Research Council (NWO) under project number VI.Veni.232.254.
@inproceedings{ijcai2026p372,
  title     = {Cycles in Liquid Democracy: A Game-Theoretic Justification},
  author    = {Brill, Markus and Colley, Rachael and George, Anne-Marie and Lisowski, Grzegorz and Papasotiropoulos, Georgios and Schmidt-Kraepelin, Ulrike},
  booktitle = {Proceedings of the Thirty-Fifth International Joint Conference on
               Artificial Intelligence, {IJCAI-26}},
  publisher = {International Joint Conferences on Artificial Intelligence Organization},
  editor    = {Diego Calvanese},
  pages     = {3350--3358},
  year      = {2026},
  month     = {8},
  note      = {Main Track},
  doi       = {10.24963/ijcai.2026/372},
  url       = {https://doi.org/10.24963/ijcai.2026/372},
}
TY - CPAPER TI - Cycles in Liquid Democracy: A Game-Theoretic Justification AU - Brill, Markus AU - Colley, Rachael AU - George, Anne-Marie AU - Lisowski, Grzegorz AU - Papasotiropoulos, Georgios AU - Schmidt-Kraepelin, Ulrike T2 - Proceedings of the Thirty-Fifth International Joint Conference on Artificial Intelligence, IJCAI-26 PB - International Joint Conferences on Artificial Intelligence Organization PY - 2026 SP - 3350 EP - 3358 DO - 10.24963/ijcai.2026/372 UR - https://doi.org/10.24963/ijcai.2026/372 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





