
Collective AI: context awareness via communication
Proceedings of the Nineteenth International Joint Conference on Artificial Intelligence. Pages 1464-1469.
© 2005 International Joint Conferences on Artificial Intelligence
Abstract
Communication among participants (agents, robots) is central to an appearance of Collective AI. In this work we deal with the development of local communication mechanisms for real microrobotic swarms. We demonstrate that despite of very limited capabilities of the microrobot, the specific construction of communication hardware and software allows very extended collective capabilities of the whole swarm. We propose mechanisms providing information content and context for collective navigation, coordination and spatial perception in a group of microrobots.
- [Bonabeau et al., 1999] E. Bonabeau, M. Dorigo, and G. Ther- aulaz. Swarm intelligence: from natural to artificial systems. Oxford University Press, New York, 1999.
- [Doyle and Dean, 1996] J. Doyle and Th. Dean. Strategic direc- tions in artificial intelligence. ACM Comput. Surv., 28(4):653- 670, 1996.
- [Fu, 2005] Zh. Fu. Swarm-based computation and spatial decision making. Master Thesis, University of Stuttgart, Germany, 2005.
- I-Swarm, 2003 2007]
- I-Swarm. I-Swarm: Intelligent Small World Autonomous Robots for Micro-manipulation, 6th Framework Programme Project No FP6-2002-IST-1. European Communi- ties, 2003-2007.
- [Kornienko et al., 2004] S. Kornienko, O. Kornienko, and P. Levi. About nature of emergent behavior in micro-systems. In Proc. of the Int. Conference on Informatics in Control, Automation and Robotics (ICINCO 2004), Setubal, Portugal, 2004.
- [Kornienko et al., 2005] S. Kornienko, O. Kornienko, and P. Levi. Ir-based communication and perception in microrobotic swarms. In submitted to IROS 2005, Canada, 2005.
- [Kube, 1996] C.R. Kube. A minimal infrared obstacle detection scheme. The Journal for Robot Builders, 2(2):15-20, 1996.
- [Megabitty, 2005] Megabitty. see http://groups.yahoo.com/group/megabitty/. 2005. Link
- [Nembrini et al., 2002] J. Nembrini, A. Winfield, and C. Mel- huish. Minimalist coherent swarming of wireless connected au- tonomous mobile robots. In Proc. Simulation of Artificial Behav- iour, Edinburgh, 2002.
- [Payton et al., 2001] D.W. Payton, M. Daily, R. Estowski, M. Howard, and C. Lee. Pheromone robotic. Auton. Robots, 11(3):319-324, 2001.
- [Pradier, 2005] M. Pradier. Collective Classification in a Swarm of Microrobots. Master Thesis, University of Stuttgart, Germany, 2005.
- [Sahin, 2004] E. Sahin. Swarm Robotics: From sources of inspi- ration to domains of application. Springer-Verlag, Heidelberg, Germany, 2004.
- [Suzuki et al., 1995] S. Suzuki, H. Asama, A. Uegaki, S. Kotosaka, T. Fujita, A. Matsumoto, H. Kaetsu, and I. Endo. An infra-red sensory system with local communication for cooperative multi- ple mobile robots. In Proc. of International Conference on Intel- ligent Robots, pages 220-225, 1995.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Communication is the central issue in collective systems such as collective/swarm robotics, multi-agent systems, sensor networks and so on. Communication provides and supports (among others) "awareness" about relevant events, collective decision making and coordination in a group, execution of cooperative activities, etc. Due to communication all robots/agents behave in a coordinated way like one "organism", they can even emerge new behavior types [Kornienko et al., 2004]. There are many phenomena that appear in this way; in the vast literature they are denoted as collective/swarm intelligence [Bonabeau et al., 1999].
In this paper we investigate the communication mechanisms for large microrobotic swarm [I-Swarm, 2003 2007]. Due to very small size and limited capabilities of microrobots, swarm robotics differs from other collective robotic systems in a couple of essential points [Sahin, 2004]. The most important are inaccessibility of global coordinates, global perception and global communication. Despite of the "very limited intelligence" of individual microrobots, the collective intelligence of the whole swarm does not change essentially. The swarm is still able for distributed spatial sensing, collective decision making, building spatial formation, coordinated acting and so on. This swarm intelligence primarily appears due to specific communication between robots. We are interested in the following question: "Which communication mechanisms among microrobots do allow emerging collective properties of a swarm ?"
Generally for AI and especially for "swarm intelligence" not only the transferred message is important ("I find something"), but also the context of the message ("where is it found") [Doyle and Dean, 1996]. One robot cannot provide this context, because e.g. it does not know its own position. Retrieving and providing this context represents also the collective task performed during communication. However not all communication approaches can provide the context of information and can generally be implemented in a swarm. In this paper we demonstrate that the well-known packagebased routing is not useful for swarms and suggest instead an approach that "diffuses" information with its context.
Achieving collective capabilities in real microrobotic systems, we are very limited by hardware. Therefore not all approaches from AI domain are feasible here. The second question of this paper is "Which collective capabilities a swarm are feasible by very limited communication hardware ?" We demonstrate that the specific composition between multi-directional communication hardware and "diffusing" software protocols allows emerging some interesting spatial and functional collective capabilities of a swarm.
The rest of the paper is organized as follows. In Section 2 we investigate the local communication between robots. Sections 3, 4 and 5 are devoted for describing the hardware platform, logical protocols and communication context. Finally, in Section 6 we discuss some preliminary experiments and conclude our work.
2 Information diffusion, swarm density and communication radius
For collective systems a communication plays the role of nervous system in human body. Since microrobots in a swarm can communicate only locally with their neighbors, such a "swarm nervous system" can be produced only by a mechanism that propagates information through multiple robotrobot connections. Parameters of a global circulation of information (like global propagation speed or global propagation time) depend on characteristics of local communication (communication radius Rc, the number of robots within Rc). In this section we derive this relation, which is necessary for further development of the robot's communication hardware.
Since parameters of local communication between robots depend on their behavior, we differentiate three following behavioral cases:
- Robots move only in small areas, so called clusters. In this case robots are situated more or less closely to each other, so that swarm peer-to-peer network (SPPN) is created "automatically". The main problem is a communication between such clusters.
- Robots move in large areas (typical swarm scenario). Robots exchange information only when they meet each other. The inter-cluster communication belongs to this case.
- Part of robotic swarm purposely creates and supports the SPPN. This is the most interesting case, that provide stable communication in swarm (see more in Section 6).
In the further calculation we consider the most hardest case of a large-area swarm. We can intuitively assume that the communication radius Rc, the swarm density Dsw, the robots motion velocity v and the time t are closely related in propagating the information. For deriving a relation between them, we take several analogies to molecular-kinetic theory of ideal gas, more exactly diffusion in ideal gas (by these analogies we denote also a "diffusion of information"). We introduce the following notions: the sensor radius Rs, where a collision-avoiding procedure is started; lc the length of free path from the start of motion till the first communication contact; ls the length of free path from the start of motion till the first collision-avoiding contact; nc and ns are correspondingly the number of communication and collision-avoiding contacts; Sc and Ss are the area of the "broken" rectangles built by a motion in some time interval t with Rc and Rs. In Figure 1(a) we sketch our consideration. Firstly, we are in-
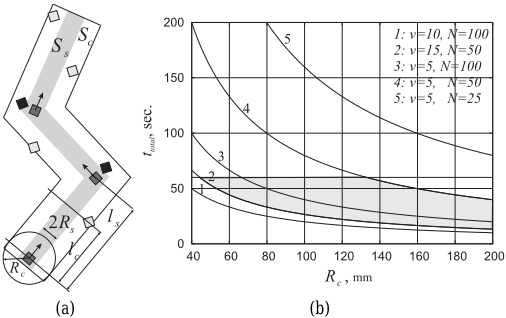
terested in the number of communication contacts nc happen during the motion. This value is equal to the average number of robots in the area Sc, nc = ScDsw, where Dsw is the swarm density. We assume that the collision avoiding radius and the robot's rotation radius are small so that we can neglect the area of fractures. In this case Sc = 2Rcυt. Dsw can be calculated as the number of robots N in swarm divided by the area available for the whole swarm Ssw:
In the relation (1) we assume only one robot moves whereas other are motionless. More exact relation, when all robots move, differs from (1) only by the numeric coefficient √2 (as proved by Maxwell for a diffusion in ideal gas). For the further calculation we use nc = 2√2RcυtN Ssw . Now we have to estimate how the information will be propagated after the first communication contact. This propagation dynamics is similar to "epidemic infection" dynamics, estimated as the series:
and written iteratively as
that is the "standard" exponential form (nc +1)n . We are interested in the case when all robots are "infected" (nc+1)n ≥ N or n = log(nc+1)N. From real experiments we know that for establishing a communication contact and transmitting messages, robots need some time pt, that can be measured experimentally. The information transfer starts when the first robot "infects" one additional robot(nc = 1); the time till the first infection tfirst and the total time ttotal = n tfirst+Npt for infecting the whole swarm can be obtained as:
In the performed simulations (pt = 0), the swarm areal is 800 × 650 pixels2 , N = 50 with Dsw ≈ 10 pix./sec., Rc = 40 pix. Formula (4) gives us ttotal ≈ 52 sec.. In many performed simulation cycles we observed ttotal between 30 and 90 sec. Formula (4) is also useful in estimating the energy needed for each robot. For example, swarm during the running time has to propagate 100 different messages; it takes about 2 hours in the mentioned example. So the power supply should provide energy at least for 2 hours.
For developing a real microrobotic swarm we can take Ssw = 1000 × 1000 mm2 , N = 50 and assume first pt = 0 (see Section 6 for the real pt). In Figure 1(b) we plot ttotal depending of Rc with different values of N and v. We see, that for the average propagation time 1 min, the Rc for N = 50 lies between 50 mm and 140 mm. Thus, for the targeted robots body of 23 mm, the communication radius Rc is of 4-5 times larger then the size of the robot.
At the end of this section we discuss such an important point as the critical swarm density Dcrit sw . The critical swarm density and the "coefficient of swarm efficiency" (the relation between the number of robots with useful/desired and useless/undesired activities) determine the minimal number of robots Nmin in some areal Sws required to perform some operation successfully. For the considered example with the given Ssw = 1000 × 1000 mm2 , ttotal = 30 sec., Rc = 100 mm and v = 20mm/sec. (related to the random motion), the minimal number Nmin ≈ 29 and the critical swarm density Dcrit sw = 28.46-6 . This relation is not exact, because it does not involve the size of a robot into this calculation, however in the microrobotic case with Srobot ≪ Ssw, it can serve as a good approximation.
3 Requirements and restrictions imposed on communication in real swarms
The requirements concern choosing the transmission equipment, the number of directional communication channels, communication radius and the hardware reduction of communication deadlocks. The communication equipment of a microrobot should consume as less energy as possible and be of small size (the robot's size is 23x23x28 mm). Finally, the communication equipment should include, as far as possible, other functions, like proximity or distance measurement. The communication radius Rc = 50 - 140 mm can be implemented in the radio-frequency (RF) and infrared (IR) way.
The RF provides two-way communication channel, the communication radius Rc is of several meters and modern one-chip RF modules, even 802.11b/802.11g modules, consume energy in mW area. However we have a serious objection against RF in microrobotic swarms. Firstly, a simultaneous transmission of many (80-150) microrobots leads to massive RF-interferences. Secondly, the RF-system (with the large Rc) transmits local information exchange between robots globally in a swarm. This local information does not have too much sense for all robots, so that we have high communication overhead in this case.
The IR communication is recently dominant in the socalled small-distance-domain, as e.g. for communication between laptops, hand-held devices, remote control and others. In IR domain we can choose between several different technologies, like IrDA 1 , 34-38 Khz PCM-based devices and so on. Additional advantage of the IR-solution consists in combining communication equipment with sensors; we can think about proximity or distance sensors on the base of IR reflection. The IR-solution is not new in robotic domain (see e.g. [Kube, 1996], [Suzuki et al., 1995]), however there are almost no solutions that combine perception, proximity sensing and communication.
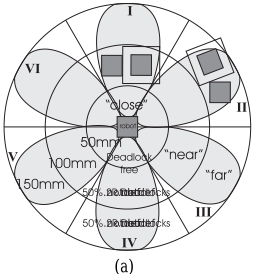
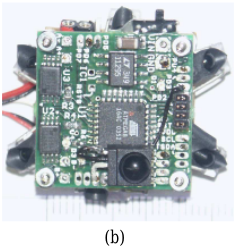
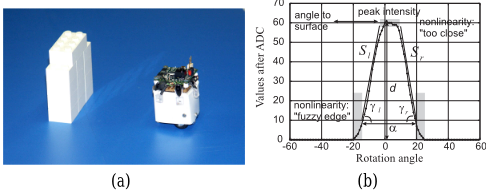
The IR-equipment has also the problem of interferences. They appear, like in RF case, when several neighbor robots transmit simultaneously. The problem of IR-interferences can be avoided by restricting an opening angle of a pair IRreceiver-transmitter. For four communication channels, the opening angle of each channel is 90o . In this case we have 2and 3-robots IR-interferences even in the "closest" radius (50 mm). Reducing the opening angle to 60o or to 40o allows avoiding IR-interferences in the "close" and "near" radius (100 mm) (Figure 2(a)). Since many microcontrollers have 8-channel ADC (one ADC input is used by the distance sensor), we choose 6-channel directional communication (Figure 2(b)).
Directional communication is extremely important in a swarm also from another reason. The point is that a robot has to know not only a message itself, but also the context of this message (e.g. the direction from which the message is received, intensity of signal, communicating neighbor and so on). Without directional communication hardware, we cannot implement algorithms providing a spatial context. From many software requirements the communication radius Rc and the number of directional communication channels are the most important ones. From this viewpoint, the IR is more suitable for robot-robot communication than the RF. The host-robot communication can also be implemented with IR (a sensor with PCM-filter for receiving global modulated signal). Such a signal can be thought as of a remote control or a global information exchange between robots and host.
1 IrDA requires additional chips, and if we think about 4-6 channels communication, this solution is not really suitable for the implementation in microrobots.
Speaking about IR communication we have to mention the problem of ambient light. It represents generally a very critical issue, because it can essentially distort or even completely break IR-communication/sensing. We performed experiments with luminescent lamps, filament lamps and daylight. Even for IR-receivers with daylight filter, swarm has to be protected against a light of filament lamps. As far as possible, the direct daylight should be also avoided. Use of modulated light can essentially improve communication against ambient light, however this solution is not always acceptable/feasible.
The filament lamps can be used as a global pheromone to control a swarm [Bonabeau et al., 1999]. When it is emitted simultaneously with luminescent light, the robot reacts more intensively on filament light. This effect can be utilized in many purposes, like finding the food source, navigation or even a quick message about some global event. This communication way does not require any additional sensors, however should be used only as an exception, because it essentially distorts a regular communication.
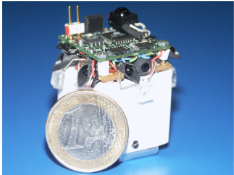
In the following we briefly describe the developed hardware solution for the directional IR-communication and sensing. More details for hardware can be found in [Kornienko et al., 2005]. In the hardware we do not use such popular sensors as IS471F or Sharp's GP2Dxxx with binary output, because they do not assume active control needed for communication. We encountered that small integrated transistordiode pairs like SFH9201, TCNT1000, TCRT 1000/1010, GP2D120, QRB1134 are not suitable as distance, proximity and communicating sensors for Rc of 130-150 mm. There are also several problems with spectral matching of some receiver-emitter pairs, despite they use the same wavelength. In the tested phototransistors with 60o angle, we choose TEFT4300 (60o , collector light current 3,2 mA, 875...1000 nm), TSKS5400-FSZ as IR-emitter for proximity measurement and communication (60o , 950 nm, 2-7 mW/sr) and GaAs/GaAlAs IR-emitter TSAL6100 (20o , 950 nm, >80 mW/sr) for distance measurement. This pair is very small (emitter 5x5x2.65 mm and receiver 4,5xφ3 mm) so that they can easily be integrated in the sensors board. In experiments the current IF of IR-emitters was limited to 20 mA, that corresponds to I/O port of the microcontroller. For controlling we use the Megabitty board (23×23×2 mm) with Atmel AVR Mega 8 microcontroller with 8 kB ROM and 1 kB RAM [Megabitty, 2005]. The sensors board and Megabitty board are assembled in one chassis with accumulators and 2 DC motors as shown in Figure 3. The tested communication speed is about 1000 bit/sec with low error rate, so that an application of error-correction approaches is not required.
4 Communication and Intelligence: logical protocols
After a description of the communication hardware of the microrobot, we return to our original question about Collective Intelligence. The question is "which degree of collective intelligence is still feasible in the group of microrobots ?" and "How to implement it ?" In Table 1 we collect some "swarm activities" that microrobots can collectively perform. These collective activities build a basis of swarm intelligence. We take the most simple example of spatial orientation. Let us assume, a robot has found a "food source" being relevant for the whole swarm. It sends the message "I, robot X, found Y, come to me". When this message is propagated through a swarm, each robot knows there is a resource Y at the robot X. However robots cannot find it because they do not know a coordinate of this "food source". The robot X cannot provide these coordinates because it does not know its own position. Therefore even for the simple collective feature of spatial orientation, a local context of messages determines a global capability of the whole group. Collective systems often have many different contexts, so that we have a context hierarchy.
| Context | N | SwarmCapability |
|---|---|---|
| Spatial | 1 2 3 | Spatial orientation Building spatial structures Collective movement |
| Information | 4 5 6 7 | Building informational structures Collective decision making Collective information processing Collective perception/recognition |
| Functional | 8 9 10 11 | Building functional structures Collective task decomposition Collective planning Group-based specialization |
The main point of this work is that the required context can be processed/provided by communication. However which level of communication can do it ? After hardware level, there are four such levels: level of physical signal transmission, level of communication protocols and level of informational structures, that require communication. In swarm-based systems we have the additional level concerned to the robot's behavior for creating and supporting required communication.
- On the level of physical transmission, the problem of communication is related to a choice of modulation/transmission approaches suitable for the IR-based signal transmission. On this level such properties of signals as strength, IR-interferences, directions can be extracted and incorporated into high-level protocols (it is closely related with the robot embodiment).
- Level of communication protocols concerns the propagation of information in a swarm. Generally, there are only two main ways of such a propagation:
- each robot routes communication packages from other robots without any changes (package-based communication);
- each robot processes the information from other low-level packages and sends only its own messages further.
In the package-based communication each package consists of a header with IDs of sender and receiver, routing information and the package content. The package ID can be coded by 10 bits, IDs of sender/receiver by 12 bits (6 bit each), so the header is of 22 bits, the package content is only of 8 bits. For recording the package history each robot needs about 900 bytes RAM only for routing 300-600 packages within a few minutes (N = 50 robots, each sends max. 1-2 messages each 10 sec, propagation time of 1 min.). In order to use the (spatial) context of message (e.g. the spatial location of the sender), the robots can follow the propagation way by using ID-history. However since all robots are continuously moving, the propagation way does not exist a long time. In the simulation, when a particular robot tries to achieve the source of a message by following the propagation way, it fails in 8090% ! After many experiments we came at the conclusion, that pure routing is not really suitable for propagating information thought a swarm (however package-based communication is used for local communication between neighbor robots). Thus, the second approach represents the main way of incorporating the information context into communication.
- 3,4. Levels of informational structures and specific collective behavior belong to the high level of information processing in a swarm. These levels deal with optimal representation of information, a minimization of communication flow, availability of information and supporting multiple peer-topeer connections for a large-distance information transmission. We demonstrate some ideas in Section 6, but generally, these levels overstep the framework of swarm-based communication.
5 Diffusion of messages context
As presented in the previous section, the context of message cannot be extracted from the message itself. This point has been discussed many time in collective AI community. In "AI world" there exist some approaches to retrieve the required context, however the microrobots are too limited to use them. Our proposal is that robots work with communication context during communication.
There are many different approaches to work with messages context. One of them is to incorporate the embodied information (signal intensity, direction, neighbors) into non-routed packages. The robots during "normal" communication process this context, so that it diffuses over a swarm. In this way a specific collective activity can be coordinated/created/controlled (see Section 6).
Another approach is a pheromone-based communication, well-known in natural [Bonabeau et al., 1999] as well as in technical/robotic systems [Payton et al., 2001]. Pheromonebased communication can be divided into two main groups: with pheromone leaved on immovable objects (ground, floor and so on) and pheromone leaved on moving objects like robots. Whereas the first type of pheromone assumes usually real (physical) pheromone, like chemical substances or electromagnetic marks, the second type of pheromone can also have some virtual nature. For instance, robots exchange the values of some variables, these variables are "located" on a robot and we can speak about "virtual pheromone".
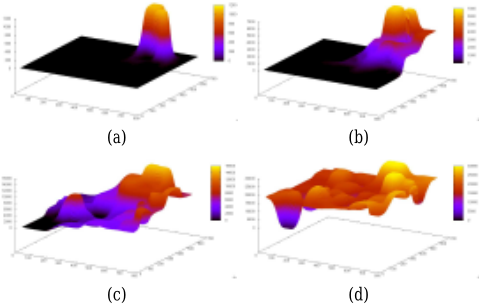
Basic idea of pheromone-based communication is quite simple. Let assume that the information source, robot X, sends a message, say "I found Y". This message is binary, however the robot X represents it by some integer value. This value is maximal at the origin. Any other robot, when getting this value, subtracts some constant and sends it further. In this way, the far away from the source the value is propagated, the less is its intensity. Based on this gradient every robot can conclude about the source Y and its origin (Figure 4). In this way not only a content of information ("something is found") is propagated, but also a spatial context (spatial origin of this "something"). More generally, different temporary, spatial or functional context can be provided by this "field".
Independently of the implemented mechanism, the "diffusion field" can be of four different types: non-gradient (used simply for transmitting some signals), gradient (to provide spatial context of a message), oriented (some specific direction), functional (e.g. repelling or attracting). The values of this field can be calculated as a function of connectivity (the number of neighbors, see [Nembrini et al., 2002]), time, specific input (e.g. only robots that see something transmit a pheromone), embodied information. Diffusion field can consist of many different subfields, i.e. with hierarchical structure.
- Diffusion of the size context. The diffusion field is a function of the connectivity degree: Φn+1 = f(∑i Φin ) where i goes over all local neighbors. The more large is the group of robots, the more higher is the value, so that a context is the size of the whole group.
- Diffusion of the spatial context. The source emits a constant value. All other robots subtract some constants Ci from this value (see Figure 4): Φsource n+1 = C1, Φn+1 = f(∑i Φin ) -C2 and transmit it further. Disadvantage of this relation is that robots can move in clusters, so that we can have local maximums of the diffusion field. Instead we can use Φn+1 = f(max(Φ1n , ..., Φin , )) - C2. In this case the clusterization effect is removed (however it cannot be completely removed from a swarm).
- Diffusion of the directional context. As already mentioned, robots support directional communication. The source emits a specific signal only in one direction. All other robots transmit this signal also only in one direction, as opposite to a receiving direction (received on "north", send to "south"). In this way, "communication streets" appear, that can be used for e.g. navigation.
- Diffusion of the temporal context. The diffusion field is a function of time: Φn+1 = f(max(Φ1n , ..., Φin , )) - f(t). This can be useful for coordinating some temporary event (activities) in a swarm.
- Diffusion of the activity context. This kind of field transmits a stimulus for a specific activity. Since all robots are heterogenous, a robot can need an assistance of only specific robots (with some specific functionality). Field can have a gradient and non-gradient character.
- Multiple diffusion. The context, especially spatial one, can be useful not only for information transfer, but also for many other spatial operations like navigation, localization
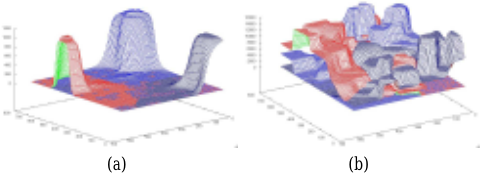
and so on. In the most simple form there are two or three field sources that are propagated in a swarm (Figure 5). Three fields are more preferable, because in this case robots can perform triangulation, like GPS.
6 Preliminary experiments and discussion
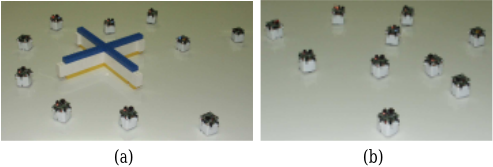
We performed two series of preliminary experiments with a small group of microrobots "Jasmine" and the goal of collective perception and spatial information processing (Figure 6). Some parameters and conditions of experiments and imple-
mented local protocols are collected in Table 2. The main
| Parameter | Value |
|---|---|
| Swarm areal | ∼ 3.5m2 , white plastic covering, only with a luminescent light |
| Signal transmission | PCM, 2 ms - logical "1" 1 ms - logical "0", 1 ms - pause |
| Logical protocols | with and without confirmation |
| Coding/decoding | Atmel's 16 MHZ Timer, divider 1024 |
| Low-level packages | 8 bit with one parity bit |
| Sending/receiving | sequential on all channels sending - 38 ms on one channel listening - 3 ms on one channel |
problem we encountered is a poor probability of bidirectional communication contact in the prototype's multi-channel communication system. The reasons for that are:
- appearance of communication-dead-zones (primarily corners of the chassis) and the problem of emitter-receiver optical isolation that additionally increases these zones (they are different at emitters and receivers). We estimate that in average ∼ 10%- 15% of the 360◦ communication areal is lost; - nonlinear radiation patterns (Figure 2(a)). For bidirectional communication contact, both radiation patterns have to match. Comparing to one-directional communication, the probability of bidirectional contact on any arbitrary channel is 0.5-0.25 (according to the communication distance);
- the microrobot can send and receive only sequentially by all channels. In order to send a message, sending and receiving channels have to be "synchronized" (the number of a "sending" channel has to correspond to the number of a "listening" channel). The probability that both channels "meet" is 1/6*1/6=1/36.
As shown in Table 2, sending on one channel continues ∼ 38ms for 8 bit package and is repeated each 10 - 100ms (depend on the currently executed activities). With the probability of 1/36, the communication contact will be established within pt =∼ 1s-1, 5s and a transmission of message (without confirmation) with 10 robots takes Npt =∼ 10 - 15s. The transmission of messages with the confirmation protocol takes 20 - 60s. These data are confirmed by experiments [Pradier, 2005], [Fu, 2005], as shown in Figure 8(b) and Table 3. To improve matching of nonlinear radiation patterns, the robots can slowly rotate during "looking/listening phase". In Table 3 we demonstrate the results of these experiments for 6 robots (from [Fu, 2005]). Generally, we are
| Receiver | Sender | Propagation Time |
|---|---|---|
| - 6◦ per cycle 6◦ per cycle | 6◦ per cycle - 6◦ per cycle | not always stable stable, 7.36 s. stable, 5.98 s. |
developing the second version of the sensors board, where at least a part of problems will be solved in hardware way.
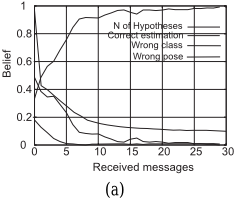
The first series of experiments concerns collective perception. For that, all robots surround an object and scan the corresponding object's surfaces (Figure 7). The scan data provide information about surface's geometry and allow classifying the type of surface (flat, concave, convex; size of surface and so on). The classification data are exchanged be-
tween robots and matched with the distributed model of the object. However for a particular robot is important not only to recognize an object, but also to know its own position in relation to this object. This positional context cannot be obtained from the sensor data of individual robot (Figure 7(b)). The idea here is that during local communication, all robots know their neighbors, and this "embodied" information can be used for estimating a position. When sequences of connected particular observations are matched with models (e.g. the model A-B-C-A-C-D and the connected particular observation A-B), these connected observations can be located in the model. In this way the robots can collectively estimate their own spatial context (see more in [Pradier, 2005]). As Optimal.notdefCommunication Distance
5
10
15
20
25
Distance.notdefbtw..notdefrobots,.notdefcm
(b)
Figure 8: (a) Estimation of spatial context during collective perception; (b) Dependence between global information propagation time and the distances between robots (6 robots).
demonstrated by experiments, even for uncomplete observations, this approach allows deriving the positions, as shown in Figure 8(a).
The second series of experiments concerns the spatial information processing, like distance/area measurement over a swarm, collective calculation of the swarm's center of gravity and so on. To perform these operations, the robots have to create the SPPN so that a part of them is continuously contained within the communication radius of each other. In this way they build a collective information system, that we call a "communication street".
To maintain the desired distances in SPPN, the moving robots can periodically scan the neighborhood. However this consumes energy/time and essentially distorts the currently executed activities. The idea is to use the local communication context provided by the IR-signal strength, which nonlinearly decreases with the distance. During PCM encoding, the robots measure the amplitude of received from different directions PCM-signals and control the motion so that to maintain SPPN. In this way they not only support an optimal distance for global information propagation (Figure 8(b)), but also can collectively perform different spatial computation (distances, areas, centers of gravity and so on). The details of the experiments can be found in [Fu, 2005].
The performed experiments are too preliminary to be generalized, however the processing of context information during communication works, videos can be downloaded from the project home page (contact authors). During experiments we encountered several undesired effects, one of them consists in clusterization. This phenomenon appears when robots fall to groups so that any communication between groups is broken down. When the detached group is small, these robots usually lose "orientation" and are "lost" for swarm.
Propagation Time,.notdefs
14
12
10
8
6
4
2
Generally, we have shown that despite the limited hardware capabilities of microrobots, the specific construction of hardware and software parts make feasible many collective properties. We also demonstrated that some features of collective AI can essentially be "improved" when using context-based communication. Context-awareness is closely related with physical processes (e.g. IR-signals transmission) and hardware/software components, i.e. with robotic embodiment. However the concept, or at least a systematic approach, that connects the embodiment, context-aware communication and collective intelligence still remains open and represents future works.
We are grateful to our students Mauricio Fern´andez Pradier and Zheng Fu for performing several experiments.
@inproceedings{ijcai2005p85,
  title     = {Collective AI: context awareness via communication},
  author    = {Kornienko, Sergey and Kornienko, Olga and Levi, Paul},
  booktitle = {Proceedings of the Nineteenth International Joint Conference on
               Artificial Intelligence, {IJCAI-05}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Leslie Pack Kaelbling and Alessandro Saffiotti},
  pages     = {1464--1469},
  year      = {2005},
  url       = {https://ijcai.org/proceedings/2005/85},
}
TY - CPAPER TI - Collective AI: context awareness via communication AU - Kornienko, Sergey AU - Kornienko, Olga AU - Levi, Paul T2 - Proceedings of the Nineteenth International Joint Conference on Artificial Intelligence, IJCAI-05 PB - International Joint Conferences on Artificial Intelligence PY - 2005 SP - 1464 EP - 1469 UR - https://ijcai.org/proceedings/2005/85 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





