
Robotics in the Home, Office, and Playing Field
Proceedings of the Sixteenth International Joint Conference on Artificial Intelligence. Invited Speakers. Pages 1385-1391.
© 1999 International Joint Conferences on Artificial Intelligence
Abstract
Robots are gradually entering into diverse application domains such as home, office, and playing field. This article presents advanced research activities related to these domains. First is RoboCup which is an attempt to promote AI and robotics research by providing a common task for evaluation of various performance, theories, algorithms, and robot architectures. In order for robots (both physical robots and soft agents) to play a soccer game reasonably well, a wide range of technologies need to be integrated and a number of technical breakthrough must be accomplished. The recent results from the last two RoboCups are reviewed and future leagues are introduced. Second, the richer domain of service robotics has also received significant interest recently. The task here is to serve as a human assistant in an office or domestic environment, for tasks like cleaning and delivery. The human-robot interaction is a key issue to success, which poses new challenges in terms of integration of spoken dialogue, gestures, body language, etc. In addition mobile manipulation and safe navigation around humans is essential to success. These two areas integrates many different disciplines including control, perception, natural language processing, hybrid systems and handling of uncertainty, and applied to tour guiding, mail delivery, domestic services, and rescue activities.
- [Andersson et al., 1999] M. Andersson, A. Oreback, M. Lindstrom, and H.I. Christensen. Intelligent Sen- sor Based Robots, chapter ISR: An Intelligent Ser- vice Robot. Lecture Notes in Artificial Intelligence. Springer Verlag, Heidelberg, July 1999.
- [Arkin, 1998] Ronald C. Arkin. Behaviour Based Robotics. Intelligent Robots and Autonomous Agents.
- MIT Press, Boston, MA, 1998. ISBN 0-262-01165-4.
- [Asada and Kitano, 1999] Minoru Asada and Hiroaki Kitano, editors. RoboCup-98: Robot Soccer World Cup II. Springer, Lecture Note in Artificail Intelli- gence (to appear), 1999.
- [Beetz et al., 1998] M. Beetz, W. Burgard, D. Fox, and A.B. Cremers. Integrating active localisation into high level robot control systems. Robotics and Autonomous Systems, 23(4):205-220, July 1998.
- [Brooks, 1986] R. A. Brooks. A robust layered control system for a mobile robot. IEEE Journal of Robotics and Automation, RA-2(1):14-23, March 1986.
- [Burgard et al., 1997] W. Burgard, A.B. Cre- mers, D. Fox, D. Haendel, G. Lakemeyer, D. Schultz, W. Steiner, and S. Thrun. The rhino museum tour project. http: I /www. cs. uni -bonn. de/ rhino, 1997. Link
- [DeHart et al., 1999] F. DeHart, D. Fox, W. Burgard, and S. Thrun. Monte carlo localisation for mobile robots. In Proc. IEEE Conf. on Robotics and Au- tomation (ICRA99}, Detroit, May 1999.
- [Engelberger, 1989] Joseph F. Engelberger. Robotics in Service. MIT Press, 1989.
- [Kitano and Asada, 1998] Hiroaki Kitano and Minoru Asada. Robocup humanoid challenge: That's one small step for a robot, one giant leap for mankind. In Proc. of IROS'98, pages 419-424, 1998.
- [Kitano and Asada, 1999] Hirokai Kitano and Minoru Asada. Special issue on robocup. Artificial Intelli- gence, 77:(to appear), 1999.
- [Kitano et al., 1997] H. Kitano, M. Asada, Y. Ku- niyoshi, I. Noda, E. Osawa, and H. Matsubara. "robocup: A challenge problem of ai". AI Magazine, 18:73-85, 1997.
- [Kitano, 1998] Hiroaki Kitano, editor. RoboCup-97: Robot Soccer World Cup I. Springer, Lecture Note in Artificail Intelligence 1395, 1998.
- [Kristensen, 1997] Steen Kristensen. Sensor planning with bayesian decision theory. Robotics and Au- tonomous Systems, 19(3-4):273-286, March 1997.
- [Nourbaksh, 1998] lllah Nourbaksh. Sage. http://www.cs.cmu.edu/ illah/SAGE, 1998. Link
- [Rencken et al., 1999] W. D. Rencken, W. Feiten, and R. Zollner. Intelligent Sensor Based Robots, chap- ter Relocalisation by Partial Map Matching. Lecture Notes in Artificial Intelligence. Springer Verlag, Hei- delberg, July 1999.
- [Simmons et al., 1999] Reid Simmons, Richard Good- win, Karen Zita Haigh, Sven Konig, Joseph O'Sullivan, and Manuela M. Veloso. Xavier: Expe- rience with a layered robot architecture. ACM Maga- zine "Intelligence", 1999.
- [Thrun et al., 1999] S. Thrun, M. Bennewitz, W. Bur- gard, A.B. Cremers, F. Dellaert, D. Fox, C. Rosen- berg, N. Roy, J. Schulte, and D. Schultz. Minerva: A second generation mobile tour guide robot. In IEEE Intl. Conf. on Robotics and Automation (ICRA99}, Detroit, May 1999.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
Robotics offers a fertile ground for demonstration of ar tificial intelligence techniques. The domain provides a basis for real-world evaluation of techniques under real istic assumptions. Construction of robotic systems re quires at the same time integration of a diverse range of expertise in order to provide operational systems. Tradi tionally robot systems have been used in manufacturing, in particular in the car industry. The majority of robots sold today are still deployed for spot-welding and car
Henrik I. Christensen
Centre for Autonomous Systems Royal Institute of Technology S-100 44 Stockholm, Sweden
painting. Mobile robots have so far not gained the ex pected wide-spread use. This is primarily due to two problems: i) adequate perception to enable deployment of systems is natural environments, and ii) lack of adap tive techniques for planning and error recovery in the context of rich environments.
Recently a number of new application areas have re ceived significant interest. Already in 1989 the far ther of robotics, Joseph Engelberger, predicted that ser vice robotics will be a major new business area for robotics [Engelberger, 1989). Service robotics involves assistance to elderly, commercial and domestic clean ing, tour guides, and delivery services (medicine, mail, printer output, etc). In parallel the area of entertain ment has begun to attract significant attention. Excel lent examples of entertainment robots include the Mind Storm system sold by LEGO (an interactive toy for chil dren) and the SonyDogs, developed by SONY (see next section). These applications clearly demonstrate that mobile robots gradually are becoming a part of our ev eryday life.
In terms of entertainment a well-structured effort of Robot Soccer has been initiated (term RoboCup). We will here introduce the overall aim of RoboCup, review results from recent competitions and point to its utility to artificial intelligence research. In parallel we will re view recent new results in the area of service robotics and illustrate how this field brings together a range of different methodologies to allow deployment of mobile robots in our regular life.
2 RoboCup - Integrating AI and Robotics
RoboCup (The Robot World Cup Initiative) is an at tempt to promote intelligent robotics research by pro viding a common task for evaluation of various theo ries, algorithms, and agent architectures [Kitano et al., 1997). RoboCup has currently chosen soccer as its stan dard task. In order for a robot (a physical robot or a software agent) to play a soccer game reasonably well, many technologies need to be integrated and a num ber of technical breakthroughs must be accomplished. The range of technologies spans the gamut of intelligent robotics research, including design principles for au tonomous agents, multi-agent collaboration; strategy ac quisition, real-time reasoning and planning, robot learn ing, and sensor-fusion.
The First Robot World Cup Soccer Games and Con ferences (RoboCup-97) was held during the International Joint Conference on Artificial Intelligence (IJCAI-97) at Nagoya, Japan with 37 teams around the world, and the Second Robot World Cup Soccer Games and Con ferences (RoboCup-98) was held on July 2-9, 1998 at La Cite des Sciences et de I'Industrie (La Cite) in Paris with 61 teams. RoboCup-99 Stockholm will be held in conjunction with IJCAI-99 participated in by over 120 teams. A series of technical workshops and com petitions have been planned for the future. While the competition part of RoboCup is highlighted in the me dia, other important RoboCup activities include techni cal workshops, the RoboCup Challenge program (which defines a series of benchmark problems), education, and infrastructure development. As of April 1999, RoboCup activity involves thousands of researchers from over 36 countries. Further information is available from the web site: http: I /www. robocup. org/
2.1 What's RoboCup?
RoboCup has a series of activities such as competitions, conferences, RoboCup challenges, education, infrastruc ture, and secondary domain. Among them, however, competition remains the most well-known component. We think competition has unique value in testing robots and software teams in environments outside of the lab oratory. It also forces participants to build robot plat forms which reliably perform the task, instead of show ing superb performance once in a hundred times. And of course, competition is fun. It motivates students and appeals to spectators.
Currently, RoboCup consists of three competition tracks:
- Simulation league: Each team consists of eleven programs, each controlling separately each of eleven team members. The simulation is run using the Soc cer Server developed by Noda et al. Each player has distributed sensing capabilities (vision and audi tory) and motion energy both of which are resource bounded. Communication is available between play ers and strict rules of the soccer game are enforced (e.g. off-sides). This league is mainly for researchers who may not have the resources for building real robots, but are highly interested in complex multi agent reasoning and learning issues.
- Small-size real robot league: The field is of the size and color of a ping-pong table (See Figure 1 (a)), and up to five robots per team play a match with an orange golf ball. The robot size is limited to approximately 15cm 3 . Typically robots are built by the participating teams and move at speeds of up to 2m/s. Global vision is allowed, offering the challenge of real-time vision-based tracking of five
Figure 1: Competition sites
fast moving robots in each team and the ball.
- Middle-size real robot league: The field size is of the size and color of three by three ping-pong tables (See Figure 1(b)), and up to five robots per team play a match with a Futsal-4 ball. The size of the base of the robot is limited to approximately 50cm diameter. Global vision is not allowed. Goals are colored and the field is surrounded by walls to allow for possible distributed localization through robot sensing.
Aside from the winner of each league, RoboCup awards the Scientific Challenge Award and Engineer ing Challenge Award for the team which made a ma jor challenge with some success. These awards were es tablished to foster challenging scientific and engineering research in RoboCup. In general, the safest approach to winning the competition is to use conventional and reliable technologies well-tuned for the specific domain. The RoboCup domain is challenging enough so that any successful team must use some challenging technologies. However, these awards are given for truly high-risk and high impact design.
In RoboCup-97, the Scientific Challenge Award was given to Sean Luke of the University of Maryland for demonstrating the utility of evolutionary computation by co-evolving soccer teams. Two engineering challenge awards were given to Uttori-United (a joint team con sisting of Ustunomiya Univ., Toyo Univ., and RIKEN, Japan) and RMIT Raiders (Royal Melbourne Institute of Technology, Australia) , for designing novel omnidi rectional driving mechanisms.
In RoboCup-98, the Scientific Challenge Award was given to three research groups (Electrotechnical Labora tory (ETL), Japan, Sony Computer Science Laborato ries, Inc., Japan, and German Research Center for Arti ficial Intelligence GmbH (DFKI)) for their simultaneous development of fully automatic commentator systems for RoboCup simulator league.
Technical details of teams represented in RoboCup-97 as well as related research results was published as the official publication [Kitano, 1998], and those in RoboCup98 will appear [Asada and Kitano, 1999]. AI jour nal special issue on RoboCup features excellent works on RoboCup research issues about multiagent reinforce ment learning, teamwork formation, and so on [Kitano and Asada, 1999] For the details of the results of all matches in RoboCup-97 and RoboCup-98, please visit the site: http: I /www. robocup. org/
2.2 Research Issues and Approaches
In this section, we discuss several research issues involved in the development of real robots and software agents for RoboCup. One of the major reasons why RoboCup attracts so many researchers is that it requires the inte gration of a broad range of technologies into a team of complete agents, as opposed to a task-specific functional module.
Currently, each league has its own architectural con straints, and therefore research issues are slightly differ ent from each other. We have published proposal papers about research issues in RoboCup initiative. For the synthetic agent in the simulation league, the following issues are considered:
- Teamwork among agents, from low-level skills like passing the ball to a teammate, to higher level skills involving execution of team strategies.
- Agent modeling, from primitive skills like recogniz ing agents' intents to pass the ball, to complex plan recognition of high-level team strategies.
- Multi-agent learning, for on-line and off-line learn ing of simple soccer skills for passing and intercept ing, as well as more complex strategy learning.
For the robotic agents in the real robot leagues, for both the small and middle-size ones, the following issues are considered:
- Efficient real-time global or distributed perception possibly from different sensing sources.
- Individual mechanical skills of the physical robots, in particular target rum and ball control.
- Strategic navigation and action to allow for robotic teamwork, by passing, receiving and intercepting the ball, and shooting at the goal.
More strategic issues are dealt in the simulation league and in the small-size real robot league while acquiring more primitive behaviors of each player is the main con cern of the middle-size real robot league.
Architectural Analysis
There are two kinds of aspects in designing a robot team for RoboCup:
- Physical structure of robots: actuators for mobil ity, kicking devices, perceptual (cameras, sonar, bumper sensor, laser range finder) and computa tional (CPUs, microprocessors) facilities.
- Architectural structure of control software.
In the simulation league, both of the above issues are fixed, and therefore more strategical structure as a team has been considered. On the other hand, in the real robot leagues, individual teams have devised, built, and arranged their robots. Although the small league and the middle one have their own architectural constraints, there are variations of resource assignment and control structure of their robots. Table 1 shows the variations in architectural structure in terms of number of CPUs and cameras, and their arrangement.
Three types A, B, and C indicate a variation adopted in the real robot small-size league. Type A is a typical structure many teams used in this league: the central ized control of multiple bodies through a global vision. Type B is a kind of multiagent system in which decision making is distributed and independent from each other although they share the global vision. CMUnited-98 in the small-size league took this sort of architecture. Type C features sensor coordination of global and local views based on the centralized control with multiple bodies. !-space (a joint team of Utsunomiya Univ. and Univ. of Tokyo, Japan) in the small-size league adopted this type architecture.
On the other hand, type E is a typical architecture adopted in both the simulation league and the real robot middle-size league: a completely distributed multiagent system. Type D used C. S. Freiburg team in the middle size league adopted a combination of types A and E uti lizing laser range finders mounted on players which make it possible to reconstruct the global view and to local ize observed objects (teammates, opponents, and ball) in the field. That is, they changed the problem in the middle-size league into one in the small-size league.
Communication between agents is possible in all of the leagues. The simulation league is the only that uses it except one team Uttori in the middle-size league. In the following, we attempt to analyze the achievements in RoboCup-97 and 98 in terms of each league.
2.3 Simulation League
The simulation league continues to be the most popular part of the RoboCup leagues, with 34 teams participat ing in RoboCup-98, which is a slight increase over the number of participants at RoboCup-97. In RoboCup-98, because of the offside rule introduced from 1998, most of matches are carried out in 'compact soccer' style like human soccer which provides two research issues closely related to each other: dynamic formation and opponent monitoring. This means the change from position based role assignment to context sensitive dynamic role assign ment.
Teams in the RoboCup simulation league are faced with three strategic research challenges: multi-agent learning, teamwork and agent modeling. All three are fundamental issues in multi-agent interactions. The learning challenge has been categorized into on-line and off-line learning both by individuals and by teams (i.e., collaborative learning). One example of off-line individ ual learning is learning to intercept the ball, while an example of on-line collaborative learning is to adaptively change player positions and formations based on expe rience in a game. The detailed analysis is given in the paper in [Kitano and Asada, 1999].
| I Type | I CPU I | Vision I | issues | I league |
|---|---|---|---|---|
| A , | 1 | 1 global | strategy | small-size |
| B | n | 1 global | sharing of information | small-size |
| c | 1 | 1 global + n local | sensor fusion; coordination | small-size |
| D | 1+n | n local | multiple robots | middle-size |
| E | n | n local | sensor fusion; teamwork | middle-size & simulation |
The stage in RoboCup-98 is still in the preliminary level. For example, tactics to escape from off-side traps was still passive even in champion teams. In future RoboCup, such tactics will require recognition of inten tion of opponent players/teams. In this stage, opponent modeling and management of team strategies would be come more important. Similarly, on-line learning will become more important, because team strategies should be changed during a match according to strategies of opponent teams.
2.4 Small-Size Real Robot League
The environment in the small-size league is highly dy namic with robots and the ball moving at speeds between 1m/s and 2mfs. An interesting research issue consists of the prediction of the motion of the mobile objects to combine it with strategy. In the case of the CMUnited98 team, prediction of the movement of the ball was suc cessfully achieved and highly used for motion (e.g., ball interception) and strategic decisions (e.g., goaltender be havior and pass/shoot decisions).
One of the main interesting open questions is the de velopment of algorithms for on-line learning of the strat egy of the opponent team and for the real-time adap tation of one's strategy in response. Finally, similarly to the simulation and middle-size leagues, we want to abstract from our experience algorithms that will be ap plicable beyond the robotic soccer domain.
2.5 Middle-Size Real Robot League
The performance of robot behaviors in RoboCup-98 was better than in RoboCup-97 although the number of teams in the middle-size league drastically increased from 5 to 16, more than three times. However, the level of skills is under development, mainly putting more fo cus on individual behavior acquisition than cooperative teamwork. Engineering issues such as precise robot con trol and robust object detection are still main issues in this league.
The focus on colors to visibly distinguish objects ex erts a strong bias for research in color-based vision meth ods. It is desirable to permit other approaches as well, such as using edges, texture, shape, optical flow etc., thereby widening the range of applicable vision research within RoboCup.
Finally, the use of communication in the different leagues is also an active research topic. Communica tion allows interesting research in a variety of topics, in cluding multi-robot sensor fusion and control. We want to explore limited communication environments and its relationship to agent autonomy, and learning of cooper ative behavior.
2.6 New Leagues
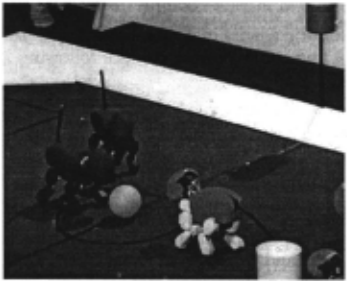
In RoboCup-98, Sony Legged Robot exhibition games and demonstration were held, and they attracted many spectators, especially boys and girls, for its cute style and behaviors. Figure 2 shows a scene from their demonstra tions. In 1999, Sony Legged Robot league will be one of the RoboCup official competitions with more nine teams around the world.
Currently, except for Sony Legged Robot League, games are played by wheel-based robots, soccer game by humanoid robot is the next major leap in the field which leads to the ultimate goal of the RoboCup [Kitano and Asada, 1998].
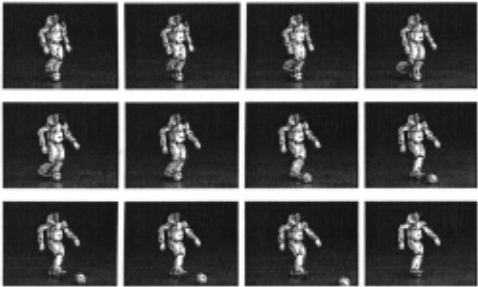
Before, actually play soccer with human players, RoboCup organize humanoid leagues in following cat egories, and start Humanoid league competition from RoboCup-02 (2002). Fig.3 shows the performances by Honda P3 in 1998, and they will show 3 by 3 humanoid games in RoboCup-2002, the year of World Cup in Japan and Korea.
2. 7 RoboCup New Activities
The comprehensive nature of RoboCup makes it an ideal subject for project-oriented AI and robotics courses. Al ready, a few undergraduate and graduate courses are now being planned using RoboCup. Further, an education infrastructure named RoboCup Jr. is proposed, re flecting the needs of educational institutions. RoboCup Jr. wHI use cheaper robots and a much simpler task domain, rather than the highly challenging arrangement seen in the current RoboCup competition. A prototype of platforms will make a debut in 2000 or 2001, and the official league RoboCup Jr. will start from 2002.
Disaster rescue is one of the most serious social is sue which involves very large numbers of heterogeneous agents in the hostile environment. RoboCup-Rescue intends to promote research and development in this so cially significant domain by creating a standard simula tor and forum for researchers and practitioners. While the rescue domain intuitively appealing as large scale multi-agent domains, it has not yet given through anal ysis on its domain characteristics. RoboCup-Rescue tar gets search and rescue activities for large-scale disaster like Kobe earthquake in 1995.
3 Service Robotics
Service robotics covers a range of robot applications in cluding office automation, lawn moving, assistance to handicapped and elderly, and domestic services. The vi sion of a domestic servant is at least three decades old, yet little progress has been achieved until recently. By 1989 Engelberger [Engelberger, 1989] predicted that ser vice robotics would be a major commercial market for robotics by the end of the century, yet the large scale commercial potential is yet to be demonstrated.
The most dominating problems in development of ser vice robots are reliable mapping and interaction with the environment. For operation in a regular home it is im possible to. make strong assumptions about the layout, the materials encountered, the behaviour of other agents like dogs, children, etc. To provide a viable solution it is necessary to provide systems that are fully autonomous and which have extensive facilities for error detection and recovery.
Research in perception, intelligent control, probabilis tic mapping and human-robot interaction has generated results that recently have allowed demonstration of a range of service robots applications with a significant potential. In the following we will briefly outline several of these systems.
3.1 Hospital Automation
Over the last five year the company HelpMate Robotics have deployed more than 120 HelpMate systems in hos pitals. The robot system provides delivery services to the staff. Typical services includes pick-up and deliv ery of meals and transport of medical records and spec imens between the different departments and the labo ratory. The system uses a touch screen in combination with spoken feedback for communication with users. The navigation is based on ultra-sonic sonars for obstacle de tection, ceiling mounted landmarks for absolute localisa tion, and a laser radar for docking. The system operates in pre-specified environments and have no facilities for error-recovery. In the event of an error a radio modem is used for signalling for assistance. The HelpMate sys tem is one of the most widely deployed service robot today. The autonomy of the system has first and fore most been achieved through careful engineering of the system and its environment. This implies that the cost of deployment is significant and due to its limited ability to perform error recovery there is need for trained staff to operate the vehicle.
3.2 Commercial cleaning
Another area that has received significant attention over the last 5 years is commercial cleaning of hotel corri dors, conference facilities and more recently supermar kets. During early 1990 the company Kent Inc. auto mated a series of their floor cleaners. The system uses a combination of ultra-sonic ranging and inertial sensing for navigation. The system, named RoboKent, drives through a specific area and builds up a map of the en vironment. Once a map is available a zamboni pattern is used for traversal of the area. The system requires fairly well structured environment for its operation. I.e., it is unable to clean small niches and narrow passages. The robot uses a simple depth-first strategy for traversal of multiple corridors. A total of 50-100 units have been sold. The units are all deployed in the US, as the unit is too large for operation in European style corridors.
Recently Siemens and Hefter demonstrated a new ve hicle for cleaning of supermarkets during opening hours [Rencken et al., 1999]. This vehicle uses also ultra-sonic and laser ranging for mapping of the environment and avoidance of dynamic obstacles like customers. This par ticular system can be seen as the next generation of cleaning robots with a more advanced user interface and the ability to operate in highly cluttered environments.
A characteristic feature of these systems is a very sim ple user interface as it is ,to be operated by unskilled labor. The user interface is typically a simple 80 char acter display and four buttons. The system have a the same time very limited facilities for handling of errors. If an error situation arises then the operator is simply notified.
3.3 Domestic cleaning
Domestic cleaning is a very tough task as few or no as sumptions can be made about the environment. Thus, few have tried to automate this market. Recently the company Electrolux demonstrated a behaviour based robot for automatic vacuuming of rooms. The system is a new ultra-sonic ranging system and a tactile array for mapping of the environment and detection of colli sions. The robot drives along the perimeter of the room and afterwards it moves through the room at random. The robot uses a truly behaviour based method for nav igation and room coverage [Brooks, 1986]. The robot is expected to be available in Europe and Asia in a few years. This will be the first fully autonomous system for domestic use that will be mass-produced for regular customers. The robot is expected to cost less than $500.
3.4 Tour guides
All of the above examples have been commercial sys tems. There are however also a number of very inter esting research platforms. One of the applications that has received the most attention is probably tour guides. The system that has been in operation the longest for autonomous navigation in an office environment is prob ably XAVIER that was developed at CMU by Simmons et. al. [Simmons et al., 1999]. This system uses a hybrid-deliberative architecture combined with Partially Observable Markov Processes (POMPS) for automatic localisation, handling of obstacles and planning of mis sions. The robot has been in daily operation for more than four years and has a remarkable robustness of more than 98%.
At the University of Bonn the RHINO system was de veloped for tour guiding at the Deutsches Museum Bonn [Burgard et al., 1997; Beetz et al., 1998]. The uses a probabilistic (Markov) approach to localisation. Com bined with methods for obstacle avoidance the system was capable of guiding visitors between different displays at the museum over a period of six days. The user spec ified desired tours using a touch screen. The robustness of probabilistic localisation is most impressive. Revised and updated version of the system have later been de ployed by CMU in the Minerva system, that operated for 2 weeks at the Smithsonian Institute during August - September 1998 [Thrun et al., 1999]. The Minerva system included both vision and sonar for localisation. Recently the use of CONDENSATION for robot locali sation has been reported [DeHart et al., 1999]. Through use of Monto-Carlo based sampling of multi-modal dis tributions it is possible to achieve real-time localisation in cluttered environments.
The SAGE system deployed at the Carnegie Museum of Natural History was also developed at CMU [Nour baksh, 1998]. This system is a permanent part of the Dinosaur hall where it provides tours and multi-media information about the items on display. The system, which has been in operation for since 1998, uses color vision and artificial markers for navigation while sonars, infra-red ranging and bumpers are used for handling of obstacles.
3.5 Office/Domestic services
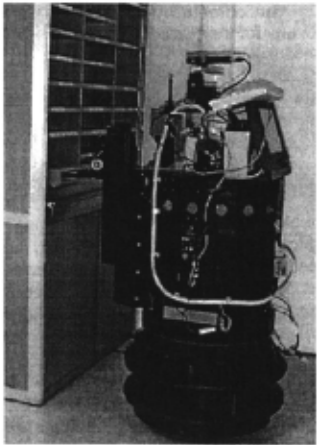
Service robots are gradually moving into the domestic market. The applications will here involve more com plex tasks like cleaning of a table, locating objects, and assisting humans. One example of such a system is the intelligent service robot developed at the Royal Institute of Technology [Andersson et al., 1999]. For operation in a natural environment it is necessary to use navigation techniques like the probabilistic mapping mentioned ear lier, as robustness is an absolute requirement. To achieve robustness the robot uses vision, laser and ultra-sonic ranging. The system uses a hybrid deliberative architec ture [Arkin, 1998] with dedicated behaviours for explo ration, door traversal, user-interaction, object recogni tion, point-to-point based navigation. The system uses a topology graph for planning of missions which in turn are expected by combinations of behaviours. The sys tem is presently capable of delivering mail to a range of different researchers in the laboratory and operation in a natural IKEA style living room. The robot is shown in Figure 4. In addition to robust navigation the system must have excellent facilities for interaction with users. Speech technology is gradually reaching a level of matu rity that enables a natural dialogue. Large vocabulary speech recognizers like IBM Via-Voice and Dragon Dic tate require user training to achieve reasonable perfor mance, but research prototypes that uses limited vocab ularies do provide an adequate robustness without user training. One major obstacle is natural language pro cessing. It is unrealistic to require that end-users will be trained to instruct the robot. There is thus a need for natural language interpretation of spoken input to enable a flexible dialogue between the user and a robot. In addition there is a need for probabilistic (re-)planning of tasks to enable handling of a diverse set of situations and errors [Kristensen, 1997].
3.6 Research Issues
Fully autonomous service robots for domestic applica tions is not yet possible. To provide such systems a num ber of fundamental issues must be resolved, including:
- Robust methods for localisation in cluttered dy namic environments. Today methods exist for ro bust localisation in static environments, but in a dynamic setting there is a need for automatic classi fication of structure into static and dynamic, which requires stronger temporal integration.
- Error recovery. For operation in dynamic setting it is essential to have facilities for automatic error detection and recovery. On research platforms a ro bustness of 99% might be enough, but that still cor responds to 15 minutes down-time per day, which is clearly unacceptable. Methods for robust comput ing using methods like voting might be a possible solution to this problem.
- Intuitive user interfaces. Almost all systems have a rudimentary interface that is acceptable to re searchers but for regular users an intuitive interface is needed which requires new methods for dialogue interaction, natural· language processing and meth ods for combination of speech and gesture.
- Software methods for configuration and deploy ment. Today a significant amount of resources is needed to deploy a system in a particular setting. To make these systems useful to a wider audience and to enable easy transfer of methods from one ap plication to another there is a need for new meth ods that allow modular design and integration of different techniques. This in turn call for standard architectures and benchmarks.
- Object recognition. To enable intelligent interac tion with objects in the environment there is a need for methods for robust recognition of diverse set of objects and object categories. This involved new methods for invariant recognition, memory organi sation and task oriented sensing.
4 Summary
Using the domains of RoboCup and Service Robotics we have tried out outline recent trends in robotics and their dependency on new research results in Artificial Intelligence. Robotics requires integration of techniques into operational systems to demonstrate operation in and outside of the laboratory. For such applications ro bustness is a key issues. It is not enough that techniques operate 80-90% of the time. Robustness must at least be of the order 98-99% to make the systems useful for enter tainment or commercial tasks. To be useful in realistic tasks there is at the same time a need for high-level rea soning and planning about goals, contexts, actions and interaction to make these systems useful to end-users. The next generations of these systems will thus rely on a wide range of artificial intelligence techniques.
Acknowledgement
The first author thanks to the members of International RoboCup Committee, especially, Dr. Hiroaki Kitano (Sony CSL, Japan).
The second author gratefully acknowledges the sup port of the Swedish Foundation for Strategic Research and the support of the staff at CAS.
@inproceedings{ijcai1999p196,
  title     = {Robotics in the Home, Office, and Playing Field},
  author    = {Asada, Minoru and Christensen, Henrik I.},
  booktitle = {Proceedings of the Sixteenth International Joint Conference on
               Artificial Intelligence, {IJCAI-99}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Thomas Dean},
  pages     = {1385--1391},
  year      = {1999},
  note      = {Invited Speakers},
  url       = {https://ijcai.org/proceedings/1999/196},
}
TY - CPAPER TI - Robotics in the Home, Office, and Playing Field AU - Asada, Minoru AU - Christensen, Henrik I. T2 - Proceedings of the Sixteenth International Joint Conference on Artificial Intelligence, IJCAI-99 PB - International Joint Conferences on Artificial Intelligence PY - 1999 SP - 1385 EP - 1391 UR - https://ijcai.org/proceedings/1999/196 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





