
Fast Planning Through Planning Graph Analysis
Proceedings of the Fourteenth International Joint Conference on Artificial Intelligence. Planning. Pages 1636-1641.
© 1995 International Joint Conferences on Artificial Intelligence
Abstract
We introduce a new approach to planning in STRIPS-like domains based on constructing and analyzing a compact structure we call a Planning Graph. We describe a new planner, Graphplan, that uses this paradigm. Graphplan always returns a shortest-possible partial-order plan, or states that no valid plan exists. We provide empirical evidence in favor of this approach, showing that Graphplan outperforms the total-order planner, Prodigy, and the partial-order planner, UCPOP, on a variety of interesting natural and artificial planning problems. We also give empirical evidence that the plans produced by Graphplan are quite sensible. Since searches made by this approach are fundamentally different from the searches of other common planning methods, they provide a new perspective on the planning problem.
- [Barrett and Weld, 1994] A. Barrett and D. Weld. Partial_- order planning: evaluating possible efficiency gains. Arti- ficial Intelligence, 67:71-112, 1994.
- Carbonell, personal communication] J. Carbonell. 1994. [Etzioni, 1990]
- Etzioni. A Structural theory of explanation-based learning. PhD thesis, CMU, December 1990. CMU-CS-90-185.
- [Knoblock, 1994] C. Knoblock. Generating parallel execu- tion plans with a partial-order planner. In AIPS94, pages 98-103, Chicago, 1994.
- [McAllester and Rosenblitt, 1991] D. McAllester and D. Rosenblitt. Systematic nonlinear planning. In Pro- ceedings of the 9th National Conference on Artificial Intel- ligence, pages 634-639, July 1991.
- [Russell, 1992] S. Russell. Efficient memory-bounded search algorithms. In ECAI-92, Vienna, 1992.
- [Stone et al., 1994] P. Stone, M. Veloso, and J. Blythe. The need for different domain-independent heuristics. In AIPS94, pages 164-169, Chicago, 1994.
- [Veloso and Blythe, 1994] M. Veloso and J. Blythe. Linkabil- ity: Examining causal link commitments in partial-order planning. In AIPS94, pages 164-169, Chicago, 1994.
- [Weld, 1994] D. Weld. An introduction to partial-order plan- ning. AI Magazine, 1994.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1 Introduction
In this paper we introduce a new planner, Graphplan, which plans in STRIPS-like domains. The algorithm is based on a paradigm we call Planning-Graph Analysis (PGA). In this approach, a compact structure we call a Planning Graph is explicitly created that is then ex plored in a search. A Planning Graph is not a graph of "world-states" (which of course could be huge). Rather, Planning Graphs are closer in spirit to the PSGs of [Et zioni, 1990]. Planning Graphs are structures based on domain information, the goals and initial conditions of a problem, and an explicit notion of time. Planning
*This research is sponsored in part by the Wright Labora tory, Aeronautical Systems Center, Air Force Materiel Com mand, USAF, and the Advanced Research Projects Agency (ARPA) under grant number F33615-93-1-1330. The first author is also supported in part by NSF National Young In vestigator grant CCR-9357793 and a Sloan Foundation Re search Fellowship. The second author is supported in part by NSF grant CCR-9119319. Views and conclusions contained in this document are those of the authors and should not be interpreted as necessarily representing official policies or endorsements, either expressed or implied, of Wright Labo ratory or the United States Government.
Merrick L. Furst
School of Computer Science Carnegie Mellon University Pittsburgh PA 15213-3891
mxf~cs.cmu.edu
Graphs offer a convenient, efficient means of organiz ing and maintaining search information. They do so in a way that is reminiscent of the efficient solutions to Single-Source Shortest-Paths and Dynamic Program ming problems. Planning Graph Analysis appears to have significant practical value in solving planning prob lems even though the inherent complexity of STRIPS like planning, which is at least PSPACE-hard, is much greater than the complexity of Shortest-Paths or stan dard Dynamic Programming problems.
Graphplan combines aspects of both total-order and partial-order planners. On the one hand, Graphplan makes more commitments than traditional total-order planners. On the other hand, the plans it generates are partially-ordered plans.
The way in which Graphplan "over-commits" is that when it considers an action, it considers it at a specific point in time. For instance, it might consider placing the action 'move Rocket 1 from London to Paris' in a plan at exactly time-step 2. It may seem puz zling that an extra level of commitment would lead to a fast planner, especially given the success enjoyed by least-commitment planners [McAllester and Rosen blitt, 1991][Barrett and Weld, 1994][Weld, 1994]. How ever, the extra level of commitment allows Graphplan to store and manipulate valuable search information. This enables it to rapidly determine when backtracking is needed.
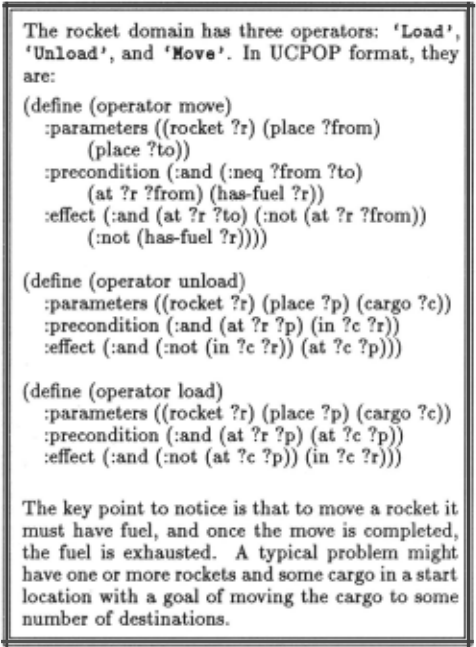
Even though Graphplan makes strong commitments, the plans it generates are partially-ordered plans. For instance, in the rocket problem (Figure 1), the plan that Graphplan finds is of the form: "In time-step 1, appropri ately load all the objects into the rockets, in time-step 2 move the rockets, and in time-step 3, unload the rock ets." The semantics of such a plan is that the actions in a given time step may be performed in any desired order. Conceptually this is a kind of "parallel" plan [Knoblock, 1994], since one could imagine executing the actions in three time steps if one had as many workers as needed to load and unload and fly the rockets.
One valuable feature of our algorithm is that it guaran tees it will find the shortest plan among those in which independent actions may take place at the same time. Empirically and subjectively these sorts of plans seem particularly sensible. For example, in Stuart Russell's "flat-tire world" [Russell, 1992], the plan produced by Graphplan opens the boot (trunk) in step 1, fetches all the tools and the spare tire in step 2, inflates the spare and loosens the nuts in step 3, and so forth until it finally closes the boot in step 12. (See Figure 4.)
Another significant feature of our algorithm is that it is not particularly sensitive to the order of the goals in a planning task, unlike traditional approaches. More discussion of this issue is given in Section 3.2.
In Section 4 of this paper we present empirical results that demonstrate the effectiveness of Graphplan on a va riety of interesting "natural" and artificial domains.
1.1 Definitions and Notation
Planning Graph Analysis applies to STRIPS-like plan ning domains. In these domains, operators do not cre ate or destroy objects and time may be represented dis cretely because the operators all act as atomic actions. Specifically, by a planning problem, we mean:
- A STRIPS domain (a set of operators),
- A set of objects,
- A set of propositions (literals) called the Initial Con ditions,
- A set of Problem Goals which are propositions that are required to be true at the end of a plan.
By an action, we mean a fully-instantiated opera tor. For instance, the operator 'put ?x into ?y' may instantiate to the specific action 'put Object 1 into Container2'. An action taken at time t adds to the world all the propositions which are among its Add Effects and deletes all the propositions which are among its Delete-Effects. It will be convenient to think of "do ing nothing" to a proposition in a time step as a special kind of action we call a no-op or frame action.
2 Valid Plans and Planning Graphs
We now define what we mean when we say a set of ac tions forms a valid plan. In the PGA framework, a valid plan for a planning problem consists of a set of actions and specified times in which each is to be carried out . In a valid plan several actions may be specified to occur at a single time step as long as none of them deletes a precondition or Add-Effect of another. 1 In a linear plan these independent parallel actions could be arranged in any order with exactly the same outcome. It is legal to perform an action at time 1 if its preconditions are all in the Initial Conditions. It is legal to perform an action at time t > 1 if the plan makes all its preconditions true at timet. Because we have no-op actions that carry truth forward in time,we may define a proposition to be true at timet only if it is an Add-Effect of some action taken at time t - 1. Finally, a valid plan must make all the Problem Goals true at the final time step.
2.1 Planning Graphs
A Planning Graph is similar to a valid plan, but without the requirement that the actions at a given time step be independent.
More precisely, a Planning Graph is a directed, lev eled graph 2 with two kinds of nodes and three kinds of edges. The levels alternate between proposition lev els containing proposition nodes (each labeled with some proposition) and action levels containing action nodes (each labeled with some action) . The first level of a Planning Graph is a proposition level and consists of one node for each proposition in the Initial Conditions. The levels in a Planning Graph, from earliest to latest are: propositions true at time 1, possible actions at time 1, propositions possibly true at time 2, possible actions at time 2, propositions possibly true at time 3, etc.
Edges in a Planning Graph explicitly represent re lations between actions and propositions. The action nodes in action-level i are connected by "precondition edges" to their preconditions in proposition level i, by "add-edges" to their Add-Effects in proposition-level i + 1, and by "delete-edges" to their Delete-Effects in proposition-level i + 1. 3
1 Knoblock [1994] describes an interesting less restrictive notion in which several actions may occur at the same time even if one deletes an add-effect of another, so long as those add-effects are not important for reaching the goals.
2 A graph is called leveled if its nodes can be partitioned into disjoint sets L1, L2, ... , Ln such that the edges only connect nodes in adjacent levels.
3 A length-two path from an action a at one level, through a proposition Q at the next level, to an action b at the following level, is similar to a causal link a S b in a partial-order planner.
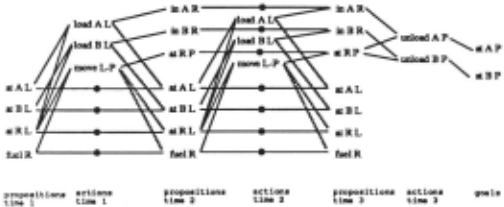
The conditions imposed on a Planning Graph are much weaker than those imposed on valid plans. Ac tions may exist at action-level i if all their preconditions exist at proposition-level i but there is no requirement of "independence." In particular, action-level i may legally contain all the possible actions whose preconditions all exist in proposition-level i. A proposition may exist at proposition-level i + 1 if it is an Add-Effect of some ac tion in action-level i (even if it is also a Delete-Effect of some other action in action-level i). Because we al low "no-op actions," every proposition that appears in proposition-level i may also appear in proposition-level i + 1. An example of a Planning Graph is given in Figure 2.
Since the requirements on Planning Graphs are so weak, it is easy to create them. In Section 3.1 we de scribe how Graphplan constructs Planning Graphs from domains and problems. In particular, any Planning Graph with t action-levels that Graphplan creates will have the following property:
If a valid plan exists using t or fewer time steps, then that plan exists as a sub graph of the Plan ning Graph.
It is worth noting here that Planning Graphs are not overly large. See Theorem 1.
2.2 Exclusion Relations Among Planning Graph Nodes
An integral part of Planning-Graph Analysis is notic ing and propagating certain mutual exclusion relations among nodes. Two actions at a given action level in a Planning Graph are mutually exclusive if no valid plan could possibly contain both. Similarly, two propositions at a given proposition level are mutually exclusive if no valid plan could possibly make both true. Identi fying mutual exclusion relationships can be of enormous help in reducing the search for a subgraph of a Planning Graph that might correspond to a valid plan.
Graphplan notices and records mutual exclusion re lationships by propagating them through the Planning Graph using a few simple rules. These rules do not guar antee to find all mutual exclusion relationships, but usually find a large number of them. 4 Specifically, there are two ways in which actions a and bat a given action-level are marked by Graphplan to be exclusive of each other:
[Interference] If either of the actions deletes a precon dition or Add-Effect of the other. (This is just the standard notion of "non independence" and depends only on the operator definitions.)
[Competing Needs] If there is a precondition of action a and a precondition of action b that are marked as mutually exclusive of each other in the previous proposition level.
Two propositions p and q in a proposition-level are marked as exclusive if all ways of creating proposition p are exclusive of all ways of creating proposition q. Specif ically, they are marked as exclusive if each action a hav ing an add-edge to proposition p is marked as exclusive of each action b having an add-edge to proposition q.
For instance, in the rocket domain with 'Rockett at London' in the Initial Conditions, the actions 'move Rockett from London to Paris' and 'load Alex into Rockett in London' at time 1 are exclu sive because the first deletes the proposition 'Rockett at London' which is a precondition of the second. The proposition 'Rockett at London' and the proposition 'Rockett at Paris' are exclusive at time 2 because all ways of generating the first (there is only one: a no-op) are exclusive of all ways of generating the second (there is only one: by moving). The actions 'load Alex into Rockett in London' and 'load Jason into Rockett in Paris' (assuming we defined the initial conditions to have Jason in Paris) at time 2 are exclusive because they have competing needs, namely the propositions 'Rockett at London' and 'Rockett at Paris'.
Note that the Competing Needs notion and the exclu sivity between propositions are not just logical properties of the operators. They depend on the interplay between operators and the Initial Conditions. For instance, the exclusivity of 'Rockett at London' and 'Rockett at Paris' cannot be logically concluded from the structure of the 'move' operator alone. It is derived both from the structure of the operator and the fact that the rocket starts in only one place at the initial time.
A pair of propositions may be exclusive of each other at every level in a planning graph or they may start out being exclusive of each other in early levels and then become non-exclusive at later levels. For instance, if we begin with Alex and Rocket1 at London (and they are nowhere else at time 1), then 'Alex in Rockett' and 'Rockett at Paris' are exclusive at time 2, but not at time 3.
3 Description of the algorithm
The high-level description of our basic algorithm is the following. Starting with a Planning Graph that only has a single proposition level containing nodes corresponding to Initial Conditions, Graphplan runs in stages. In stage i Graphplan takes the length i- 1 Planning Graph from stage i -1, extends it one time step (the next action level and the following proposition level), and then searches the extended Planning Graph for a valid plan of length i . Graphplan's search either finds a valid plan (in which case it halts) or else determines that the goals are not all achievable by time i (in which case it goes on to the next stage).
4 In fact, determining all mutual exclusion relationships can be as hard as finding a legal plan. For instance, consider creating two new artificial goals 91 and 92 such that satisfying 91 requires satisfying half of the original goals and satisfying 92 requires satisfying the other half.
This basic algorithm could be termed "weakly com plete": in each iteration through the Extend/Search loop described above, the algorithm either discovers a plan or else proves that no plan having that many time steps or fewer is possible. In Section 5 we describe how this al gorithm may be augmented to be complete in the usual sense, so that if the Problem Goals are not satisfiable by any valid plan then the planner does eventually halt with failure. We wish to point out, however, that weak completeness can be useful. For instance, a user may know that if the problem is solvable at all, then it will be solvable in, say, 15 time steps. In that case, by re peating the Extend/Search loop until it has failed on a graph with 15 action levels, Graphplan is able to report failure in what may be significantly less time than would be needed to prove full unsolvability.
3.1 Extending Planning Graphs
All the initial conditions are placed in the first proposi tion level of the graph. To create a generic action level, we do the following. For each operator and each way of instantiating preconditions of that operator to proposi tions in the previous level, insert an action node if no two of the preconditions are labeled as mutually exclusive. 5 Also insert all the no-op actions and insert the precondi tion edges. Then check the action nodes for exclusivity as described in Section 2.2 above and create an "actions that-l-am-exclusive-of' list for each action.
To create a generic proposition level, simply look at all the Add-Effects of the actions in the previous level and place them in the next level as propositions. At this point insert the add-edges and delete-edges. (Note: do not create a proposition if its only reason for existence is to be deleted by some action.) Mark two propositions as exclusive if all ways of generating the first are exclusive of all ways of generating the second.
As we demonstrate in the following theorem, the time taken by our algorithm to create this graph structure is polynomial in the length of the problem's description and the number of time steps for problems with STRIPS style operators.
Theorem 1 Consider a planning problem with n ob jects, p propositions in the Initial Conditions, and m STRIPS operators each having a constant number of for mal parameters. Let£ be the length of the longest add-list of any of the operators. Then, the size of a t-level plan ning graph created by Graphplan, and the time needed to create the graph, are polynomial n, m, p, £, and t.
5 Checking for exclusions keeps Graphplan, for instance, from inserting the action 'unload Alex from Rocket! in Paris' in time 2 of the rocket-domain graph when the ini tial conditions specify that both Alex and the rocket begin in London.
Proof. Let k be the largest number of formal parame ters in any operator. Since operators cannot create new objects, the number of different propositions that can be created by instantiating an operator is O(£nk). So, the maximum number of nodes in anr proposition-level of the planning graph is O(p + min ) . Since any opera tor can be instantiated in at most O(nk) distinct ways, the maximum number of nodes in any action-level of the planning graph is O(mnk). Thus the total size of the planning graph is polynomial in n, m, p, .e, and t, since k is constant.
The time needed to create a new action and proposi tion level of the graph can be broken down into (A) the time to instantiate the operators in all possible ways to preconditions in the previous proposition-level, (B) the time to determine mutual exclusion relations between actions, and (C) the time to determine the mutual ex clusion relations in the next level of propositions. It is clear that this time is polynomial in the number of nodes in the current level of the graph. ·
Empirically, the part of graph creation that takes the most time is determining exclusion relations. However, empirically, graph creation only takes up a significant portion of Graphplan 's running time in the simpler prob lems, where the total running time is not very large any way.
An obvious improvement to the basic algorithm de scribed above (which is implemented in Graphplan) is to avoid searching until a proposition-level has been cre ated in which (A) all the Problem Goals appear, and (B) no pair of Problem Goals has been determined to be mutually exclusive.
3.2 Searching for a plan
Given a Planning Graph, Graphplan searches for a valid plan using a backward-chaining strategy. Unlike most other planners, however, it uses a level-by-level ap proach, in order to best make use of the mutual exclusion constraints. In particular, given a set of goals at time t, it attempts to find a set of actions mapping these goals to some other set of goals at time t- 1 having the property that if only these goals could be achieved in t - 1 steps, then the original goals could be achieved in t steps. If the goals at timet- 1 turn out to not be mutually solvable, Graphplan tries to find a different set of actions, yielding a different set of sub goals at timet -1 and so forth, until it either succeeds or has proven that the original set of goals is not solvable at timet.
In order to implement this strategy, Graphplan uses the following method (easily implemented recursively) to generate the subgoal sets at time t - 1 from a given set of goals at time t. For each goal at time t, for each ac tion generating that goal (starting with the no-op) select that action if it is not exclusive of some action already selected. Continue in this fashion with the next goal at timet and so forth. If there are no actions available for achieving the current goal that are not exclusive of pre vious selections, then back up to the previous goal. Once finished with all the goals at timet, the preconditions to the selected actions make up the new goal set at time t - 1. Graphplan then continues this procedure at time step t- 1. 6
An improvement to this approach (which is imple mented in Graphplan and helps modestly on the tasks we have tried) is that after each action is considered a check is made to make sure that no goal ahead in the list has been "cut-off." In other words, Graphplan checks to see if for some goal still ahead in the list, all the actions creating it are exclusive of actions we have currently se lected. If there is some such goal, then Graphplan knows it needs to back up right away.
One final aspect of Graphplan's search is that when a set of (sub )goals at some time i is determined to be not solvable, then before popping back in the recursion it memoizes what it has learned, storing the goal set and the time i in a hash table. Similarly, when it creates a set of subgoals at some time i, before searching it first probes the hash table to see if the set has already been proved unsolvable. If so, it then backs up right away without searching further.
The strategy of working on the sub goals in a somewhat breadth-first-like manner makes Graphplan fairly insensi tive to goal-orderings. In particular, the number of sets examined did not depend much on the order of the goals in any of the domains we tried. Within a Planning Graph level, the amount of time needed to construct a goal set at the previous time step from the current goal set might vary based on the ordering. Nonetheless, empirically, Graphplan's dependence on goal orderings seems to be much less than that of other planners such as Prodigy and UCPOP.
4 Experimental Results and Discussion
4.1 Natural domains
We compared Graphplan with two popular planners, Prodigy and UCPOP, on two "natural" planning prob lems. For both problems we ran Prodigy with heuristics suggested in Stone et al. [Stone et a/., 1994] and by Car bonell [Carbonell, personal communication]. Note that Graphplan is written in C while the other planners are in compiled LISP. On the other hand, we ran Graphplan on a (slow) DECstation 2100 and the other planners on a (faster) SPARC10.
In addition to running time, we also report for Graphplan the number of "goal-set creation steps" (the number of times it creates a goal set at time t- 1 from a goal set at timet) and the total number ofrecursive calls made (the number of times it selects an action). These are somewhat analogous to the backward-chaining steps taken by total-order planners.
Rocket
We ran the planners on the rocket domain described in Figure 1 with the following setup. The initial conditions have 3 locations (London, Paris, JFK), two rockets, and n items of cargo. All the objects (rockets and cargo) begin at London and the rockets have fuel. The goal is to get fn/21 of the objects to Paris and Ln/2J of the ob jects to JFK. The goals are ordered alternating between destinations.
6 Graphplan currently makes no attempt to order the goals at a time step in an advantageous way. We are currently experimenting with various standard heuristics.
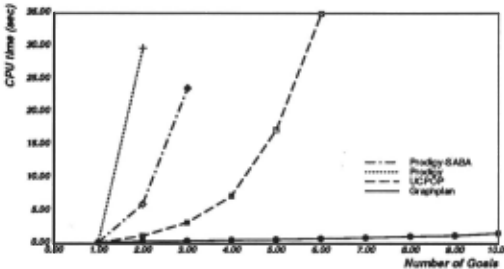
Results of the experiment are in Figure 3. Notice that Graphplan significantly outperforms the other two plan ners on this domain. Graphplan does well in this domain for two main reasons: (1) the Planning Graph only grows to 3 time steps, and (2) the mutual exclusion relations allow a small number of commitments (unloading some thing from Rocketl in Paris and something else from Rocket2 in JFK) to completely force the remainder of the decisions. In particular, Graphplan performs only two goal-set creation steps regardless of the number of goals, and the number of recursive calls is linear in the number of goals.
The running time of Graphplan is completely unaf fected by goal ordering for this problem.
Flat Tire
A "natural" problem of a different sort is Stuart Rus sell's "fixing a flat tire" domain [Russell, 1992]. Unlike the rocket domain, a valid plan for solving this problem requires at least 12 time steps (and 19 actions). While for the rocket domain, Graphplan would do pretty well even without the mutual exclusion propagation, here the mu tual exclusions are critical and ensure that not too many goal sets will be examined. Graphplan solves this prob lem in 1.1 to 1.3 seconds depending on the goal order ing. The number of goal-set creation steps ranges from a minimum of 107 to a maximum of 246, and the num ber of recursive calls from 609 to 1380. Neither UCPOP nor Prodigy found a solution within 10 minutes for this problem in the standard goal ordering, though it is possi ble to find goal orderings where they succeed much more quickly. Graphplan is not only fast on this domain, but it also produces a "sensible" plan. Figure 4 shows the plan produced by Graphplan for this problem.
4.2 Artificial domains
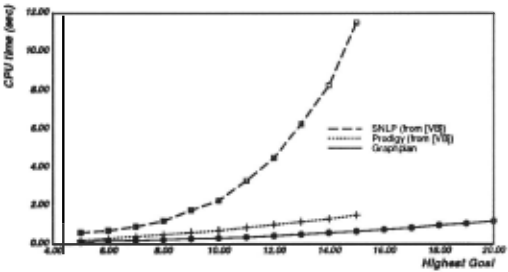
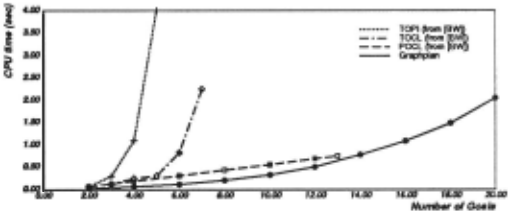
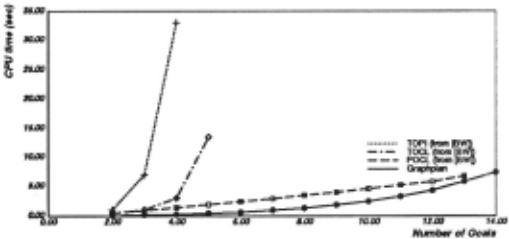
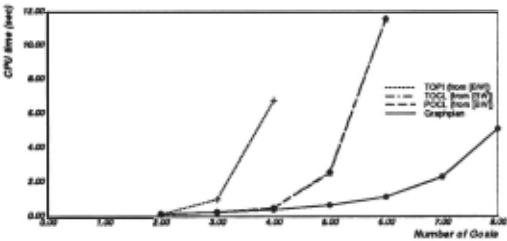
The papers by [Barrett and Weld, 1994] and [Veloso and Blythe, 1994] define a collection of artificial domains in tended to distinguish the performance characteristics of various planners. On all of these, Graphplan is quite com petitive with the best performance reported.
| Step 1: | open boot |
| Step 2: | fetch wrench boot fetch pump boot fetch jack boot fetch wheel2 boot |
| Step 3: | inflate wheel2 loosen nuts the-hub |
| Step 4: | put-away pump boot jack-up the-hub |
| Step 5: | undo nuts the-hub |
| Step 6: | remove-wheel wheell the-hub |
| Step 7: | put-on-wheel wheel2 the-hub put-away wheell boot |
| Step 8: | do-up nuts the-hub |
| Step 9: | jack-down the-hub |
| Step 10: | put-away jack boot tighten nuts the-hub |
| Step 11: | put-away wrench boot |
| Step 12: | close boot |
We present in Figures 5, 6, 7, and 8 performance data on four of the more interesting domains. All performance results in these figures for the other planners are taken from figures in their respective papers.
4.3 Discussion of Experimental Results
Four major factors seem to account for most of Graphplan 's efficiency. They are, in order of empirically derived importance:
Mutual Exclusion: The propagation and extensive use of mutual exclusion relations effectively prunes a large part of the search space.
Consideration of Parallel Plans: In some cases, such as the rocket problem, the valid parallel plans are relatively short compared with the length of the corresponding totally-ordered plans. In such cases neither the cost of Planning Graph construc tion, nor the cost of search is very large.
Memoizing: By fixing actions at specific places in time, Graphplan is able to record the goal sets that it proves to be unreachable in a certain number of time steps from the initial conditions.
Low-level costs: By constructing a Planning Graph in advance of search, Graphplan avoids the costs of per forming instantiations during the searching phase.
It is interesting to note that in three out of four of these points Graphplan's commitment to putting specific actions at specific points in time plays an important role.
5 Making Graphplan Complete
To a first approximation, Graph plan conducts something similar to an iteratively-deepened search. In the ith stage the algorithm sees if there is a valid parallel plan of length less than or equal to i. As described so far, if no valid plan exists there is nothing that prevents the algorithm from mindlessly running forever through an infinite number of stages.
We now describe a simple and efficient test that can be added after every unsuccessful stage that makes Graphplan a complete planner. That is, by augmenting Graphplan with the test we will describe, if the input problem has no solution then Graphplan will eventually halt and say "No Plan Exists."
5.1 Planning Graphs "Level Off"
Assume a problem has no valid plan. First observe th~t in the sequence of Planning Graphs created there Will eventually be a proposition level P such that all future proposition levels are exactly the same as P, i.e., they contain the same set of propositions and have the same exclusivity relations.
The reason for this is as follows. Because of the no op actions, if a proposition appears in some p~oposition level then it also appears in all future propositiOn levels. Since only a finite set of propositions can be created by STRIPS-style operators (when applied to a finite set of initial conditions) there must be some proposition level Q such that all future levels have exactly the same set of propositions as Q. Also, again because of the no-op's, if propositions p and q appear together in some level and are not marked as mutually exclusive, then they will not be marked as mutually exclusive in any future level. Thus there must be some proposition level P after Q such that all future proposition levels also have exactly the same set of mutual exclusion relations as P.
In fact it is not hard to see that once two adjacent levels Pn,' Pn+i are identical, then all future levels will be identical to Pn as well. At this point, we say the graph has leveled off
5.2 The Test that Makes Graphplan Complete
Let Pn be the first proposition level at which the graph has leveled off. If some Problem Goal does not appear in this level or if two Problem Goals are marked as mu-' . tually exclusive in this level, then Graphplan can immediately say that no plan exists. However, it may be the case that no plan exists but this simple test does not detect it, so we need to do something slightly more so phisticated.
As mentioned earlier, Graphplan memoizes, or records, goal sets that it has considered at some level and deter mined to be unsolvable. Let Sf be the collection of all such sets stored for level i after an unsuccessful stage t. In other words, after an unsuccessful stage t, Graphplan has determined two things: (1) any plan oft or fewer steps must make one of the goal sets in Sf true at time i, and (2) none of the goal sets in Sf are achie':able in i steps. The modification to Graphplan to make it com plete is now just the following:
If the graph has leveled off at some level n and a stage t has passed in which IS:,- 1 1 = IS:,I, then output "No Plan Exists."
Theorem 2 Graphplan outputs "No Plan Exists" if and only if the problem is unsolvable.
Proof The easy direction is that if the problem is unsolvable, then Graphplan will eventually say that no plan exists. The reason is just that the number of sets in st is never smaller than the number of sets in s;,-i, and nthere is a finite maximum (though exponential in the number of nodes at level n).
To see the other direction, suppose the graph has lev eled off at some level n and Graphplan has completed an unsuccessful stage t > n. Notice that any plan to achieve some set in S~+l must, one step earlier, achieve some s~t in S~. This is because of the way Graphplan works:. it determined each set in s~+l was unsolvable by mappmg it to sets at time step n and determining that they were unsolvable. Notice also that since the graph has leveled off st 1 = st- 1 . That is because the last t- n levels of ' n+ n dd' · l the graph are the same no matter how many a itlona levels the graph has.
Now suppose that after an unsuccessful stage ~' IS~- 1 1 = IS:.I (which implies that s~- 1 = .s~). This means that S~+1 = S:,. Thus, in order to achieve any set in st 1 one must previously have achieved some other n+ . f · d set in S~+1 . Since none of the sets m -?'n+1 are contame in the initial conditions, the problem iS unsolvable. ·
Acknowledgements
We thank Jaime Carbonell and the members of the CMU Prodigy group for their helpful advice.
@inproceedings{ijcai1995p211,
  title     = {Fast Planning Through Planning Graph Analysis},
  author    = {Blum, Avrim and Furst, Merrick L.},
  booktitle = {Proceedings of the Fourteenth International Joint Conference on
               Artificial Intelligence, {IJCAI-95}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Chris S. Mellish},
  pages     = {1636--1641},
  year      = {1995},
  note      = {Planning},
  url       = {https://ijcai.org/proceedings/1995/211},
}
TY - CPAPER TI - Fast Planning Through Planning Graph Analysis AU - Blum, Avrim AU - Furst, Merrick L. T2 - Proceedings of the Fourteenth International Joint Conference on Artificial Intelligence, IJCAI-95 PB - International Joint Conferences on Artificial Intelligence PY - 1995 SP - 1636 EP - 1641 UR - https://ijcai.org/proceedings/1995/211 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





