
Computer Control of Multijoined Finger System
Proceedings of the Sixth International Joint Conference on Artificial Intelligence. .
© 1979 International Joint Conferences on Artificial Intelligence
Abstract
This . paper treats computer control of multijoin ted fingers. First, we discuss optimum operational direction of multijointed fingers. The direction is determined from motional structure of the fingers and is important in th e control stage of arm part. Second, general descripti on about software system is presented with primitive programs to cont rol hardware system . These have b een implemented on the ETL o bje ct -handling system for manual industry. Third, experimental results of nut-turning task are presented which verify the feasibility of manual task by comp ut er control.
- H.Hana fusa and JI.Asada , "A Robot Hand with Jo:last-JC' Finge rs and its Applicati o n to 1\ snC' rnbJy .Proc ess ." TF'AC Symposium, •rokyo, 19'77. 1:' 1 '!' . Okada and ~~.'l' r: uddya , "On a Vt •n;at. il •• Jo'in p;er ~;ysL em." Proe . '(t.h 1:~1H , 197'(.
- •n 'l' . Okada, "ObJ Pct. -ll an<rl ir11 ~ :~y s t e m !'or• Ma11ual [ndust ry." TF:F.E Tran s . V0•1 • :;w:-9, No. ;' , I')'(().
- l1l T . Okada , "A Short-Range F'inding Sensor !'o r Manipulators." Bull. Electrotech. Lab. Vol.l,; •, No . 6, 1978. (a) II•'MODE=l (b )H'MODr:= ;• l•'i I~• ., NiJI.-I. ilf'fli 11 1~ l.ns k
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
1. INTRODUCTION
Multijointed fingers are useful not only for automation of manual industry but also for animal-like assistant robot from the standpoint of human welfares since t~ey are suited to realize flexible motions that give us not fear but familiality. Further, the fingers provide a research tool for investigation of new modes of servoing, intelligent manipulation, interactive real-time real-world system and AI. Under this philosophy, we treat fingers with complicated structure in our research,
Most of multijointed fingers are not competent f or manuul task G i nc1' they are nol on a 1 <>vc·J of programmable manipulation. Hanafusa [l 1 performed flexible manipulation by using elastic fingers which have coil springs. The ETL object-handling system [3] of which the hardware is overviewed in a reference [ 2 ] realizes the flexible manipulation with multijointed fingers.
In this paper, an optimum operational direction of a fi~ger part is discussed with generality . Then, Fundamental ideas for programming manual task are presented with primitive programs about the ETL finger system. Experimental result s of nut-turning task by computer control are also shown.
2 . OPERATIONAL DIRECTION OF A FINGER PART
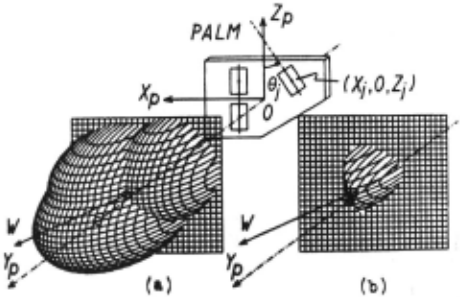
Multijointed fingers have an adaptability to grasp an object and handle it from various direction in geneJ:"al. But it is reasonabl e t.o fix an operational direction for a finger pnrt to have much flexibility in handling an object. We consider a volume in which the finger terminal can be located. We call the surface of it an envelope. Shape of the envelope depends on structure of the finger. In most cases, the shape is like an ellipsoid as shown in Fig.l . It is mathematically expressed in the coordinate system (Xp,YprZpl that has an origin at the center of the palm plate as
where j is a subscript related to finger number, (Xj ,O,Zjl denotes the coordinates of the finger root, Aj means effective finger length concerned with bend-in and bend-out joint, and Bj means that concerned with abduct and adduct joint. Mostly, the value of Aj is greater than that of Bj (A=R.1+R.2+R.3+R.4, B=R.2+R.3+R.4) ·
We have determined an optimum operational direction of a finger part as the direction toward which a common point of multiple envelopes is viewed from the center of the palm plate (In Fig.l, W shows this direction). Even if the finger part is composed of a lot of fingers, the optimum operational direction of the finger part would be fixed on the finger system according to its structure. On the other hand, an object has its own optimum operational direction as its property. Tt can be expressed by an axial line wh i C'h i :~ peculiar to the object. Therefore, adfiplnlli I i ty of the finger s would be created by cont. r·o·l ·1 i np; thr~ arm so that these operational directi ons might accord with each other.
3. SOFTWARE SYSTEM
3.1 General description
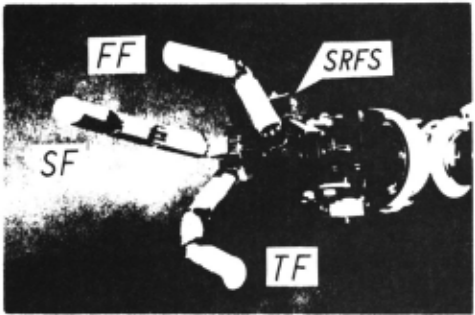
At present, the software system for manual task is on a low level since it is not described in the form like manipulator lahguage or hand language. We consider the symboric notations [3] that are defined to fundamental motions of a finger are useful to develop the language. Finger opPration for manual task would be prn"rarrml<'d by applying thl·SP moL ions t o a ~··ornL·t.r·i·· mod(~ · l of' an ob.Jcc t.. 'l'hc use of t;em:;on; i ::; important to make adaptable handling i.r1 r eal-world. As shown in Fig, ;> , our system has a short-range finding sensor (SRFS) [4] at the palm area for local inspection of the object. This sensor reduces complexity of programming since it augments the capabilities of the system so that it can find and acquire unindexed workpieces and cope with unexpected events in performing object handling and assembly operations. For example, in nut turning, it monitors the fixation between screw and nut, and provides the resulting displacement of a nut along a screw axis. Therefore, fingers' pushing or pulling operation is sensor-controlled according to the amount of its displacement.
3.2 Primitive Programs
Primitive programs control the hardware of the object-handling system, The next program is common to finger part and arm part.
TAFCON(IAF,IFMODE,XAF,YAF,ZAF)
The argument lAF designates thl' part to be cont r olled . The meaning of it. is
IFMODE is the argument concernPd with the cont r ol mode about the finger terminal di r ection , 'l'his is effective when the vulue of T AF is noL equa] to zero . When 'lYMODF: Lakes the value of l, only the position of a finger terminal is controlled. But when the value of 2 or 3 is assigned to IFMODE, not only the position but also the direction of the finger terminal is contr olled. Especial ly, when the value of 3 is assit;ned to IFMODE, the directi on is controlled to be optimum. (XAF ,YAF', 7.AF) are t he coordinates of the palm poi nt for arm !'ontr ol or the terminal point for f i np:Pr (·onLrol lr1 t.he coordinate syst.r·rn (X,Y,/'.) l.lint has an oriein at the shoulder ,joint. . When t.he value of IAF is equal to zero , the next program is used.
ARMSOL(XAF,YAF, ZAF,a,S,y, IFLAG )
This program calculates an arm solution by using the parameters (a,S,y) that are concerned with the optimum operational direction of the finger part. The argument TFLAG notifiPs whether the arm solution is obtained or not.
As far as the fingers are concerned , coordinates (XAF,YAF,ZAF) are the values expressed in the coordinate system CX,Y,Z). In order to obtain the coordinates (XF,YF,ZF) expressed in the coordinate system (xf;Yf, Zf ) that has an origin at the root of the finger, the next program for coordinates transformation is used 1
TRANSF(J,XAF,YAF, ZAF.XF,YF, ZF)
The argument J takes the value equal to that of IAF and designates t he finger to be controlled. Control values (Pl,P2 ,P3,P4) for finger joints are obtn.ined from programs FINSLl, F'I NSL? and 1<'1NSL'3 that are prepared according to the val ucs o f TF'MODE. '!'he command format to use these programs .is written as follows:
FlNf>Ltt(.J ,XF', YF, ZF , Pl ,P; 1 ,P3 ,Pl1, IFLAG)
when the value of' H'MODE is 2 or 3, the unit vee t o r Vjn (=u{·l X+uj 2 Y+ujJ Z) which denotes the dir· ·r.L"ion oft te rlnr:e r to b e controlled in r·efer-r cd. l·'inr~e r· [;o.lut.i on in FIN~;L;.' and F!NSL'3 arro o bt. :d ned by h tl] - <~ I imbing method and r·xhall s tinp; mr~ t.hod, r<':;pe c·tive ly.
!1. EXPEHI MF:N'I'I\ L MANlli\L 'l'ASK
Nut-turning task :is performed in the experiment. Tn ordror t.o adapt thP. fingers to the task, arm part 'i r; controlled so that the optimum operational d.irer~t:ion of the fingers accords with axial line of the screw . Then, each terminal point of the fingers is controlled to move along the contour which is assumed to be circ:ular in mathemati cal model of the nut. Results of t he task arP. shown in Fig. 3 . The vu.J U<:.'S of [FMODE in (a) and (b) are equal to 1 and :~ , r es pectively. Tn (b), both directions o f I. he f'i ngPr SF and 'l'F are equal to screw axis , nam<~ ly, U21=ll2 3 =u 31=u33=0 and u22=u32=J. 'rime requi r·c d to :wcompl i s h one cycle of t urning for (b) is about 2 . 3 times long as compared with t.hat. r o r (a) under sue~ condition that the r< ·~;o lut.i. on angle of the joint is 2 degrees. Tncidentally , the time for the case of IFMODE=3 is about 3.5 times l ong . The fact shows that t h e more precisely the finger direction is control l ed, the more time it takes . But the ti me r Pqui r c rl to obta·i n control values for the r·ase of TF'MODF:=2 ·in no t so long as we have s uppos erl. We cou ·l d hardly find Lhe di ff'erence ·in t.hP r·crmlt.s between the cases of IFMODE=;! and ] FMODr:= ·~. 'I'hi s means the < ~ apabi 1 ity of r<Jfi1 - t ime <'ont.rol o!' both the posit :ion and the <H'i··ntaLi on of' mult.i jointed f'i.nr:ers in ri·'MODI~:=;'. ·In (a), l'.i nger supports t he nut with a point. But in (u), it Lends to s upporL t.he nut wi I. h a li rl<'. 'l'hP f'i nge rs wou] rl r ea 1 i zc [;f.al>l· · " Jl<:ral.ion wh e.'fl t.he orient.ati<m o f' !.liP f'i nr;er:: arc cor1t r o·l I" " to fit to a nurfa<: e of' a n ub, j ec t..
~' . CONCLIJ~; I ON:;
Nut.-t.urnintc !.as k ha~: been carried Ul !l. smoothly by compul.<·r con tro·l wi Lhout inf'Jue nc e of' ::hape a nd ~~ i Y.r' o 1' thr· JIUL. 'l'his wouJd show the ['ea[; il>il j t.y o l' manua·l tasks by mult. ·i ,jointed I' i n~Cc r :~ w·i Lh f1 ex·i hi I i Ly .
l·:uC'h f'int~ c· r·l.ip in a::::umPd to bl' an idea·! point .. IIIII. ·in r·Pal , it. i :: ··xt.ended Likr' a ball. 'l'hr·r·· ·l'"r··, l.lio' ex l.< ·ll::.i on of' tlH·~ IIlli. :;ho11ld ·lw conside red in fine operation of an object . Further the fingers might be controlled not only in position but also in torque. We have Just started to deve l op int e lligent manipulation with cooperated control of these.
@inproceedings{ijcai1979p152,
  title     = {Computer Control of Multijoined Finger System},
  author    = {Okada, Tokuji},
  booktitle = {Proceedings of the Sixth International Joint Conference on
               Artificial Intelligence, {IJCAI-79}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Bruce G. Buchanan},
  year      = {1979},
  month     = {8},
  url       = {https://ijcai.org/proceedings/1979/152},
}
TY - CPAPER TI - Computer Control of Multijoined Finger System AU - Okada, Tokuji T2 - Proceedings of the Sixth International Joint Conference on Artificial Intelligence, IJCAI-79 PB - International Joint Conferences on Artificial Intelligence PY - 1979 UR - https://ijcai.org/proceedings/1979/152 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:





