
POPS: An Application of Heuristic Search Methods to the Processing of a Nondeterministic Programming Language
Proceedings of the Third International Joint Conference on Artificial Intelligence. General Problem Solving. Pages 589-599.
© 1973 International Joint Conferences on Artificial Intelligence
Abstract
POPS is a processor for a simple nondeterministic programming language, · PSL. POPS accepts a problem stated in PSL and attempts to solve it by finding a successful execution of the PSL program. POPS operates by identifying elements of the input program with elements of the heuristic search paradigm, analyzing the input program to obtain information about the problem operators, and applying methods borrowed from GPS to solve the problem. In addition to the goal-directed methods based on GPS, POPS contains the methods developed by Fikes in his program REF-ARF. Key words : Problem solving, Heuristic search, Non deterministic programming language.
- Bolce, J.F., "LISP/360, A Description of the Uni- versity of Waterloo LISP 1 • 5 Interpreter for the IBM System/360," Computing Centre University of Waterloo, Waterloo, Ontario, Canada, 1967.
- Ernst, George W. and Newell, Allen, GPS: A Case Study in Generality and Problem Solving, Academ- ic Press, N.Y., 1969.
- Feigenbaum, E. and J. Feldman (eds.), Computers and Thought, McGraw-Hill, 1963.
- Fikes, Richard Earl, A Heuristic Program for Solving Problems Stated as Nondeterministic Procedures, Doctoral thesis, Carnegie-Mellon University, 1968.
- Fikes, Richard Earl, REF-ARF: A System for Solving Problems Stated as Procedures, J. Art. Intel. 1 (1) 1970.
- Floyd, Robert, "Nondeterministic Algorithms," J. ACM 14 (4) 1967.
- Gibbons, G. D., Beyond REF-ARF: Toward an In- telligent Processor for a Nondeterministic Pro- gramming Language, Doctoral Thesis, Carnegie- Mellon University, 1972.
- Newell, A. and Simon, H. A. ,"GPS, A Program that Simulates Human Thought," in Feigenbaum and Feldman, 1963.
- Raphael, B. , "The Frame Problem in Problem -Solving Systems," in Artificial Intelligence and Heuristic Programming, Edinburgh University Press, 1971.
References were extracted automatically from the PDF and may contain errors.
Full text extracted automatically from the PDF; figures, tables and equations may differ. The PDF is the version of record.
POPS: AN APPLICATION OF HEURISTIC SEARCH METHODS TO THE PROCESSING OF A NONDETERMINISTIC PROGRAMMING LANGUAGE
by
Gregory Dean Gibbons
Naval Postgraduate School Monterey, California
execution times.
Interpretation of Nondeterministic Programs
Nondeterministic programs are convenient for stat ing problems because they leave unspecified the order in which some alternatives are to be considered. Conse quently, the process that interprets a nondeterministic program must determine for itself which alternative to consider at a given time.
A processor for a language containing a CHOICE function must select values for the function. If the language contains a nondeterministic branch instruc tion, or if the particular program's flow of control de pends on the value of a CHOICE function, the proces sor must select possible control paths as well. A problem represented by a nondeterministic program is, therefore, a search problem in the space of possible combinations of values of the CHOICE function and pos sible control paths through the program.
Nondeterministic programs fall into two categories: those in which the flow of control is deterministic, and those in which it is not. In the former case, the pro cessor may be required to select values for the program variables so that certain constraints are satisfied. If this selection is made symbolically, the processor can execute the program until and END statement is en countered, at which time the symbolic selections must be replaced by actual values . Such problems are refer red to as constraint satisfaction problems. Fikes's pro gram REF-ARF solves a class of constraint satisfaction problems of considerable difficulty.
To execute a program having nondeterministic con flow, a processor must select the control path it will follow, as well as the values for the program variables . The problems represented by programs in the second cate gory are heuristic search (HS) problems.
REF-ARF
Richard Fikes (Fikes, 1968, 1970) implemented a problem solving system, REF-ARF , based on Floyd's suggestion, but containing much improved solution methods. Fikes represents nondeterministic values sym bolically by creating internal variables. Constraints are represented as formulas involving these variables. This representation allows the use of algebraic simplification methods to reduce the size of the space to be searched. Fikes 's most powerful solution method consists of al ternating value instantiation and algebraic simplifica tion, effectively reducing large spaces to anything from a few to a few hundred nodes. This method enables REF-ARF to solve some constraint satisfaction problems that would not only swamp a system designed along the
Abstract
POPS is a processor for a simple nondeterministic programming language, · PSL. POPS accepts a problem stated in PSL and attempts to solve it by finding a suc cessful execution of the PSL program. POPS operates by identifying elements of the input program with elements of the heuristic search paradigm, analyzing the input program to obtain information about the problem opera tors, and applying methods borrowed from GPS to solve the problem. In addition to the goal-directed methods based on GPS, POPS contains the methods developed by Fikes in his program REF-ARF.
Key words : Problem solving, Heuristic search, Nondeterministic programming language.
Background
Nondeterministic Algorithms
Robert Floyd (Floyd, 1967) suggested that a com piler for a nondeterministic programming language (NDPL) could be used as a problem solver. His NDPL was ob tained by adding to Algol the function CHOICE (N) and two special labels for exits, SUCCESS and FAILURE. The value of CHOICE (N) is an unspecified integer be tween 1 and N . Only executions that terminate with a SUCCESS exit are considered· to be computations of the algorithm. The programmer may impose constraints on the values of the program variables by inserting, for example, IF statements that direct the flow of control to a FAILURE exit unless the constraints are satisfied. In this way the programmer specifies what constitutes a solution to his problem.
The proposed problem solver would operate as a compiler by translating a nondeterministic program into a deterministic one and executing the resulting program. The deterministic program is so constructed as to simu late the input program by enumerating the possible com
binations of values of the CHOICE function.
Floyd illustrated his proposal with a complete statement, translation, and solution of a sophisticated representation of the Eight Queens problem. This ex ample shows clearly that programming a problem in his nondeterministic language is much easier than program ming the corresponding search in a conventional language. However, it is also clear that the solution is obtained by a blind generate and test search. Thus, un sophisticated representations of problems having large search sp_aces would result in unacceptably long lines suggested by Floyd, but would prove very difficult for humans to solve as well.
REF-ARF will accept HS problems, but is essential ly limited to a generate and test algorithm in its search for an executable path through the program. HS prob lems can induce REF-ARF to expend thousands of times more effort than is intrinsically required by the problem. For example, if the Missionaries and Cannibals pro blem is represented by a program with a single loop rep resenting a crossing of the river, and the loading of the boat is selected nondeterministically, then each path through the program will represent a constraint satis faction problem having two selections for each crossing of the river. RElf2, an early version of POPS which used the same search mechanism as REF-ARF, was presented with such a program. Calculation showed that the solu tion would have required over 32 hours of 360/67 time.
POPS (Procedure Oriented Problem Solver) extends Fikes's work by including the successful methods of REF-ARF in a system designed to solve heuristic search problems. POPS was written in Lisp 1. 5 and run on the 360/67 computer at the Naval Postgraduate School using the Waterloo Lisp Interpreter (Bolce, 1967).
The Problem Statement Language, PSL
PSL is a simple algebraic language, similar to Fikes's language, REF. PSL contains a nondetermin istic choice function SELECT(A), whose value is some element of the named range A. The user may impose constraints on the values of the program variables by using the statement CONDITION(B), which means that at the time the statement is executed the boolean expres sion B must be satisfied. PSL also contains a nonde terministic branch instruction, GOTOL (Ll, L2 ··. Ln). GOTOL is essentially a computed GO TO with the index unspecified.
An Approach to Heuristic Search Problems: GPS
REF-ARF's considerable success with constraint satisfaction problems is due largely to algebraic simpli fication methods which allow it to reduce its search space without eliminating valid solutions. Unfortunate ly, there is no similar way of reducing the space of pos sible execution paths when a program's flow of control is nondeterministic. The alternative is to provide some mechanism whereby the processor can make informed decisions in its search for a successful control path. The GPS work of Newell and others (Newell, Simon, and Shaw, 1963; Ernst and Newell, 1969) provides such a mechanism, namely, the selection of operators on the basis of their apparent usefulness in the current situation.
A problem statement for GPS contains a set of ob jects which are transformable by a given set of opera tors. A problem takes the form: given an initial object x 0 , find a sequence of operators q such that the predi cate p is true of the object q{X 0 ) ·. GPS attempts to trans form the initial object into a desired object by matching the initial object to the desired object (or to the pro perties of a desired object) in order to obtain a "dif ference; GPS then attempts to reduce the difference by applying an operator to the object. The operator is selec ted by means of a table of connections which indicates the relevance of the operators to the various differences.
The POPS Program
POPS solves heuristic search proble-ms by applying GPS techniques to the interpretation of PSL. Like GPS, POPS operates by transforming an initial object into a desired object by the application of operators.
The task environment of POP$. In the task environ ment of POPS, an object is a path from the beginning to the end of a PSL program. If the entry and exit points of the program are given labels, and if every point in the program at which control paths join is labelled, then every execution path corresponds to a string of labels. The set of such strings of labels can be given by a grammar.
POPS obtains a suitable grammar by identifying all simple closed paths in the program and all simple paths from the beginning to the end of the program. For ex ample, the program whose flowchart appears in Figure has possible execution paths given by the following grammar:
S .... BEGIN A EXIT
A ... A Ml A I A M2 A I I A Mn A
Thus, solving a problem stated as a PSL program can be considered as searching in the space of strings of labels. The initial object is (BEGIN A EXIT), and each subse quent object results from applying one of the rules of the grammar for the program to a previously generated object.
The final object is a string of labels representing a path through the program such that if the path were ex ecuted, all the constraints would be satisfiable. Clear ly not all grammatically legal paths have this property. Thus, the search process must select the rules to apply at each point, and verify that at each point in the path the current constraints can be satisfied. Such a path will be referred to as a legal path.
Because applying a rule of the grammar to a string can result in an illegal path, the process of applying an operator in the original problem is represented by apply ing a rule of grammar and then executing the PSL program along the control path represented by the resulting string. If this execution results in the creation of an unsatisfiable constraint, then the operator represented by rule does not apply to the object represented by the previous string of labels.
De scription of operators. POPS uses a technique similar to that of GPS to make rational selections of operators. In place of a table of connections, POPS uses a description of the effects of the problem opera tors. To obtain these descriptions, POPS executes each operator in isolation, i.e. , with no assumptions about the effects of any prior operators. By examining the assignments and the constraints so generated, POPS constructs a simple description of the operator's effects. Presently, this description consists of 1) a list of the program variables that are used before they are assigned, 2) a list of program variables that are changed, 3) the set of constraints that must be satisfied before the operator may be applied, and 4) the size of the operator, as measured by the number of symbols in the data struc ture generated by the trial execution of the operator. While the current set of descriptors is minimal, it is sufficient to guide POPS directly to the solutions of several simple heuristic search problems, as will be seen. More sophisticated analysis of operators would facilitate more intelligent selection of operators by the problem solver, and should enable it to solve more sub stantial problems.
Differences. Since any complete executable path is an acceptable final object, the match is accomplished by attempting to execute the path represented by the ob ject. If a path is not executable, it is because at some point in the execution of the path, the processor en counters a constraint that cannot be satisfied. The pro cessor then returns a triple (L, R, D), where Lis the portion of the path that can be executed, R is the re mainder of the path, and D is the unsatisfiable con straint, together with a description of what changes to the program variables must be made in order to satisfy the constraint. This description is the POPS version of the GPS difference.
Selection of operators. To select an operator, POPS compares the difference with the descriptions of the available operators, and selects the operator that appears most promising. Currently, POPS selects the operator that changes the most program variables need ing change. In case of a tie, it selects the operator that changes the fewest variables having acceptable values. Finally, if there is still more than one candi date operator, POPS selects the smallest one.
Example. Consider, for example, the !vbnkey pro blem, given in Figure 2. The grammar for the PSL pro gram is:
S BEGIN A GET_BANANAS
A A WALK A I A CARRY A I A CLIMB A
The initial object is (BEGIN A GET_BANANAS). If this path is executed, a contradiction will be found after passing A, because the necessary conditions for exit ing the program have not been met-- the monkey doesn't have the bananas. The goal then becomes that of mak ing the offending constraint TRUE. This requires changing the values of M (1), M (2) and B(l). Since WALK changes M(1), CARRY changes M{l) and B(1), and CLIMB changes M(2), it is reasonable to guess that rule A - A CARRY A should be applied. The pro posed path then becomes:
(BEGIN A CARRY A GET_BANANAS).
When execution of this path is attempted, however, a contradiction is encountered at CARRY: the monkey cannot carry the box unless he is located where the box is, i.e., M{l) = B(l). The subgoal then becomes: make M (1) = B(l l true. Both WALK and CARRY change M(1), but CARRY does other things as well, so A- A WALK A is the move to try. The proposed path is then:
(BEGIN A WALK A CARRY A GET BANANAS). Execution of this path proceeds into GET_BANANAS
before finding a false constraint. This one is: M (2 )=box, representing that the monkey must be on the box. The correct move is A - A CLIMB A. The path becomes:
(BEGIN A WALK A CARRY A CLIMB A GET_BANANAS).
Since this path can be successfully executed, the solu tion has been found.
Redundancy Tests
POPS employs tests to prevent two types of redun dancy in its search for a complete executable path. A newly generated path is redundant if it is either identi cal with or equivalent to a previously generated path. Equivalent paths can be generated, for instance, if there are two operators q 1 and q 2 such that q 1 q 2 and q2q 1 achieve the same effect. Identical paths can be gen ated as follows:
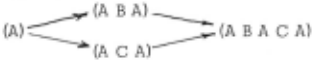
Here the two operators A - A B A and A - A C A have been used to expand (A) to generate (A B A C A) in two different ways.
POPS tests newly generated paths for equivalence to previous paths by comparing the state of the program variables resulting from the execution of the new path with the results of executing previously generated paths. This comparison can be rather expensive if the variable values are formulas; however, the comparison is essen tial to lim it search.
POPS automatically avoids the generation of identi cal paths by restricting the selection of operators ac cording to a rule known as the 0-size rule. Each opera tor 0 is assigned a unique size, denoted IO 1. The O-size rule provides that an operator 0 may be consider ed for application to a path P = (L, R, G) only if IO I < OR and IO I .$_ OL, where OL is the size of the last operator used to generate L and OR is the size of the next operator in R. Intuitively, one may consider the size of an operator to be its difficulty. The O-size rule then predicates that POPS will consider applying an operator to an object only if the operator is easier than its immediate supergoal and no more difficult than the previous goal.
The importance of the O-size rule is that it prevents the catastrophic proliferation of identical nodes in the program's search space. Without such a test, the num ber of redundant nodes can grow as fast as N! , where N is the number of operators applied to generate a single node. The redundancy could be eliminated by means of a direct comparison with previous nodes; indeed, this is the usual practice. However, the number of compari sons required grows exponentially with N. In contrast, the cost of the 0-size rule is only two comparisons per node generated. These assertions about the O-size rule are proved elsewhere (Gibbons, 1972).
POPS flowcharts. The flowcharts for the major prob lem solving processes in POPS are given in Figure 3. POPS itself is an executive routine that analyzes the PSL program to obtain the grammar and operator descriptions, and then enumerates the simple paths through the PSL
program until one is found that can be converted into a legal path. The other programs, TRANSFORM, FIXPATH and APPLY are similar to the GPS methods TRANSFORM, REDUCE , and APPLY, respectively, as given in Newell and Simon (1963). In FIXPATH, the list of operators is filtered by the Q-size Rule before an operator is selec ted. The operation "assign if appropriate" selects actual values for nondeterministic expressions under certain circumstances. Issues surrounding this assign ment will be discussed in the following section.
Performance of Pops
The performance of POPS can be easily evaluated by means of a comparison with the performance of Ref2 on the same problem. Ref2 is the immediate predeces sor of POPS, and contains the same basic machine·ry in cluding formula manipulation processes, data repre sentation, and constraint satisfaction methods. The design of Ref2 is sufficiently similar to that of REF- ARF , except in its data representation, that comments about the performance of Ref2 apply equally well to REF-ARF. The performances of Ref2 and POPS on the problems dis cussed are summarized in Figure 9 .
The GPS-like control structure of POPS and the basic control of search provided by the Q-size rule and the redundancy test, provide a skeleton of a problem solver. The sources of problem solving power in POPS are the processes that analyze the PSL program to get a description of the operators, select the operator to apply during FIXPATH, and decide whether to assign values to variables during FIXPATH, and if so, what values to assign . The performance of POPS depends directly on the adequacy of these description and com parison processes. These processes are rather rudi mentary at pre sent, yet they suffice to guide POPS to the solution of some simple HS problems that REF- ARF and Ref2 were unable to solve with reasonable effort.
The Missionaries and Cannibals Problem
Ref2 is unable to solve the Missionaries and Can nibals problem as stated in Figure 4. The problem statement contains only one operator. Executing the operator requires that two selections be made from a range of three possible values. Ref2 approaches this program by executing directly to the end, where it en counters a constraint satisfaction problem. If it finds no solution to the constraint satisfaction problem, Ref2 attempts an alternate path to the end . Since the solution of the problem requires eleven eros sings of the river, and each crossing is accomplished by one execution of the loop in the program, the first ten con straint satisfaction problems will have no solution. Since each crossing of the river generates two addi tional variables, we may estimate the size of the nth constraint satisfaction problem to be Kn, where K is the average number of possible selections generated by one crossing of the river.
On being given this program, Ref2 ran out of time at eight minutes, having failed to complete the search on the fifth constraint satisfaction problem . If we as sume K = 3 , then the total space Ref2 would search through the fifth constraint problem would contain about 540 nodes, so that the search rate established by Ref2
is roughly 540 nodes per eight minutes . Under these assumptions, the total space to be searched by Ref2 up through the tenth crossing of the river is roughly 133,000 nodes. In short, Ref2 would start on the final crossing of the river after computing for something in excess of 32 hours on the problem.
Whether the above estimate is accurate is immateri al; the point of consequence here is that delaying the determination of actual values for the nondeterministic selections causes Ref2 to expend a tremendous amount of time on redundant search. The space of the Mission ary problem is actually remarkably small - only sixteen distinct legal configurations can be reached from the initial node.
In contrast to Ref2 ' s estimated time of 32 hours, POPS solves the Missionary problem in somewhat less than six minutes. The search conducted by POPS is shown in Figure 5. This success is based on a method of assigning actual values to nondeterministic selec tions before the end of the program has been reached.
When to assign actual values. An assignment is made only if failing to do so would deepen the space of the constraint satisfaction problem at the end of the program. For instance, if an operator contains an as signment such as X = X + SELECT (A) , and the current value of X is already SELECT (A), then the eventual con straint satisfaction problem would contain variables representing both selections. If the range A contains N elements , the number of possible selections would be N2 , but the number of distinct values of X could be as small as 2N. Before applying the operator in such a case, POPS chooses an actual value for the first selec tion. Then after the operator is applied, the value of X still depends on only one SELECT operator. Conse quently, in the Missionary problem, each of the con straint satisfaction problems encountered at the end of the program has only two variables, and the constraint satisfaction problem space searched by POPS in the first ten crossings contains roughly 30 nodes.
Selection of actual values to assign. In choosing an actual value, POPS attempts to find the value that is most likely to be helpful in solving the problem. For example, in the Missionary Proble:m, where the selec tions determine the number of missionaries and the num ber of cannibals to place in the boat for a crossing of the river, POPS makes selections that maximize the number of persons being transported to the right side of river and minimize the number being transported to the left side of the river. The sense of direction this gives the search can be seen in Figure 5.
When POPS selects an operator, it is attempting to find one that will modify the current state of the program in a direction that will tend to satisfy some currently unsatisfied constraint. This constraint is also used to guide the selection of actual values. For example, in the Missionary problem, the constraint on the exit branch of the program says, among other things, that the number of missionaries on the right side of the river, MR, should be 3. Suppose the current value of MR is SELECT (A) , where A = f 0, 1, 2} . Then the first choice POPS will make for the value of this selection is 2, since that choice minimizes the difference between the current and desired values of MR. If the current value of MR were -SELECT(Al, then the first choice would be 0, for the same reason.
The Monkey Problem
The Monkey problem has been formulated in three different ways. The performance of POPS on these three problem statements illustrates its dependence on the in formation it can derive from the PSL program. Briefly, one version contains sufficient information that POPS makes no wrong decisions in the solution process. The other two formulations require some search. Flow charts for these formulations are shown in Figure 6.
MB4 and MB2. The first version of the Monkey problem will be referred to as MB4, because the con straint on the exit branch of the program specifies what the values of each of the four variables in the program must be. The second version will be called MB2, be cause it is identical to MB4 except that the constraint on the exit branch of the program specifies the values of only two variables. MB4 requires the monkey to be on the box under the bananas and the box to be on the floor under the bananas. MB2 requires only that the monkey be on the box under the bananas, and says nothing about the box. Of course, because of the struc ture of the problem, the box must be under the bananas and on the floor in order for the monkey to be on the box under the ·bananas, so that any solution of MB2 is a solution of MB4.
POPS does not recognize the necessity of moving the box in MB2 until it fails to solve the problem with out moving the box. Thus, POPS obtains less guidance from the constraints in MB2 than it does from the con straints in MB4; as a result, while POPS goes directly to a solution in MB4, it is forced to perform some search in MB2. The executions of MB4 and MB2 by POPS are shown in Figure 7.
Because MB4 and MB2 are identical except for the constraint on the exit branch, and because Ref2 gets no direction from the constraints, Ref2 carries out the same search on MB4 as it does on MB2.* Thus, be cause of its ability to use constraints to guide the selection of operators, POPS not only searches a smal ler space than Ref2 on MB2, but is also able to make use of the additional information in MB4 to reduce the search further.
MBF. The third version of the Monkey problem that POPS has run, called MBF, is a translation of Fikes's statement of the problem for REF-ARF. MBF was con sidered in order to get a direct comparison of Ref2 and POPS with REF-ARF, since Fikes does not report running problems stated like M82 and MB4. The search carried out by REF-ARF on MBF generated 28 nodes.
The chief difference between MBF and MB4 is that the control structure in MBF carries some information of potential value to the problem solver, whereas M84 is in strictly HS form. Ref2 performs considerably better on M8F than on MB4. POPS, however, finds a solution for M BF after applying only one operator, generating a space of only two nodes.
*In fact, Ref2 runs one second faster on M B2 than on MB4; the reason is that the shorter constraint in M 82 takes less time to evaluate.
Robot and Two Boxes Tasks*
This is a sequence of simple robot tasks with a single initial situation. In the initial situation, there is a room, and A, B, C, and D are locations within it. The robot is at location A, and two boxes, 81 and B2, are at location B. The following actions are available to the robot: it can walk to any location in the room; if the robot and box 82 are at the same location as box 81, the robot can stack B2 on top of Bl; and if the robot is at the same location as 81, the robot can push Bl to any location in the room. Thus, the only way the robot can move B2 to another location is by stacking it on Bl and pushing Bl. Also, the robot must know whether B2 has been moved or not.
There are five tasks in the sequence. They are:
- 1: The null task
- 2: Move the robot to location C
- 3: Move Box Bl to location C
- 4: Move Box B2 to location C
- 5: Move Box B2 to location C and Box Bl to location B
These tasks were intended to be of gradually increasing complexity so that some indication of the effect of in creasing complexity on the performance of POPS could be obtained. This sequence of problems was also given to Ref2 for comparison purposes.
POPS executions of the robot problems. The null task, problem 1 , is included in order to determine the cost of initialization; POPS spends 9. 9 seconds solving this problem. There is no search. The second task re quires one operator, WALK. POPS finds and applies this operator in 2. 5 seconds. Problem 3, move box Bl to C, is also simple, because the robot can push the box. The solution requires two steps, however. POPS first attempts to apply the operator that pushes B 1. Before that operator can be applied, however, it is necessary to apply WALK, to get the robot to the same location as Bl. POPS selects and applies these two operators in 6. 9 seconds, or 3. 45 seconds per subgoal. To move Box B2 to C (problem 3), it is necessary to push Bl over to B2, stack B2 on Bl, and then push them both to C, requiring a total of four operators and taking POPS 17.8 seconds plus initialization, or 4.45 seconds per subgoal. In the fifth problem, POPS must move B2 to C as in pro blem 4 and then unstack B2 from Bl and push Bl to loca tion B. After stacking B2 on Bl and pushing them to location C, POPS erroneously selects WALK instead of attempting to push Bl, thereby generating seven sub goals instead of the necessary six, for a cost of 3 5. 1 seconds, or 5 seconds per subgoal.
Figure 8 shows the search POPS conducted on these problems. The performance of POPS on these problems Ref2 executions of the robot problems. Because Ref2 performs essentially no preliminary analysis of a PSL program, it can do the null robot task faster than POPS. On the more complex task, however, Ref2 be comes less effective than POPS. This is to be expected in problems where POPS is able to derive some guidance from the problem statement. See Figure 9.
*These problems were suggested by a similar set of tasks given by Raphael (1971). Raphael uses these tasks to illustrate the frame problem.
Conclusion
The major accomplishment of POPS is the applica tion of goal directed methods to the execution of non deterministic programs. The analysis of the effects of operators and the selection of operators on the basis of a match between the current situation and the desired situation allows POPS to display a sense of direction in its search, and not rely merely on generate and test search, as other processors for nondeterministic lan guages do. POPS contains discrete processes for de scribing operators, describing goals, selecting opera tors, and selecting values to assign. These processes may be improved almost independently of each other, and without modification of the basic system. Con sequently, the design will support substantial improve ment in problem solving ability.
@inproceedings{ijcai1973p73,
  title     = {POPS: An Application of Heuristic Search Methods to the Processing of a Nondeterministic Programming Language},
  author    = {Gibbons, Gregory Dean},
  booktitle = {Proceedings of the Third International Joint Conference on
               Artificial Intelligence, {IJCAI-73}},
  publisher = {International Joint Conferences on Artificial Intelligence},
  editor    = {Nils J. Nilsson},
  pages     = {589--599},
  year      = {1973},
  month     = {8},
  note      = {General Problem Solving},
  url       = {https://ijcai.org/proceedings/1973/73},
}
TY - CPAPER TI - POPS: An Application of Heuristic Search Methods to the Processing of a Nondeterministic Programming Language AU - Gibbons, Gregory Dean T2 - Proceedings of the Third International Joint Conference on Artificial Intelligence, IJCAI-73 PB - International Joint Conferences on Artificial Intelligence PY - 1973 SP - 589 EP - 599 UR - https://ijcai.org/proceedings/1973/73 ER -Copied
Machine-readable versions of this paper, for tools and AI agents:
 Welcome
 Future Conferences
 AI Journal Division
 IJCAI Proceedings
 About IJCAI
 IJCAI Awards